 Ehsan Abdi


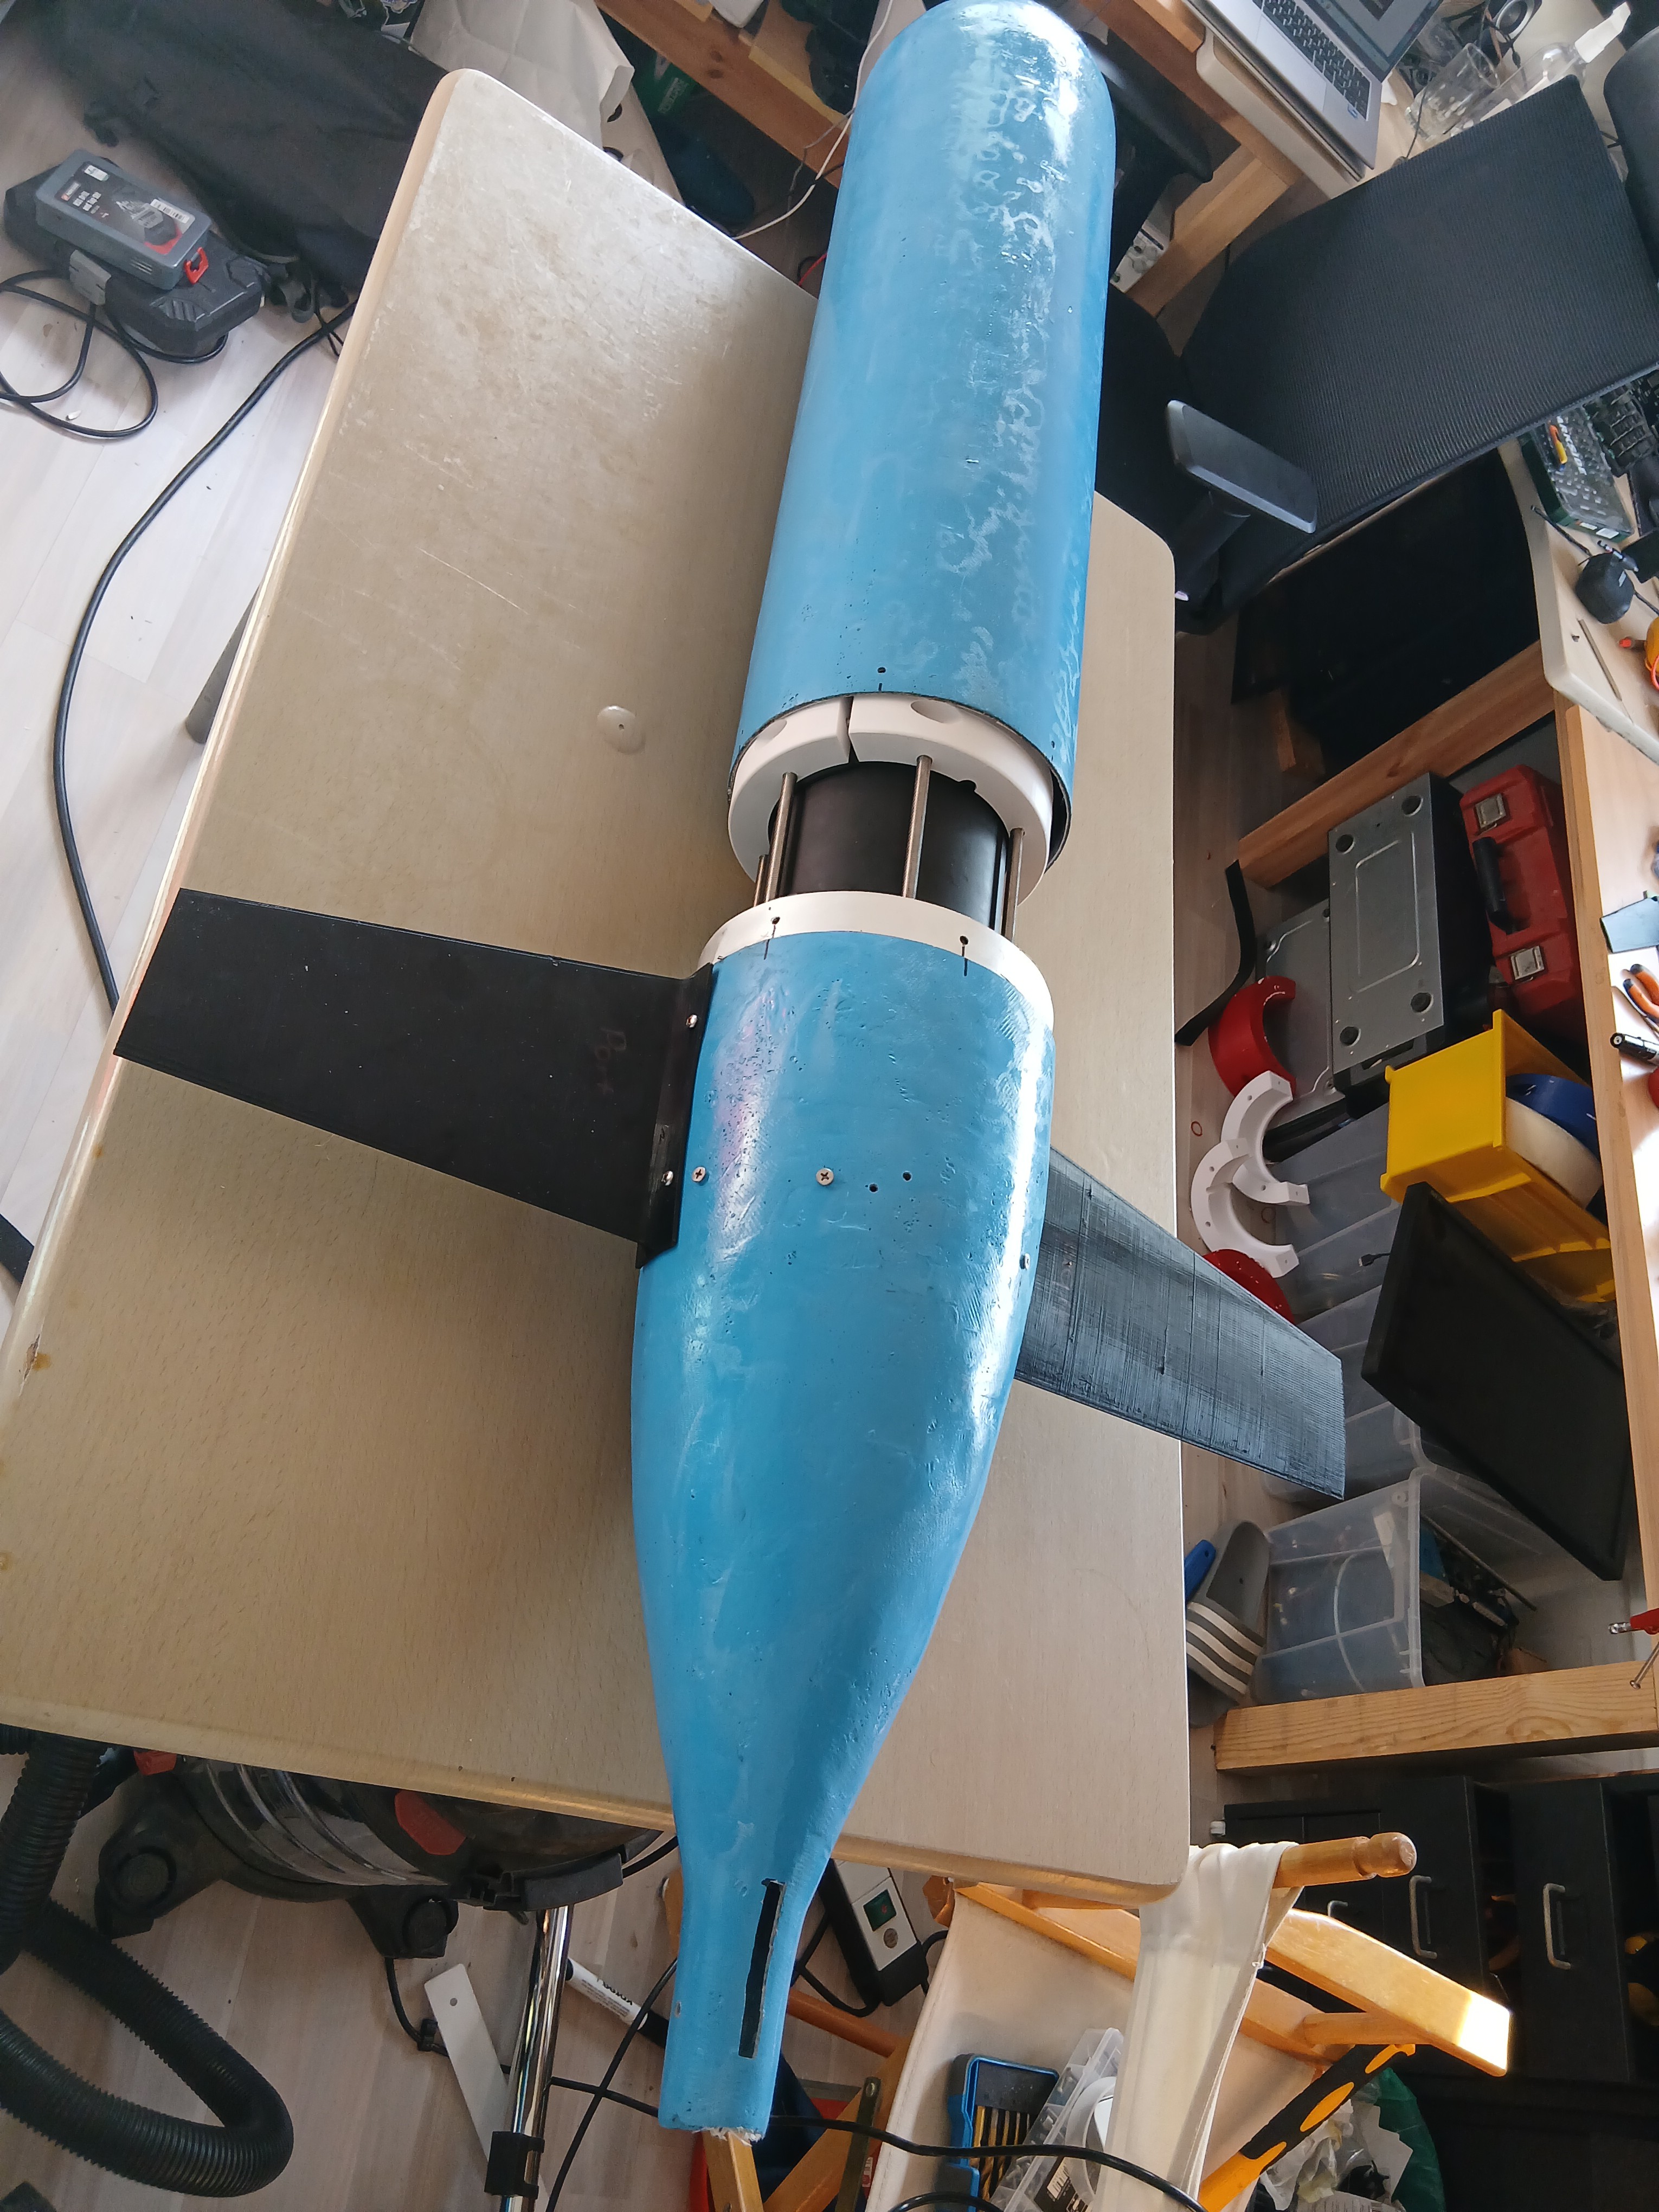
An underwater glider operates on principles similar to those of an aircraft glider, but in water instead of air. Like their airborne counterparts, underwater gliders do not use propellers for propulsion. Instead, they move forward by converting vertical motion into forward glide using their wings.
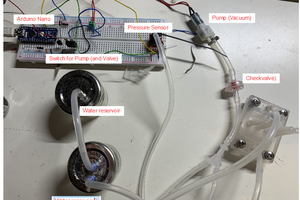
The key difference lies in how they return upward after descending. Underwater gliders use a clever buoyancy-based mechanism: they are designed to have a density very close to that of the surrounding water. By slightly changing their volume—using systems such as a piston pump or an oil-filled bladder—they can adjust their density. This allows them to alternately become slightly heavier than water (to descend) or slightly lighter (to ascend), effectively “flying” up and down through the water column.
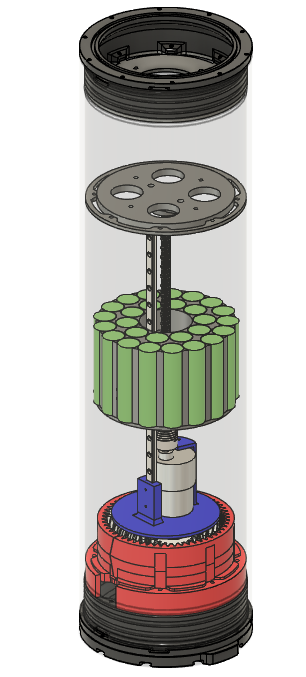
To control their movement, gliders shift an internal mass—typically the battery pack. Moving this mass forward or backward changes the pitch, controlling ascent and descent angles. Rotating the mass laterally induces roll, which in turn allows the glider to steer and maintain a desired heading.
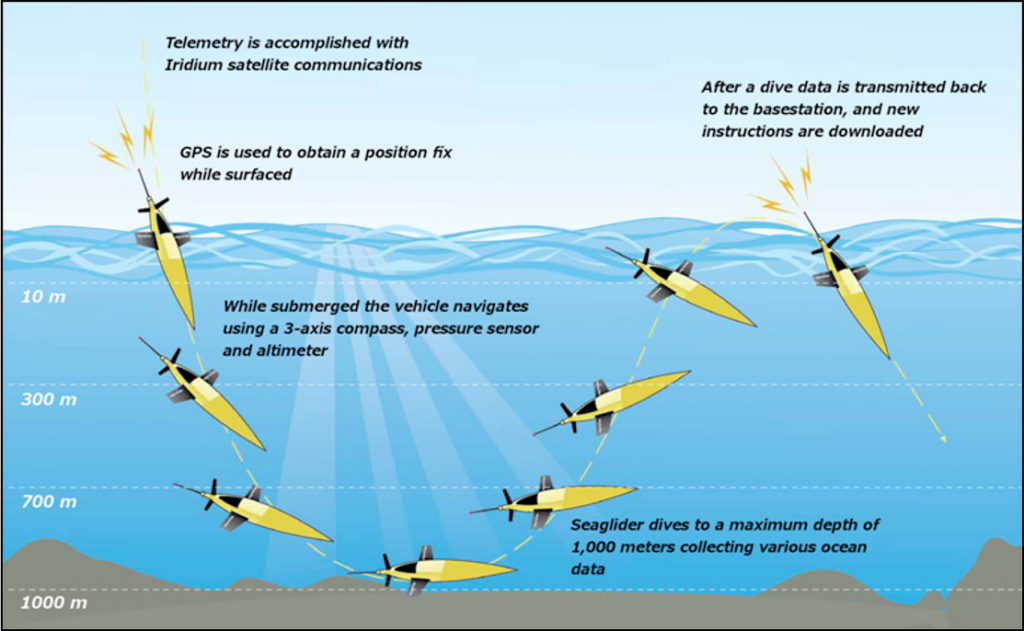
Ocean gliders have become an important tool for sustained ocean observation because they combine long endurance, low power consumption, and high-resolution sampling in a mobile platform. By changing buoyancy rather than relying on continuous propulsion, a glider repeatedly dives and climbs through the water column, following a characteristic sawtooth flight path while progressing horizontally between waypoints. This allows it to collect repeated profiles over large spatial areas and long time periods, often reaching depths of around 1000 m or more depending on the platform. Even with a basic sensor payload, gliders can measure essential ocean variables such as temperature, salinity, pressure, and depth-averaged currents. Together, these observations provide valuable insight into the structure, variability, and movement of ocean water masses, helping to bridge the gap between fixed-point moorings, drifting floats, satellite observations, and ship-based surveys.
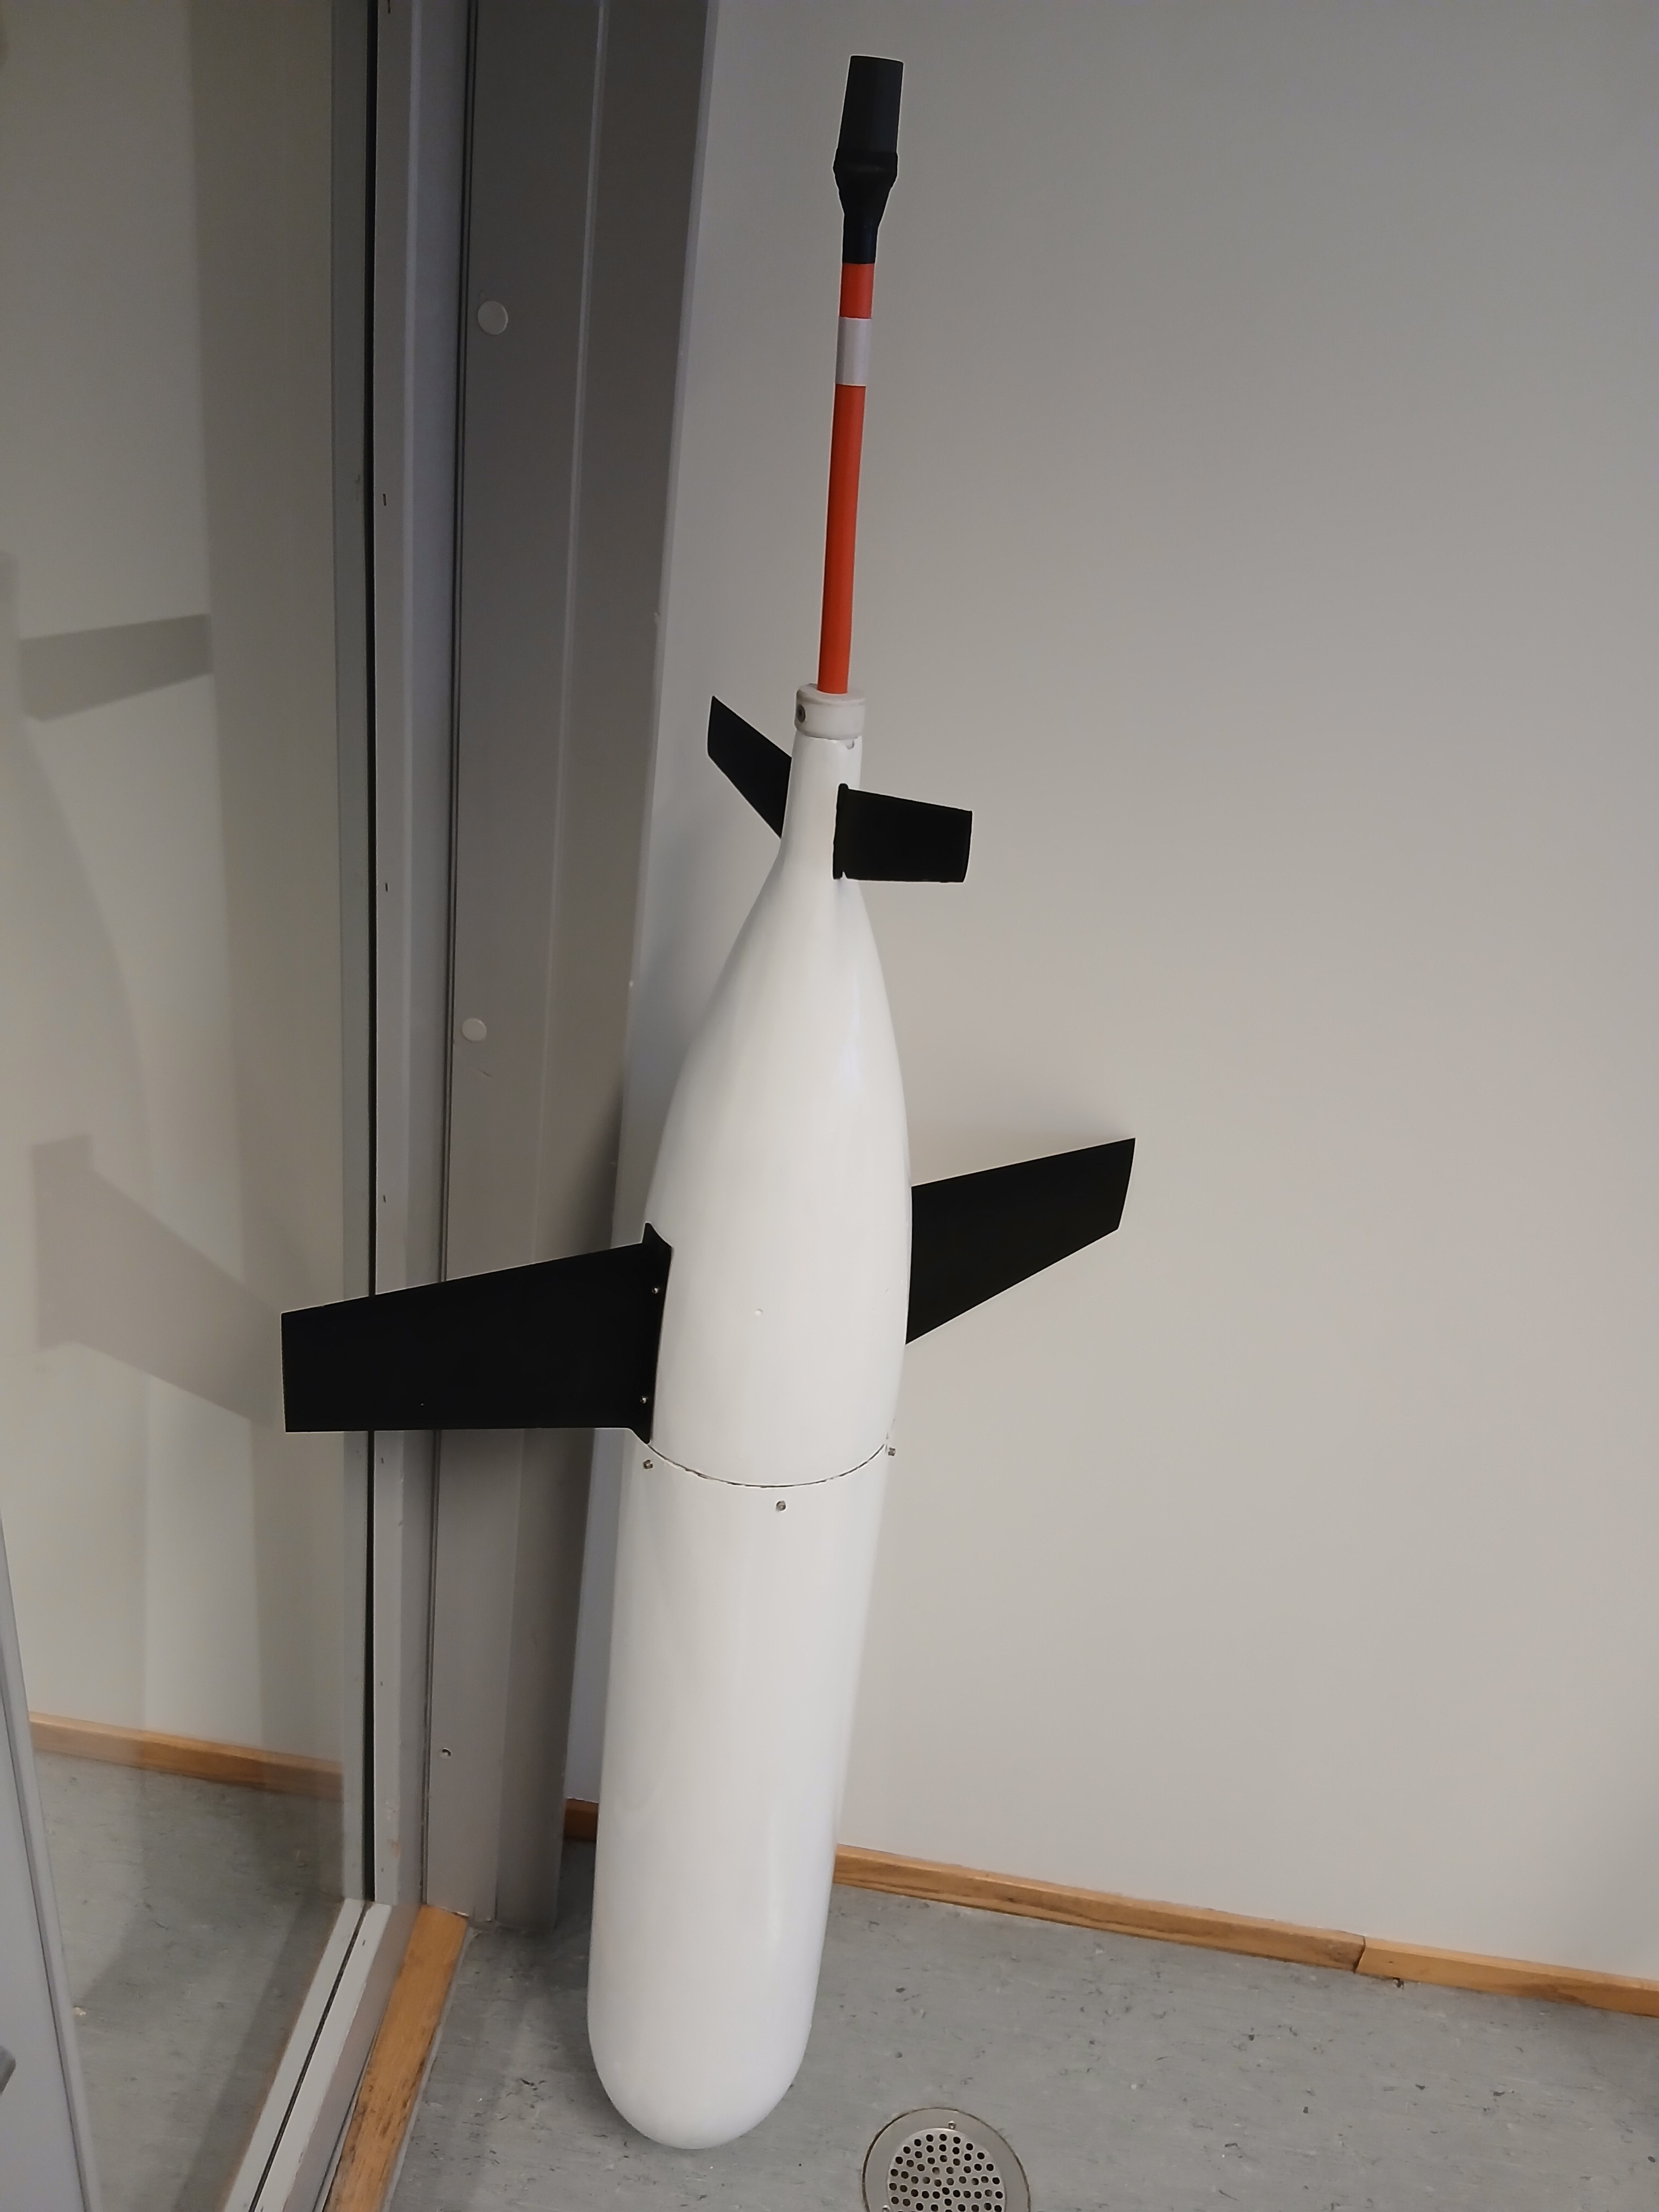
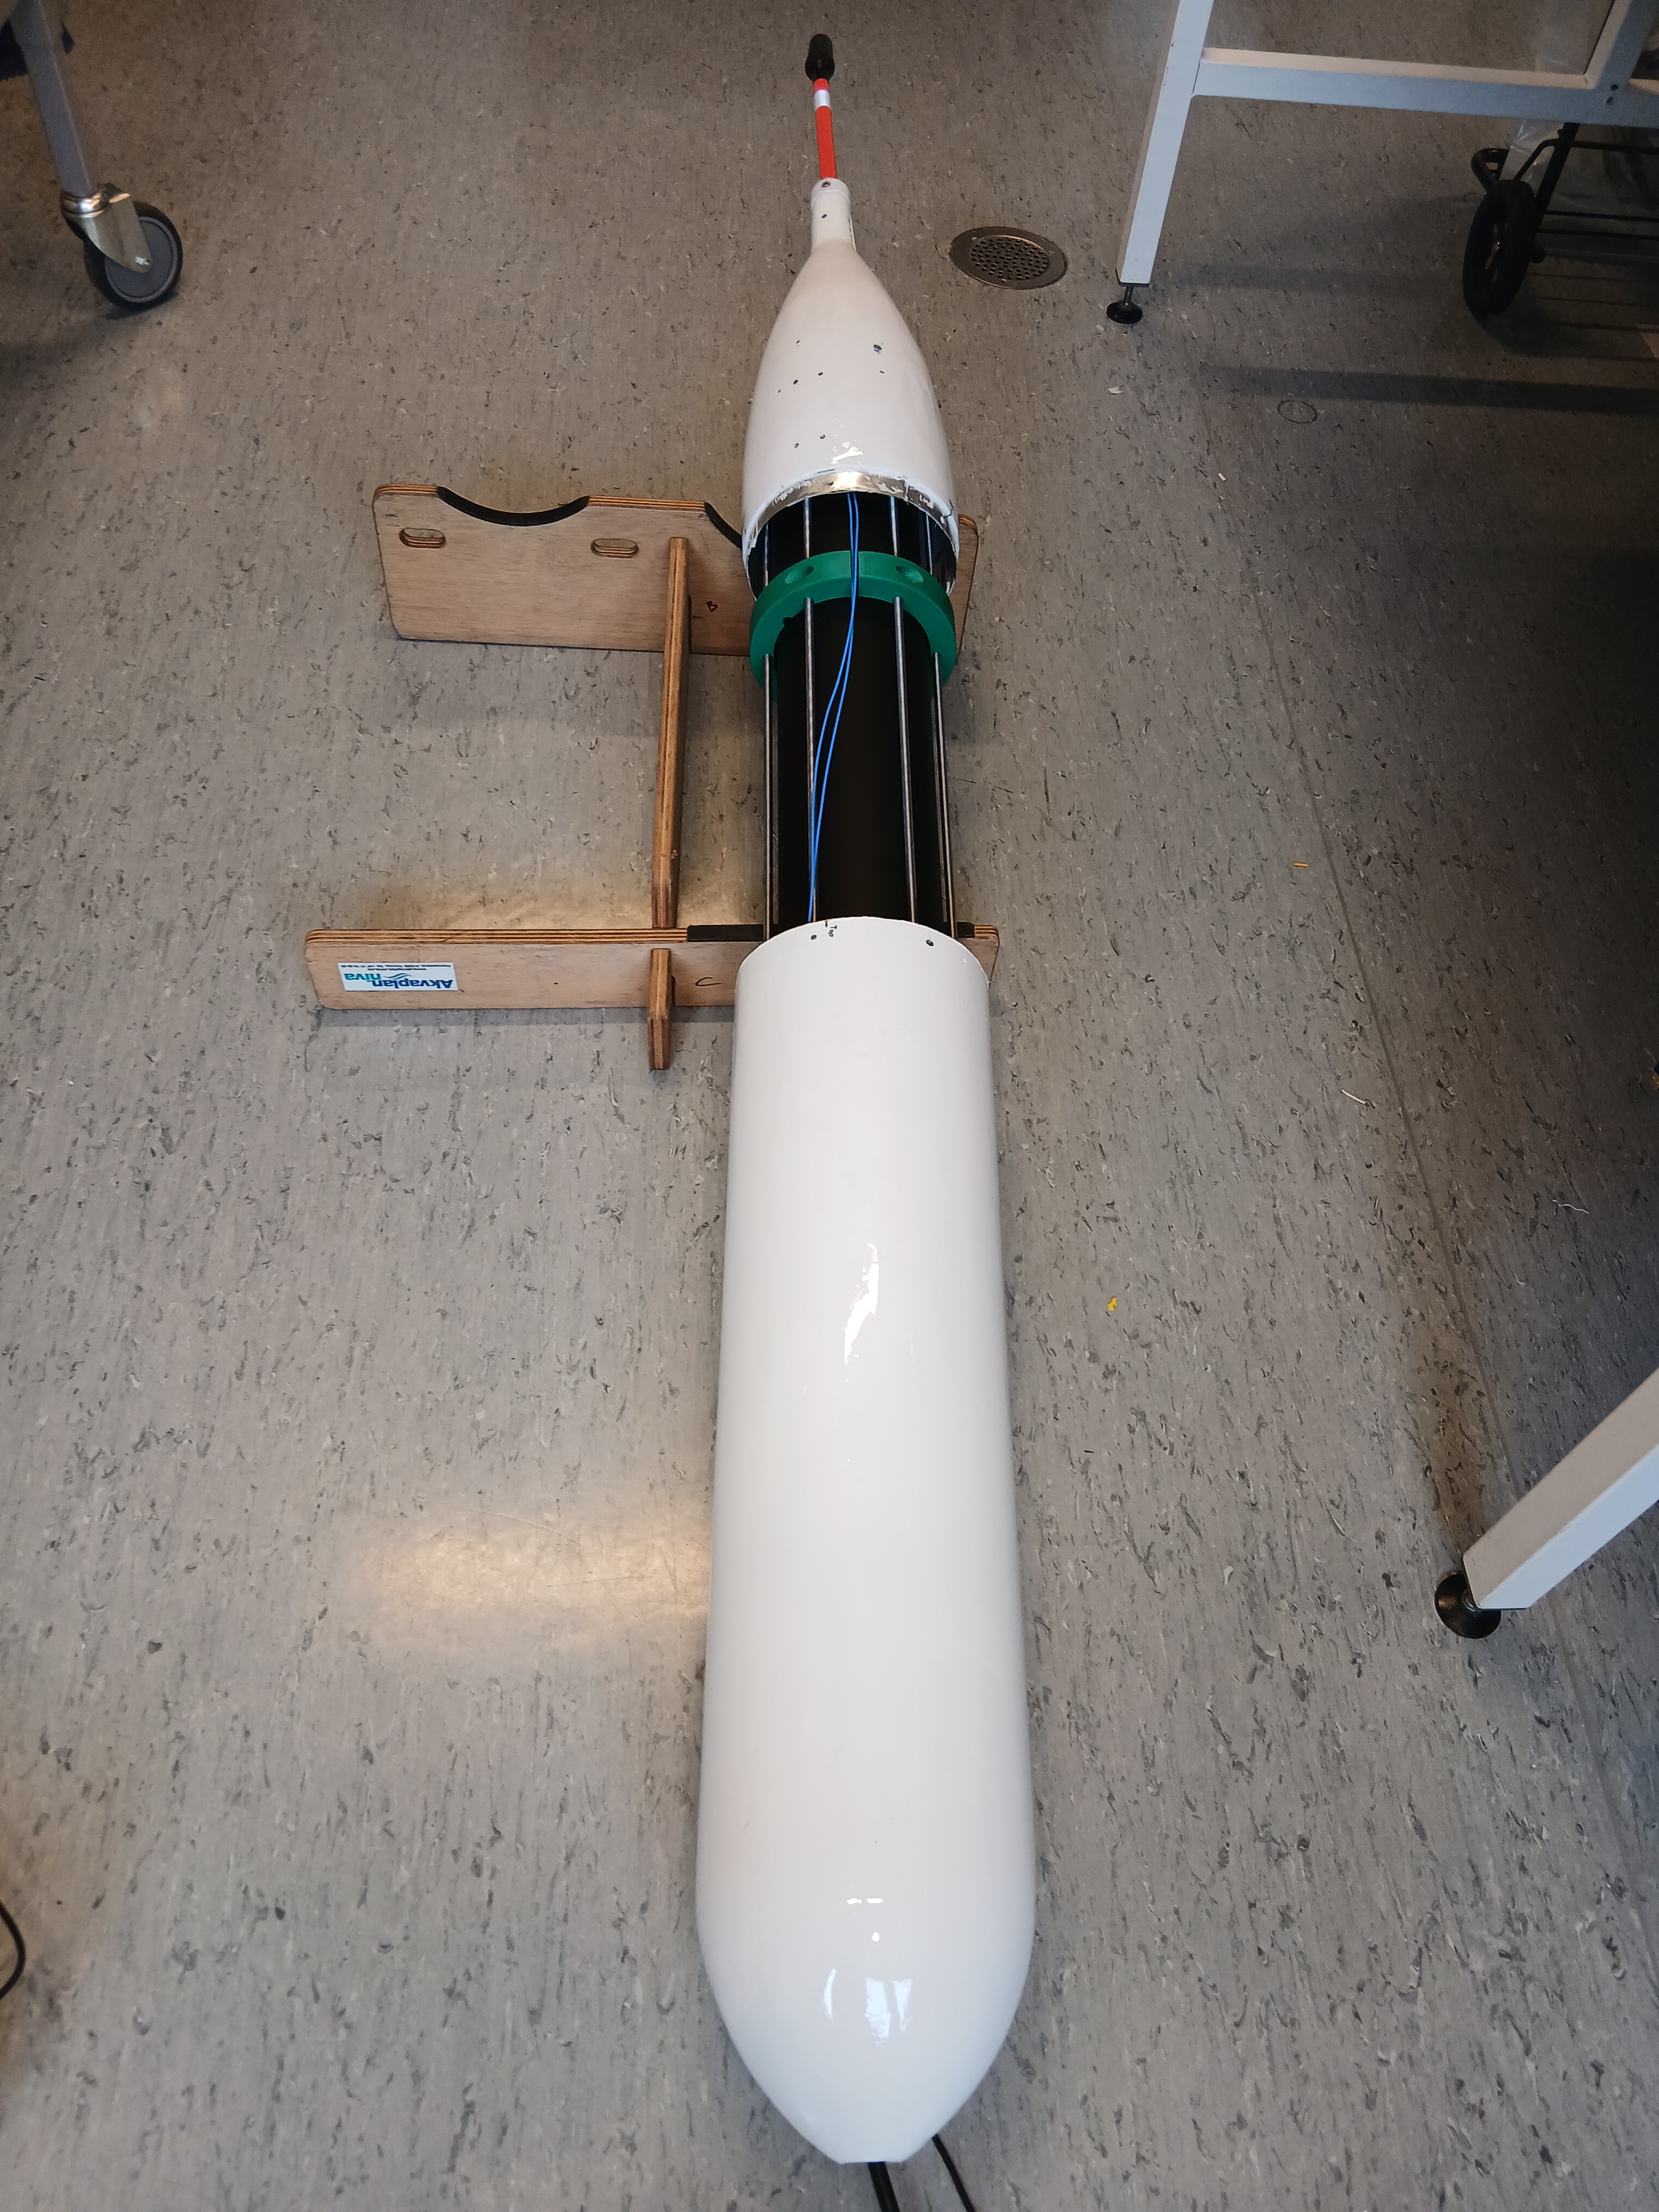
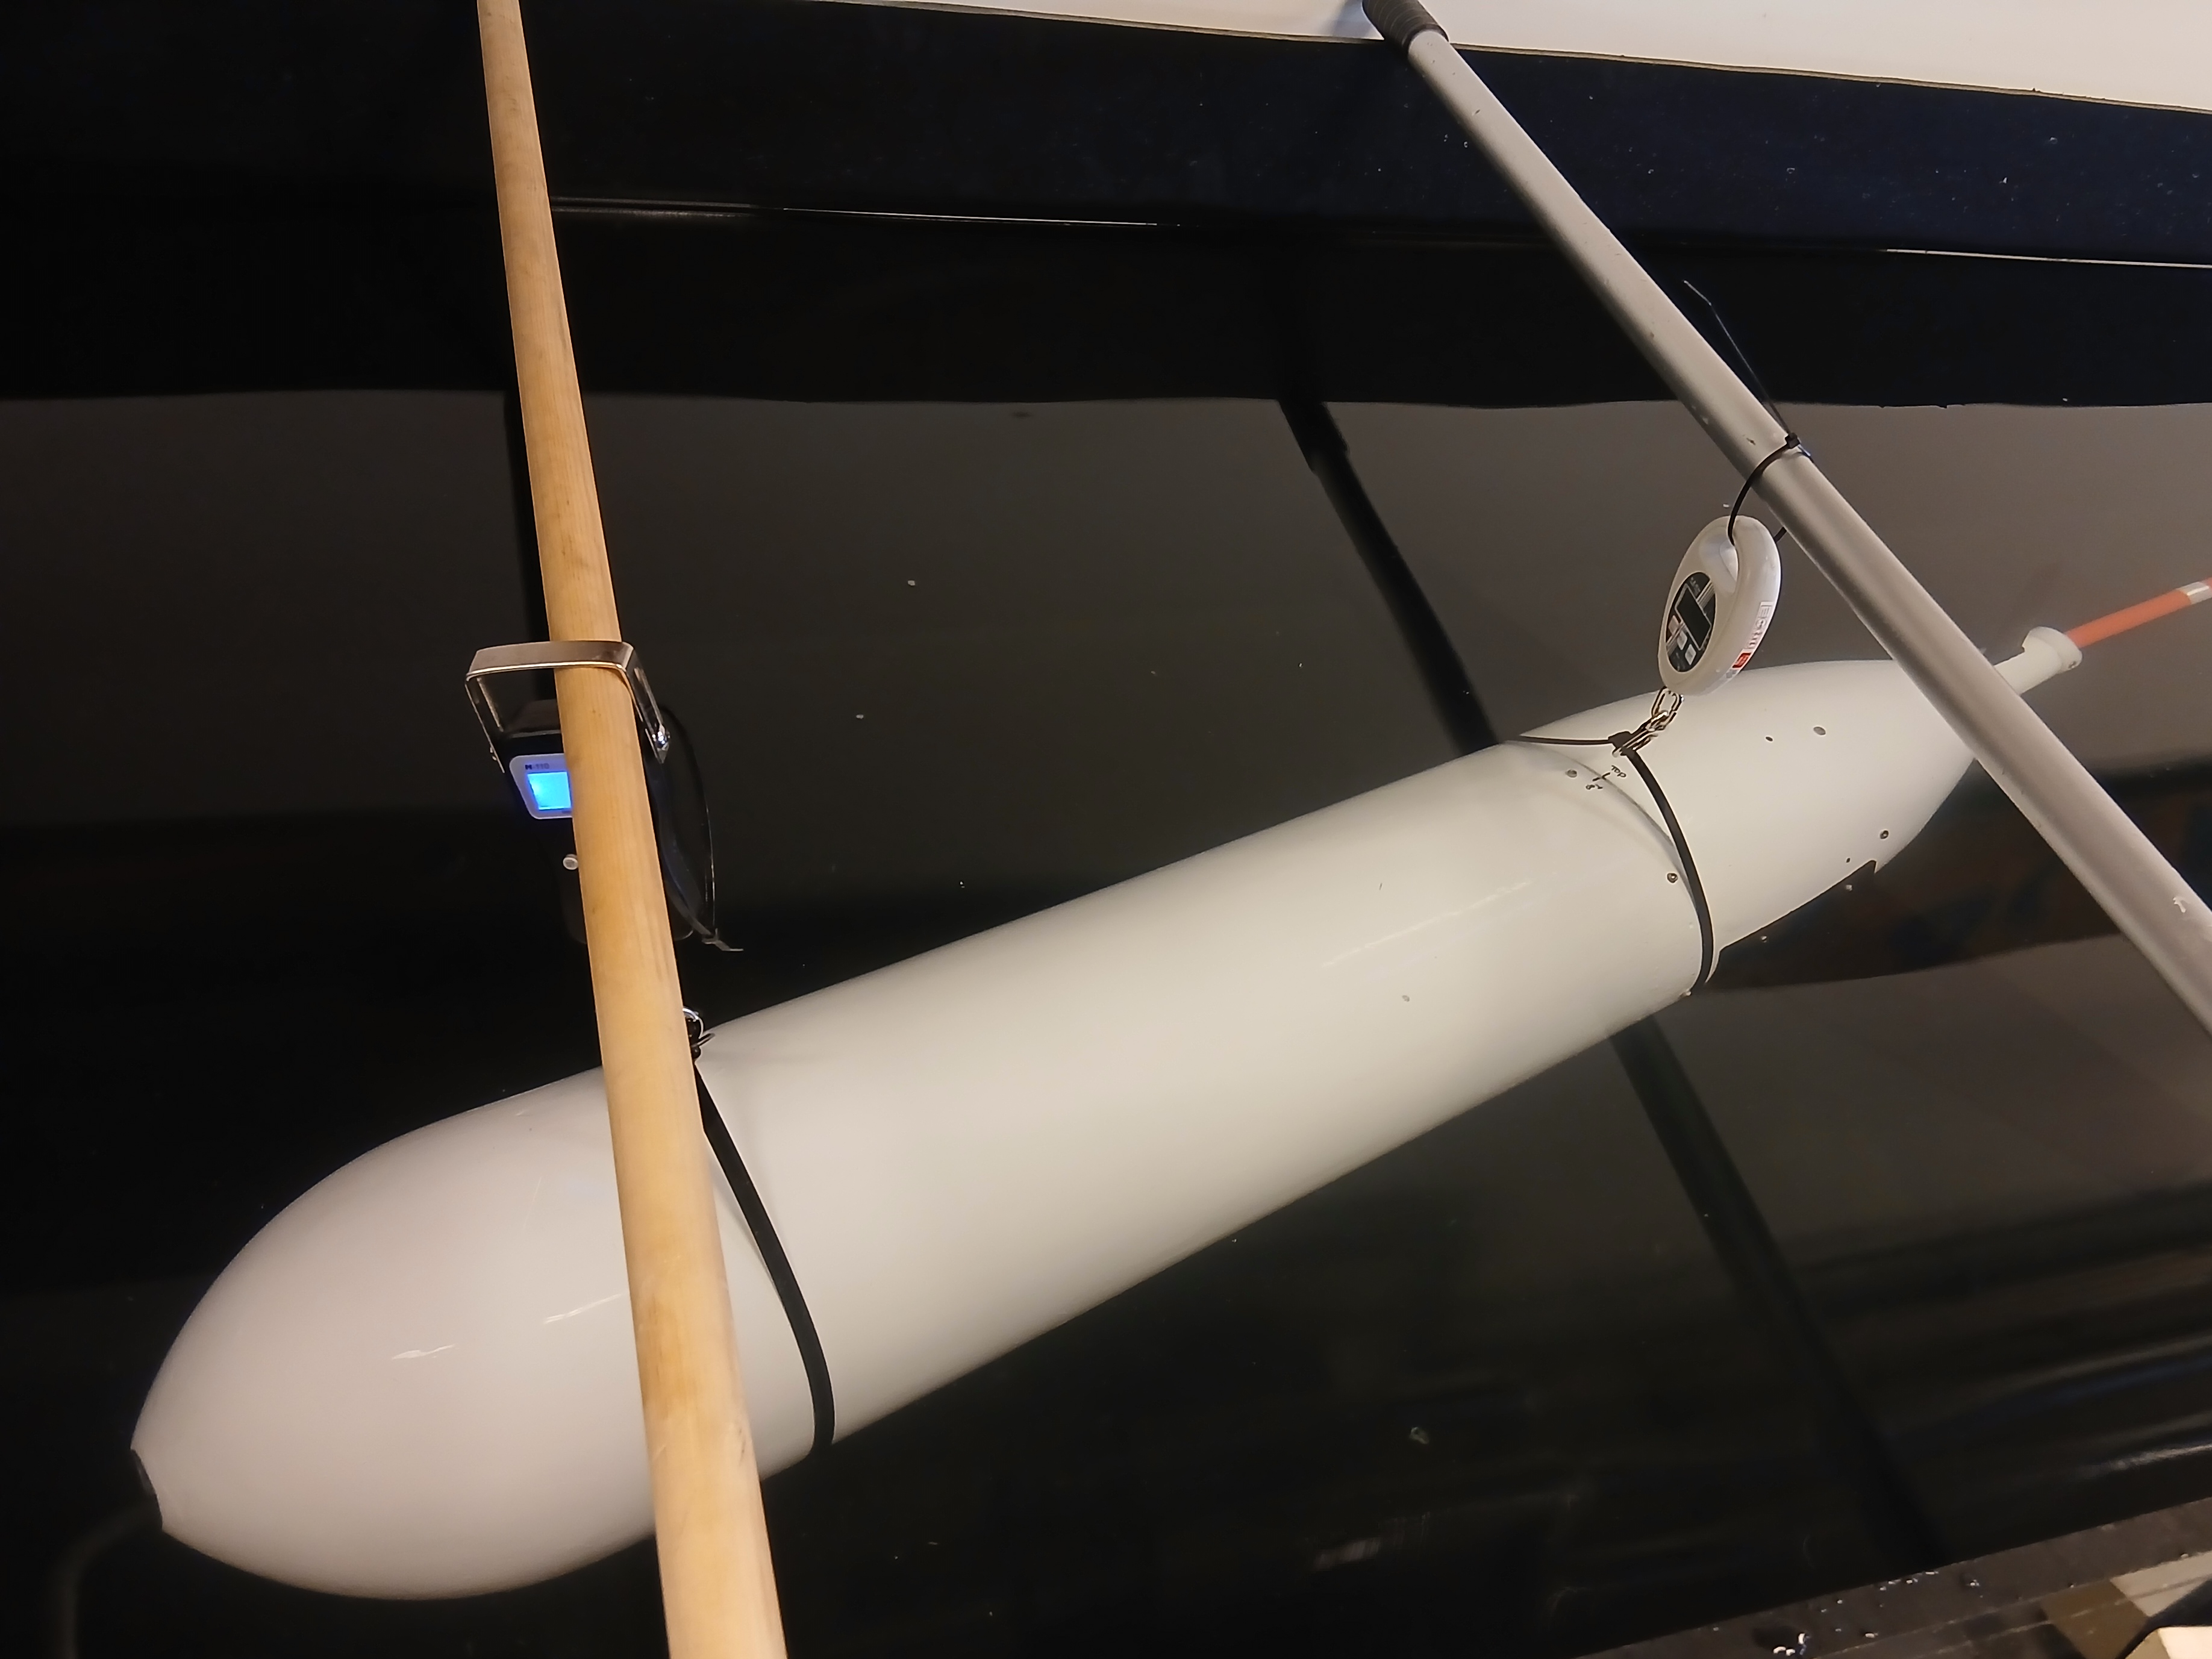
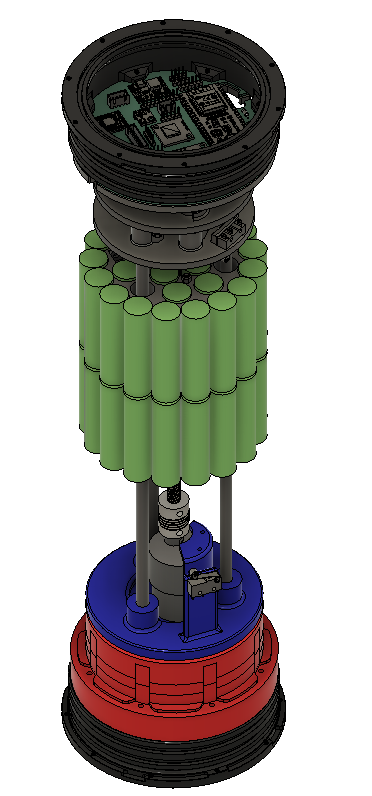
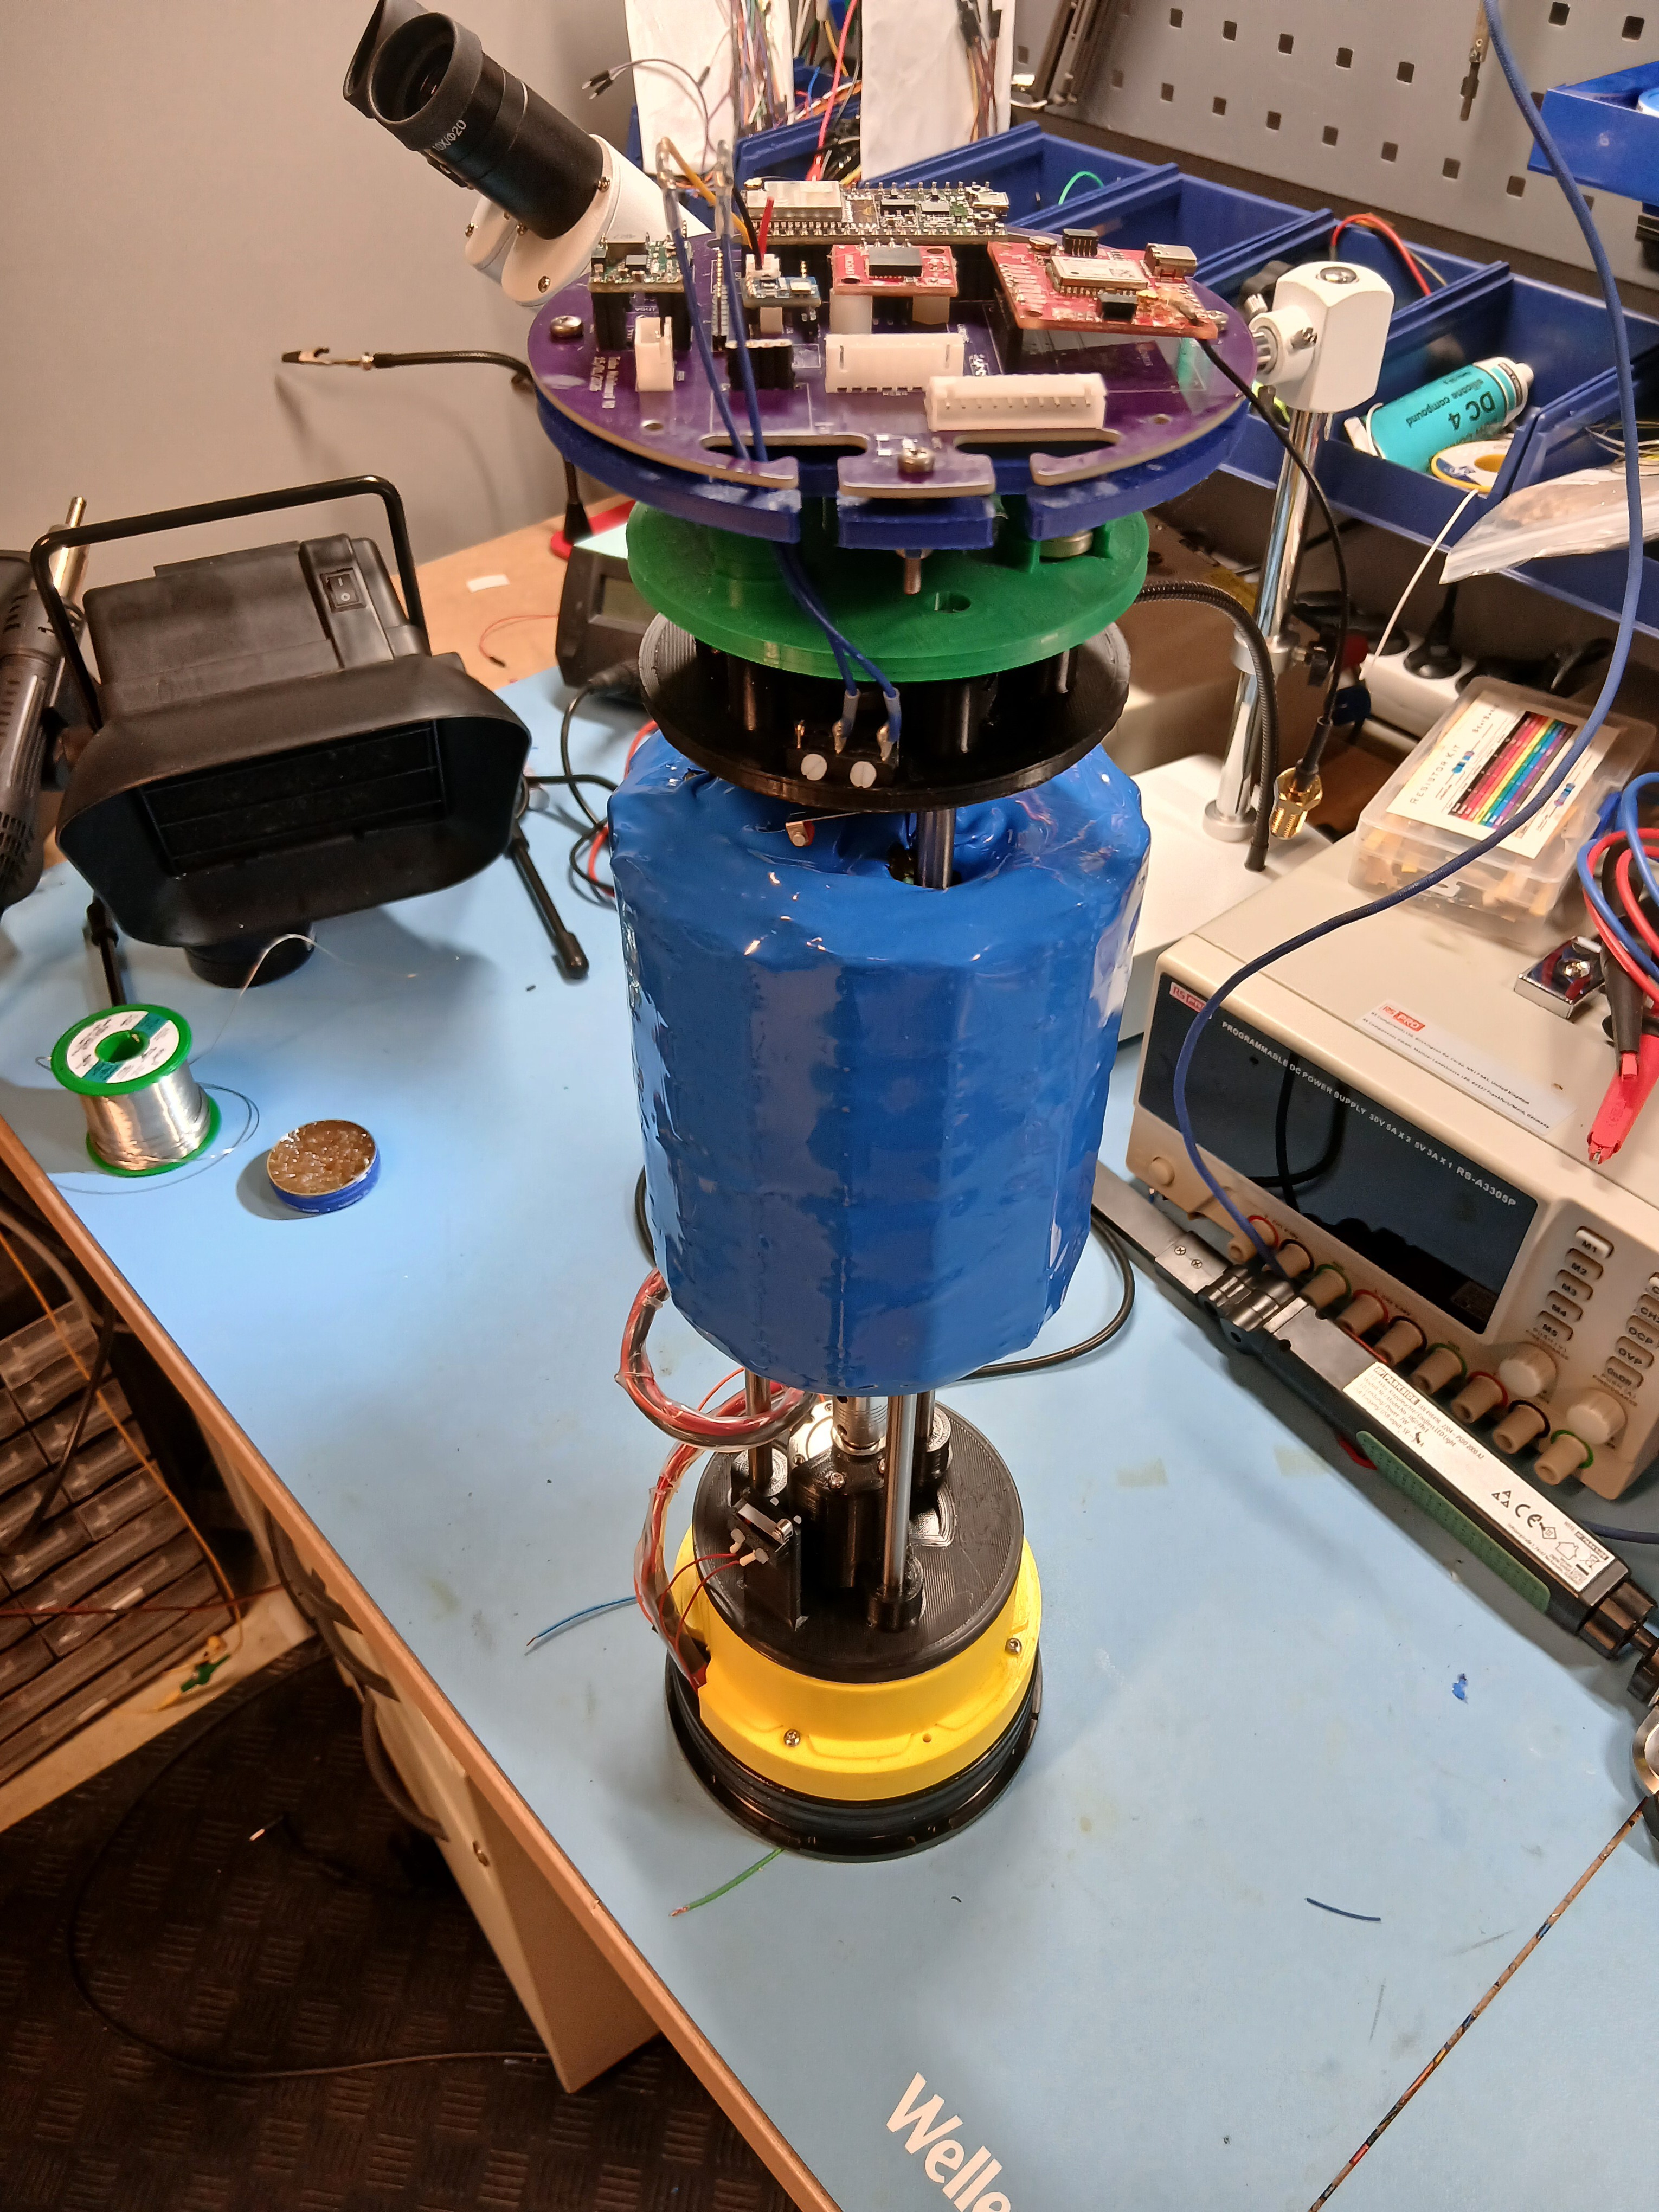
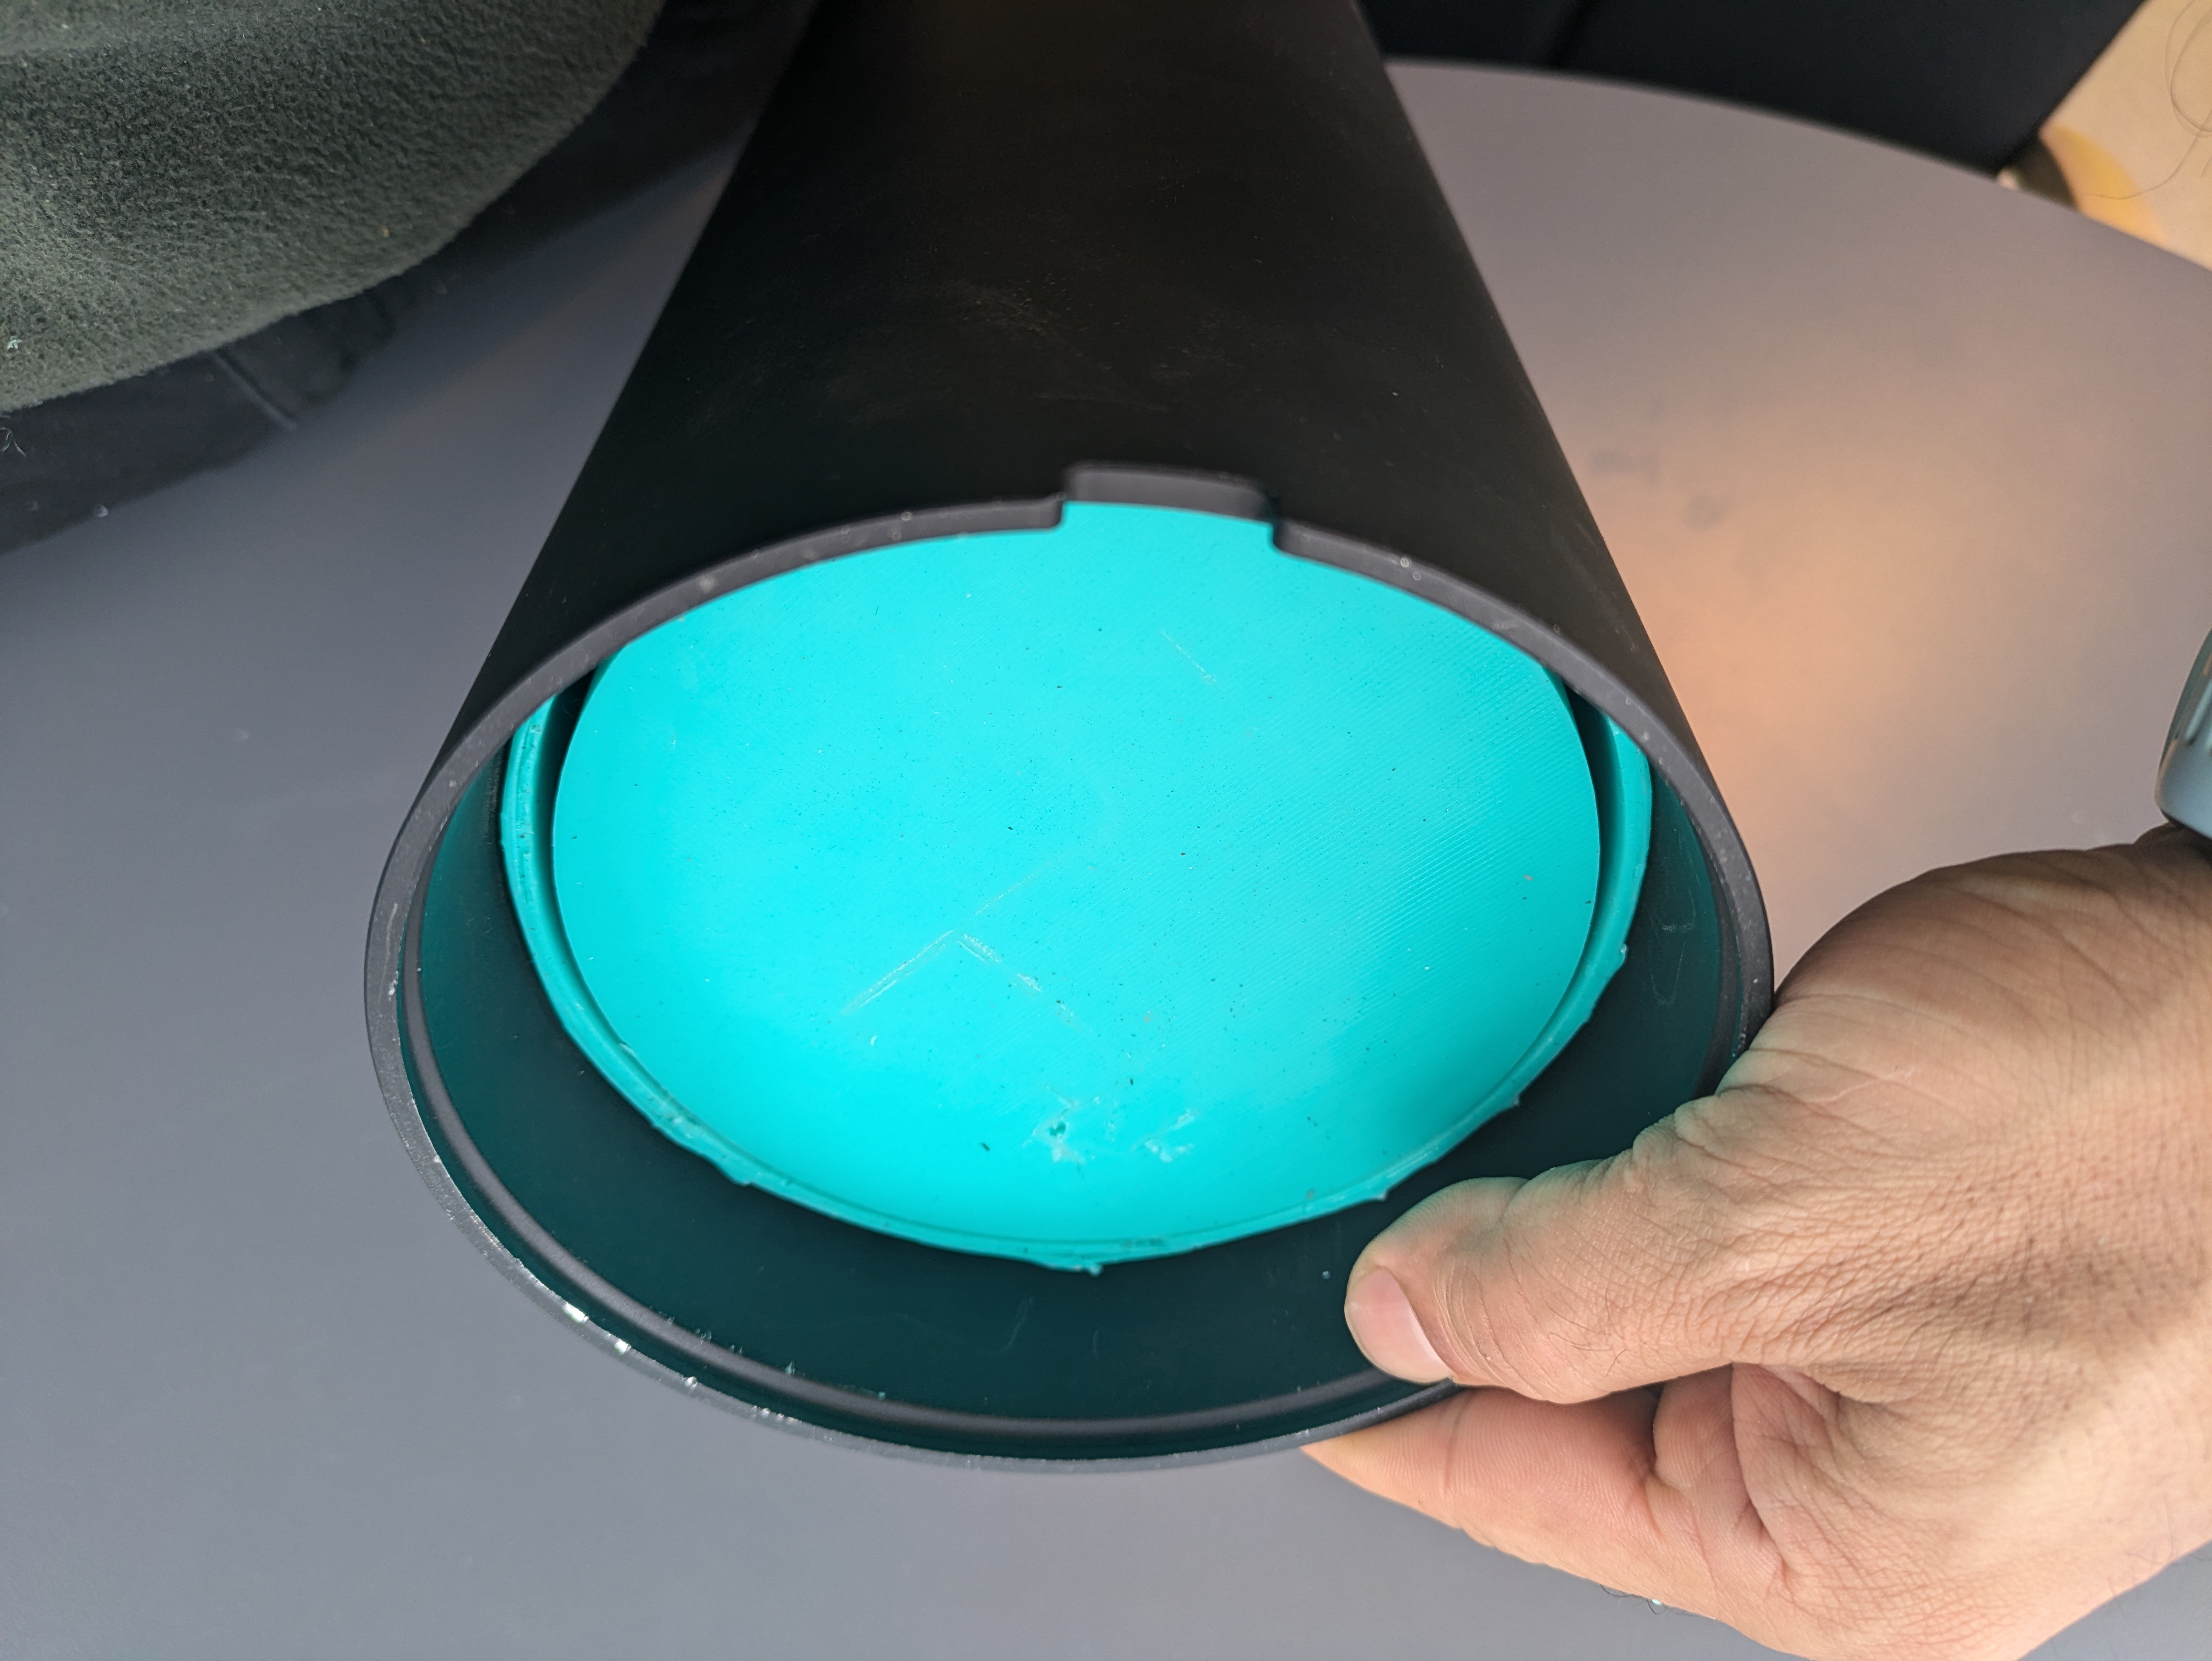
This glider will consist of three separate sections. These are buoyancy drive, mass shifter and electronics sections. Each section will be housed inside a 5" BlueRobotics pressure housing. This way, later we can upgrade the buoancy drive section to reach the full 1000m depth.
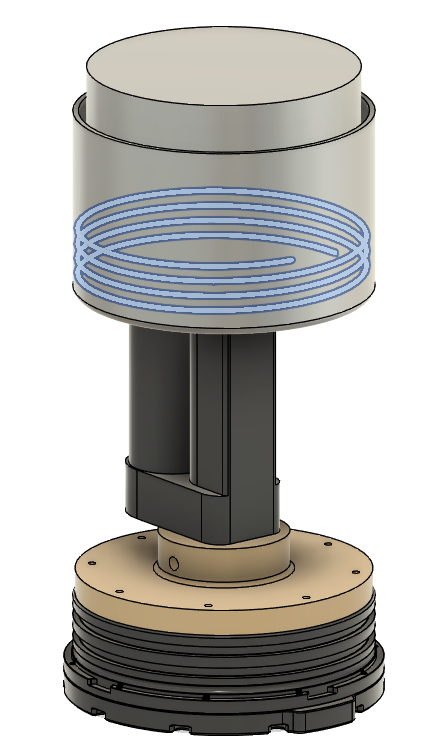
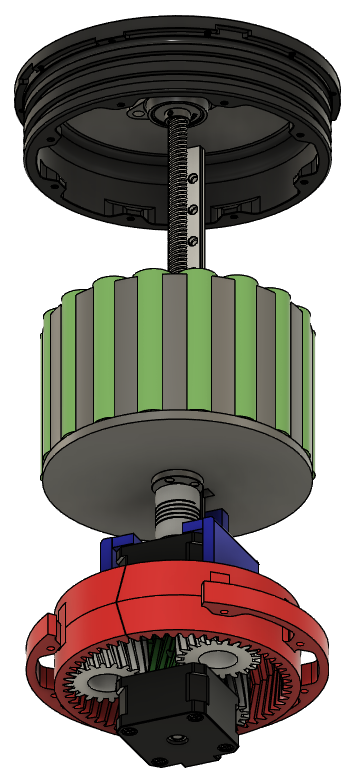
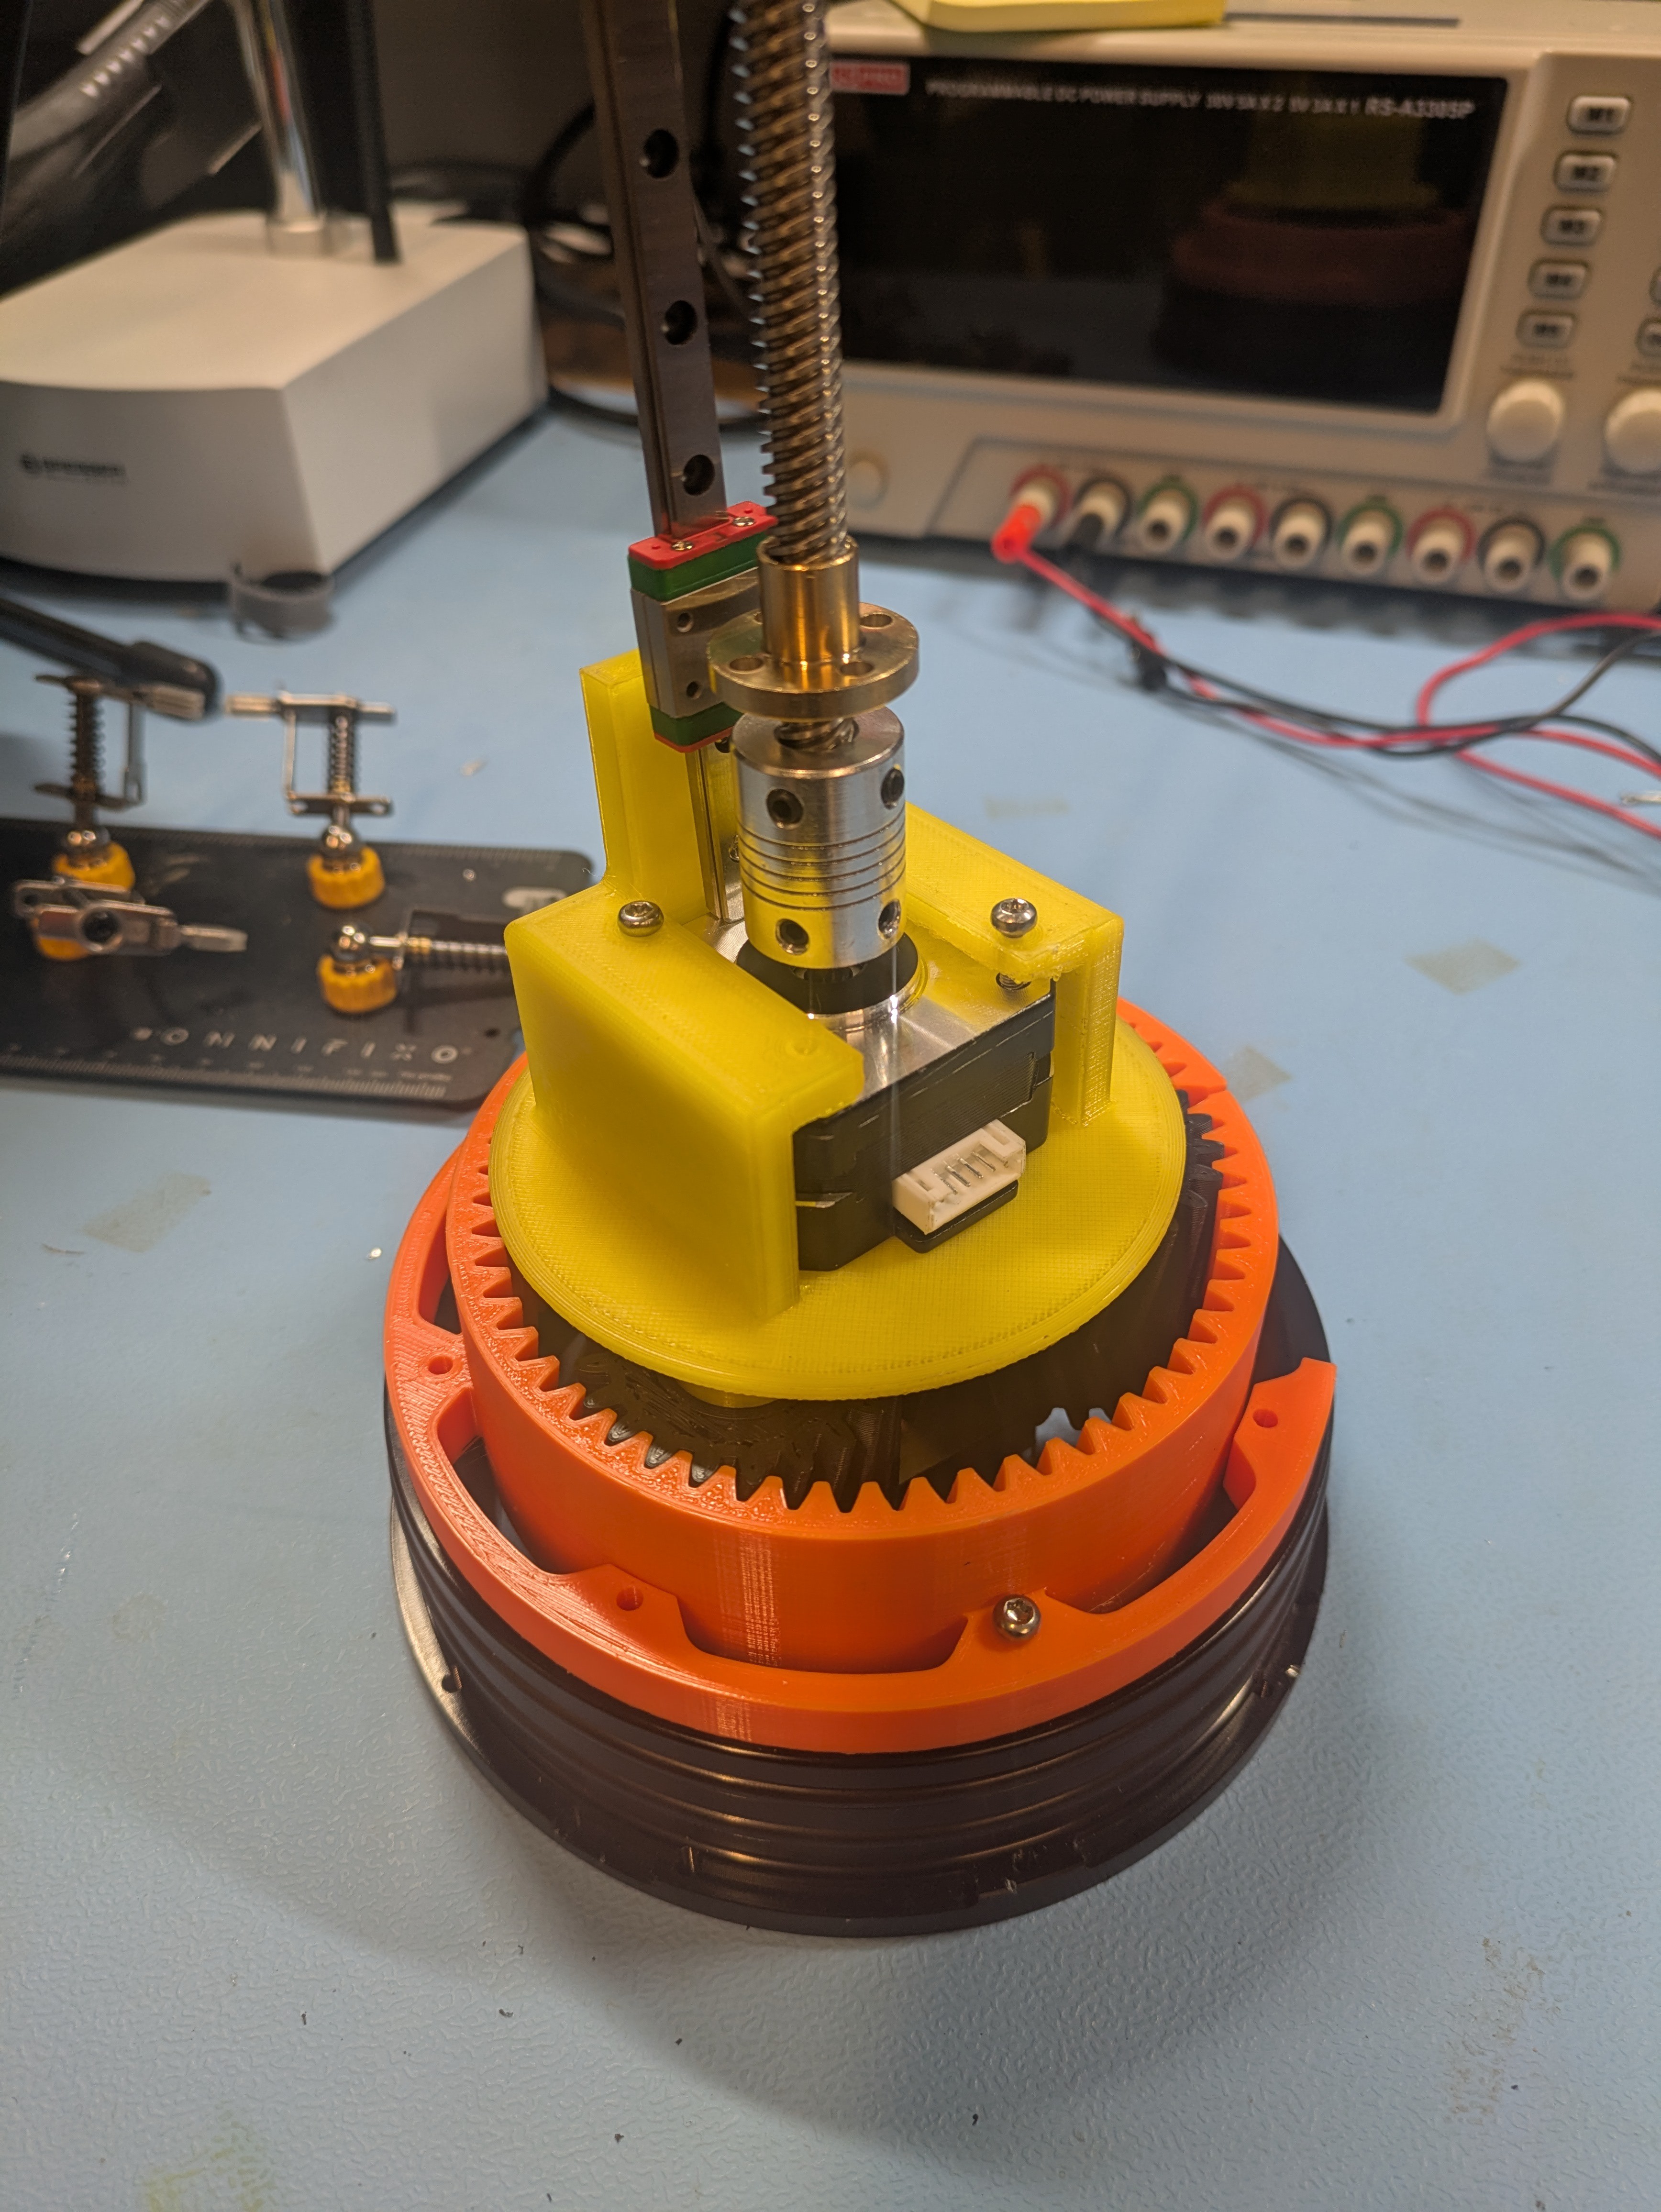
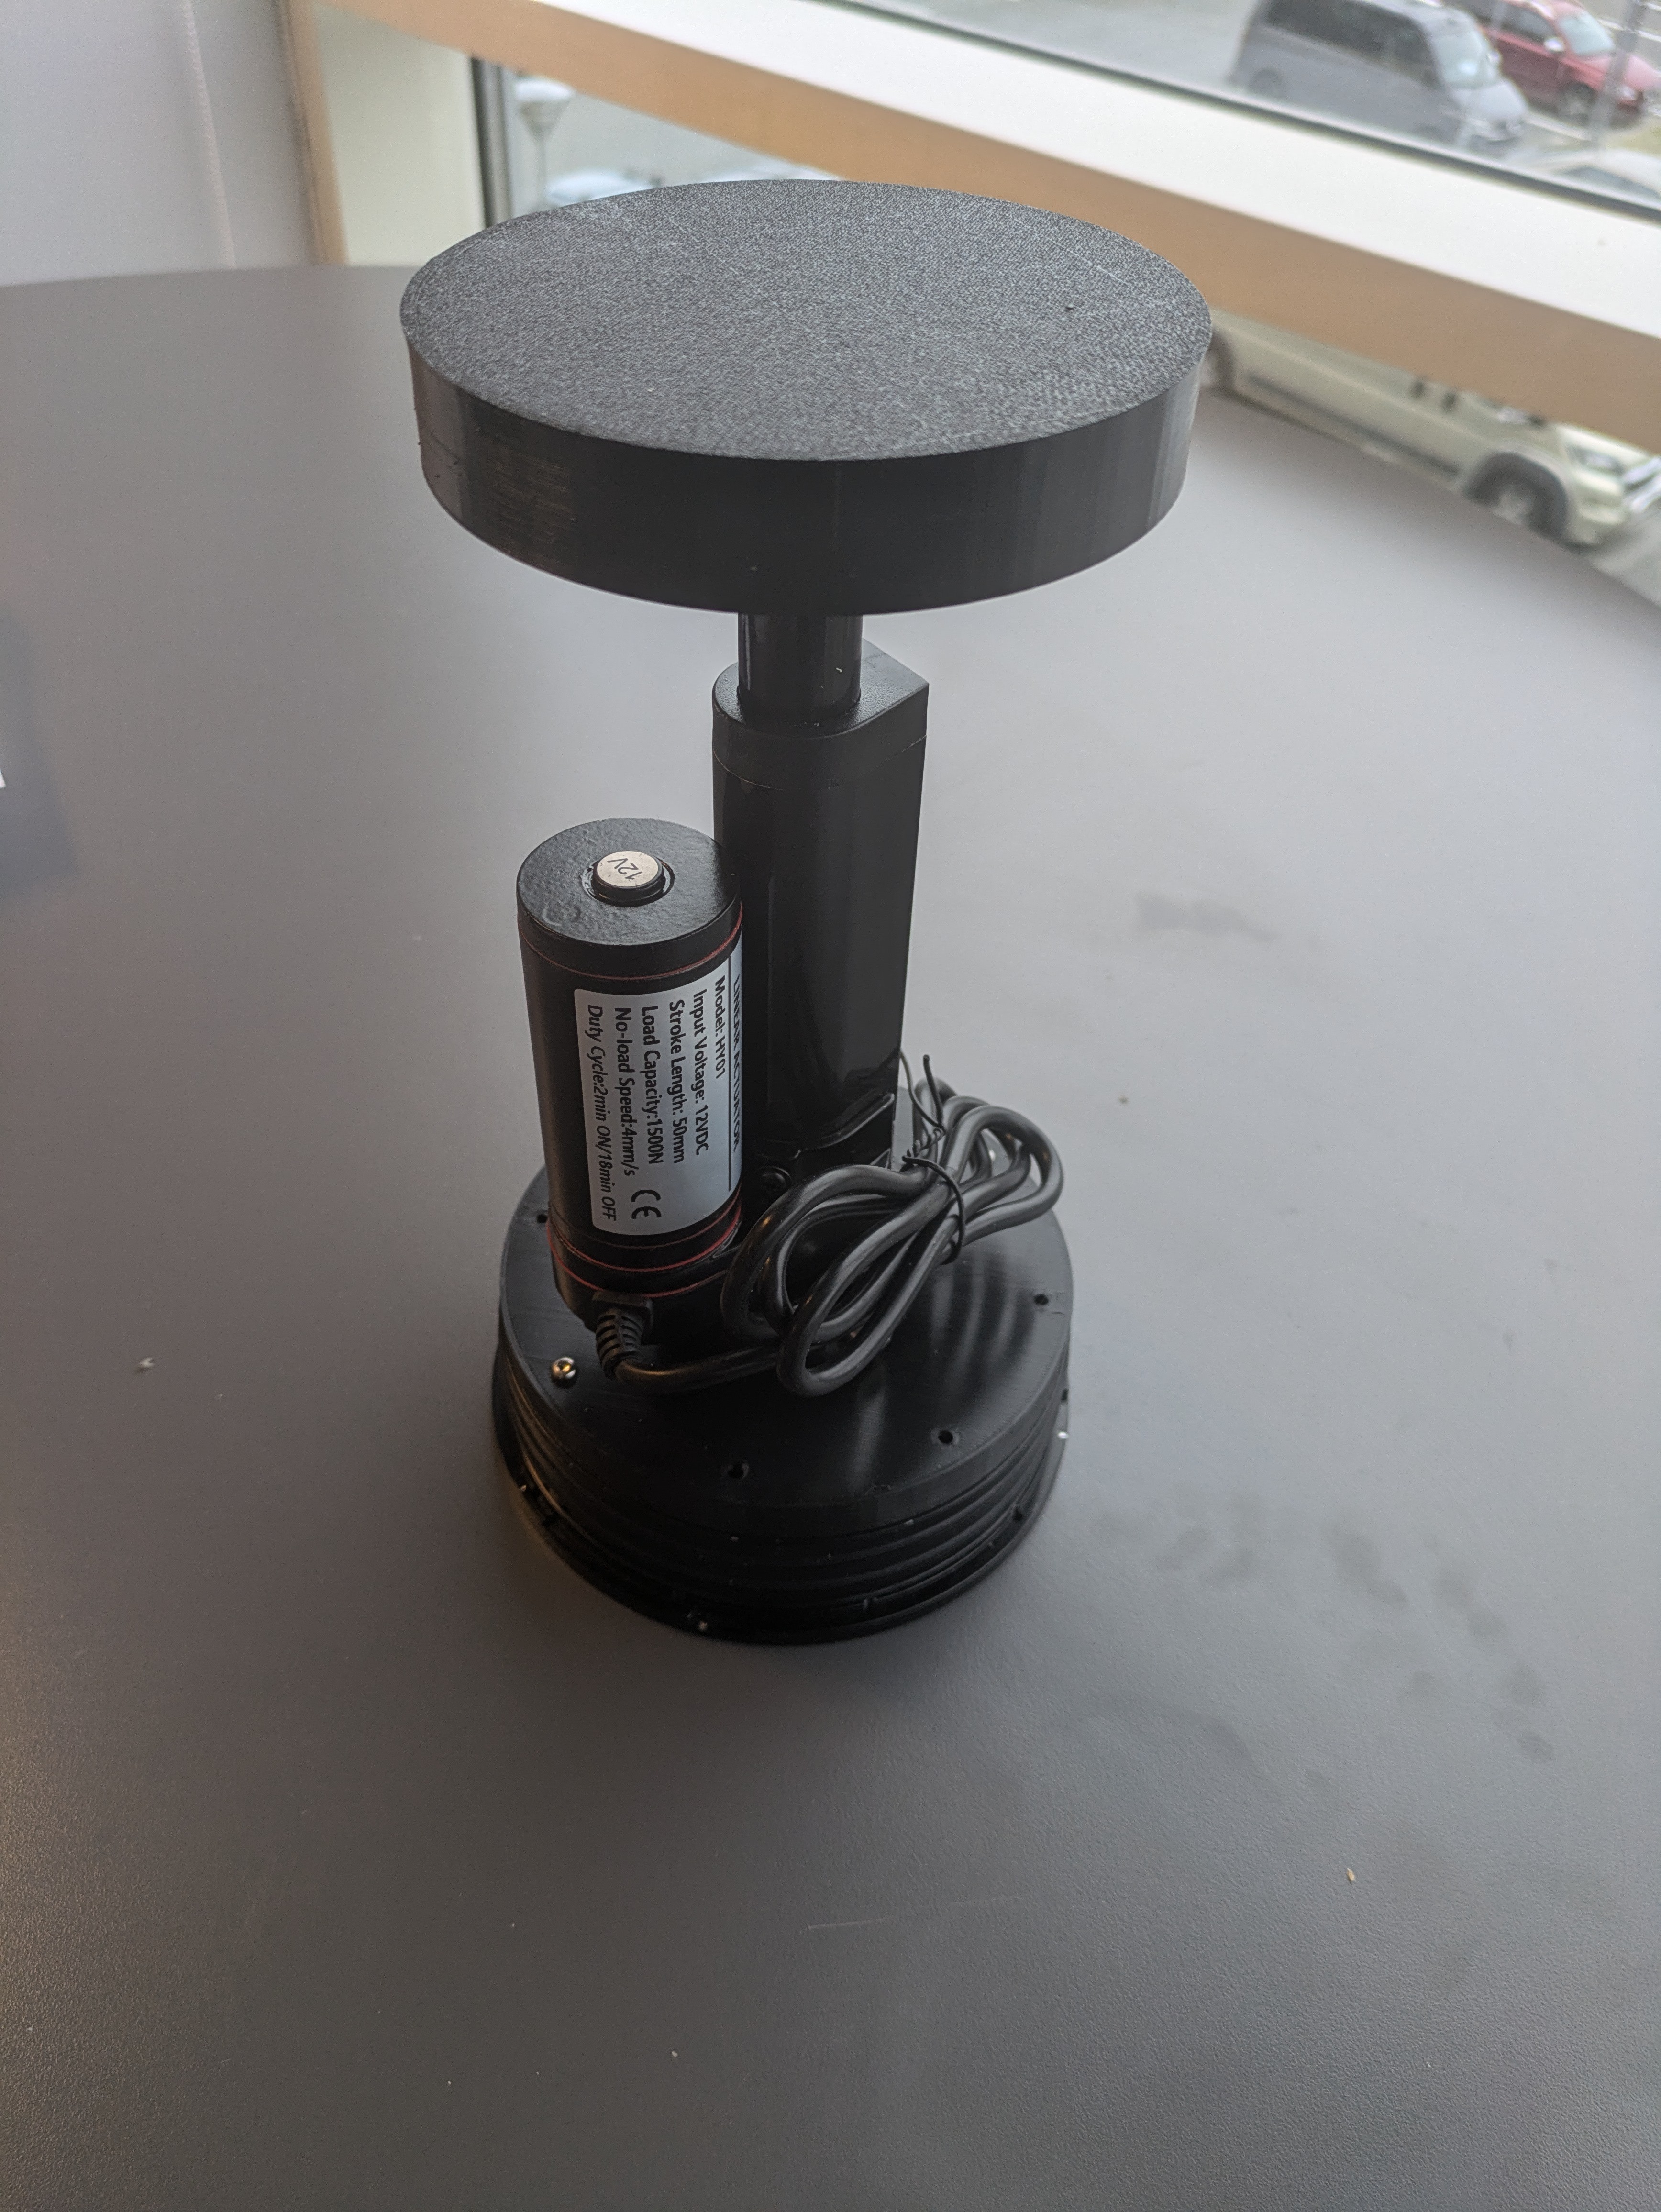
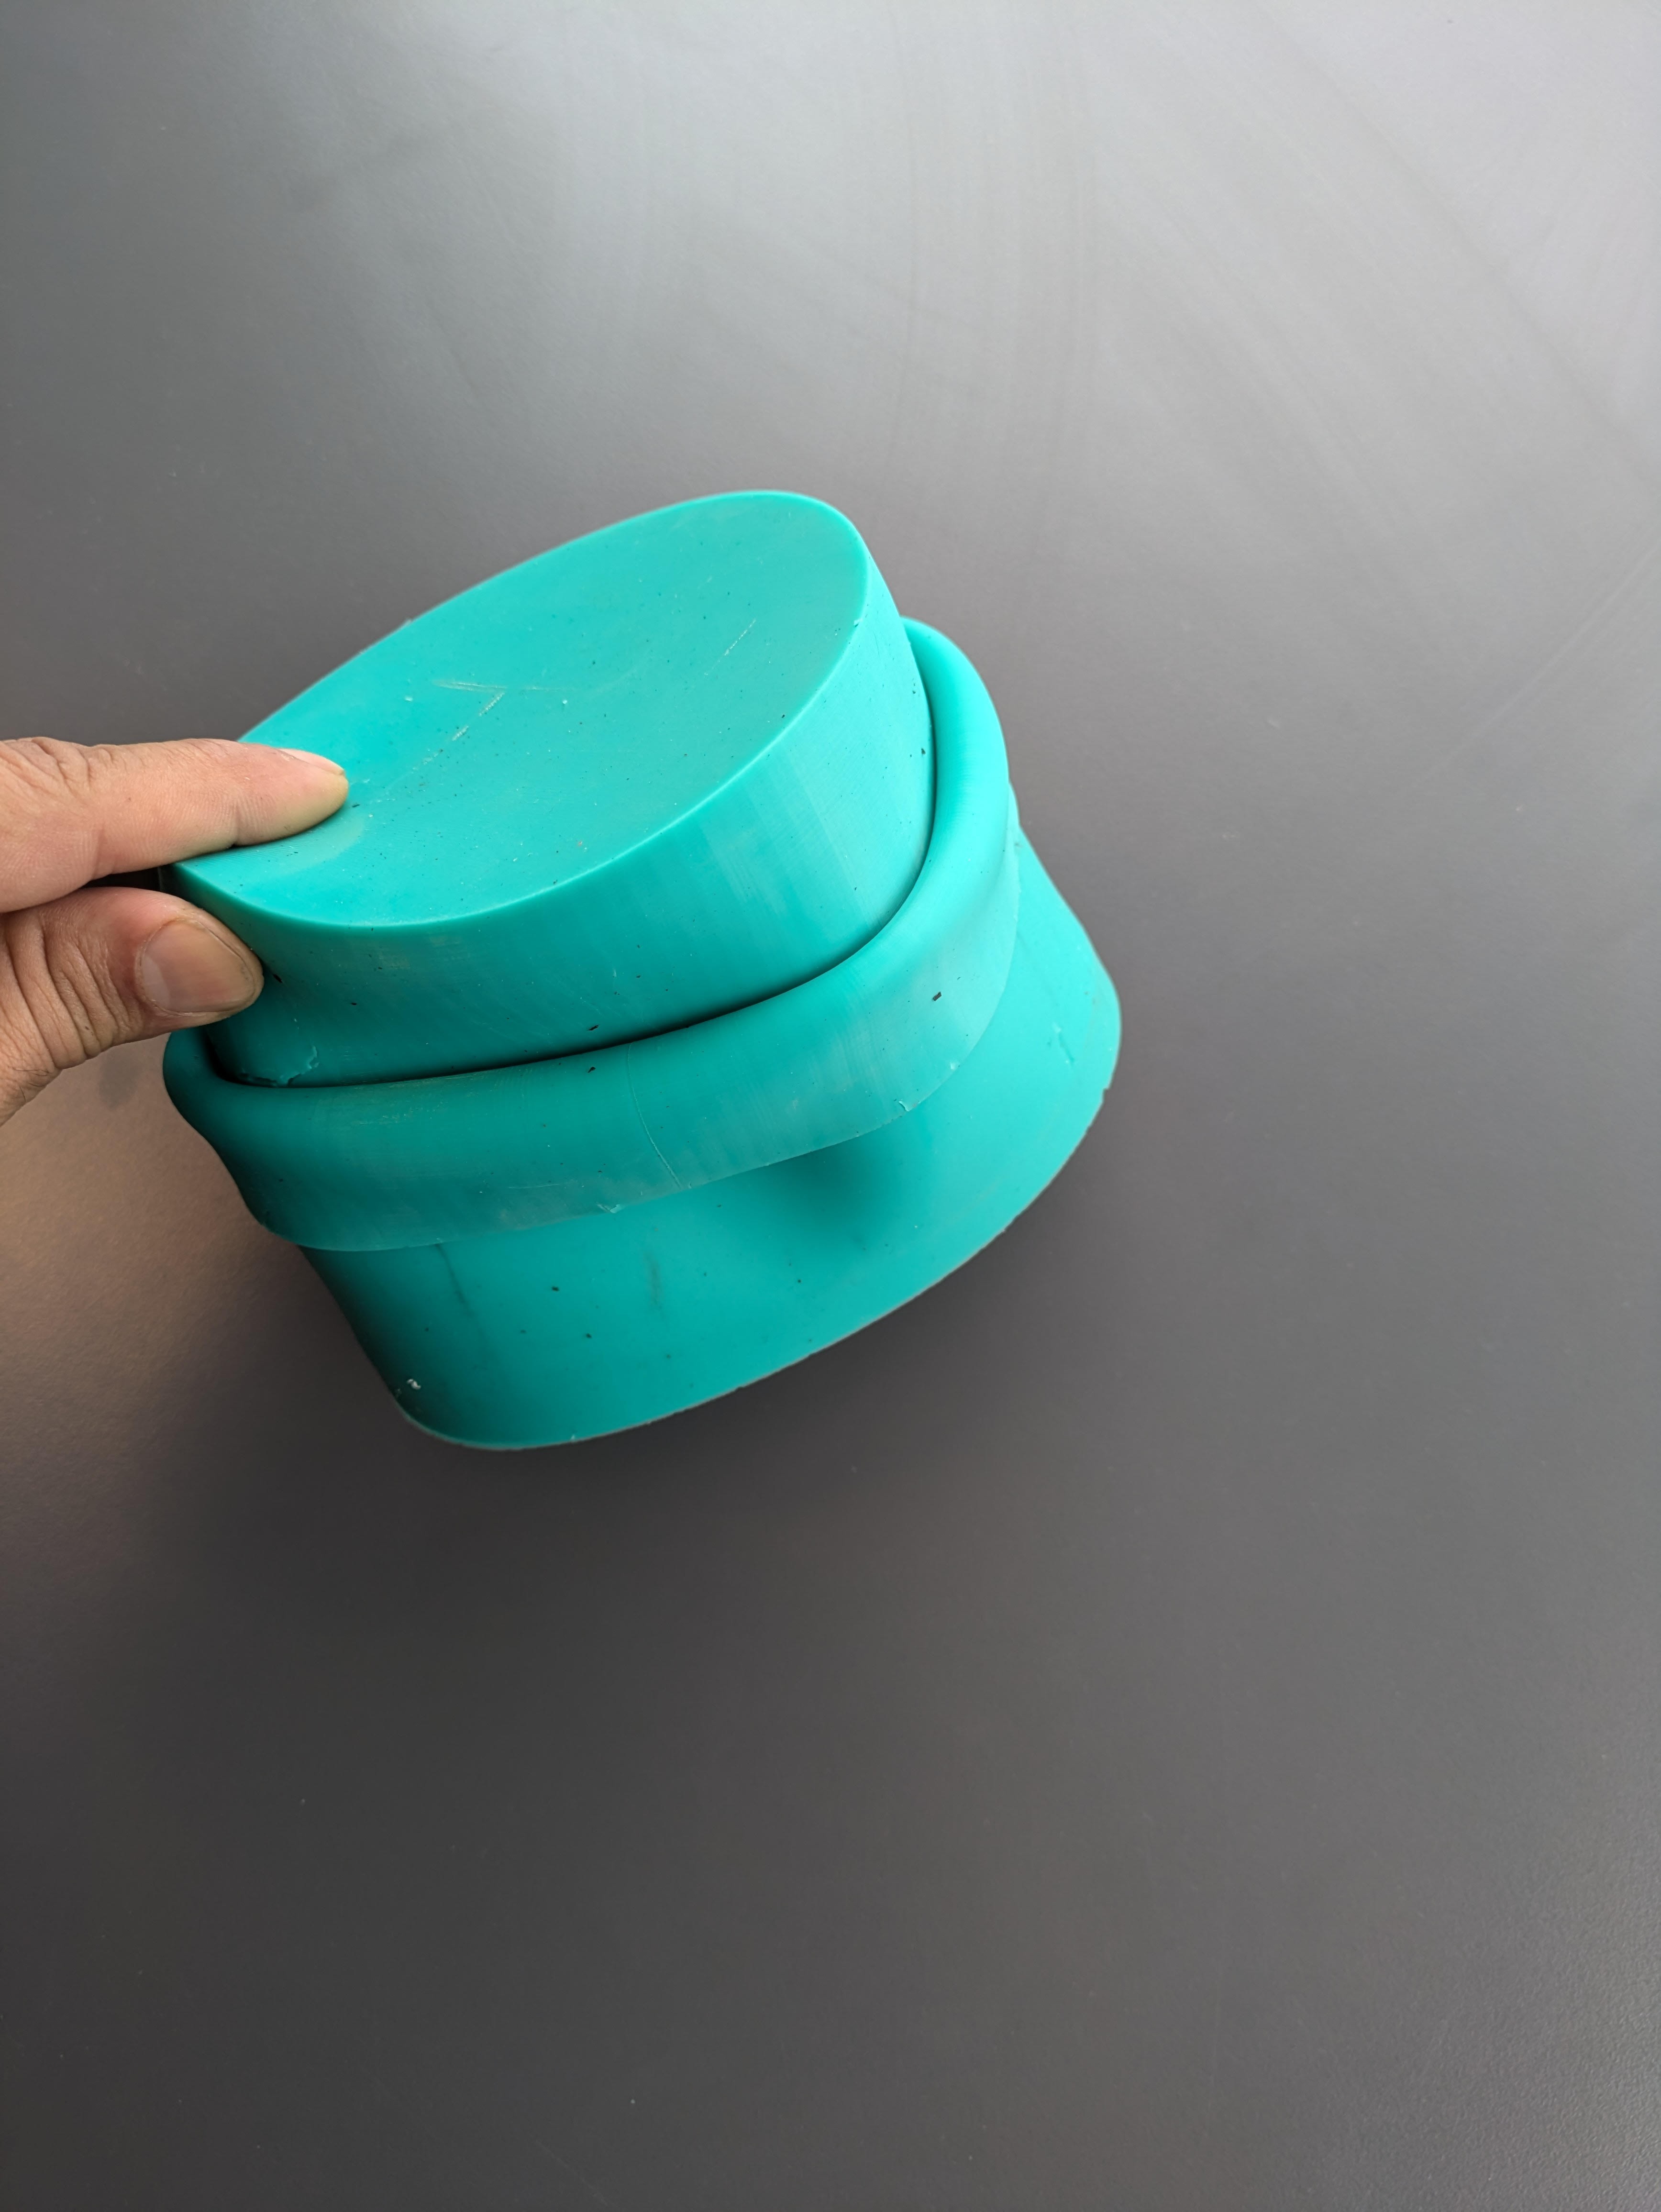
Initially I will focus on making a simple but robust buoyancy drive system. This will inistially consist of a custom-made rolling diaphragm and a linear actoator. Next step is to focus on the mass shifter system. As for comms, I am planning to use LTE-M and LoRa at the beginning and maybe add Iridium at a later stage. The aim of this first build is to quickly and cheaply put together something functional and see what major changes needs to be done for the next version.

 kelu124
 Kenji Larsen
 BastelBaus
 Michael Barton-Sweeney