 R Lang
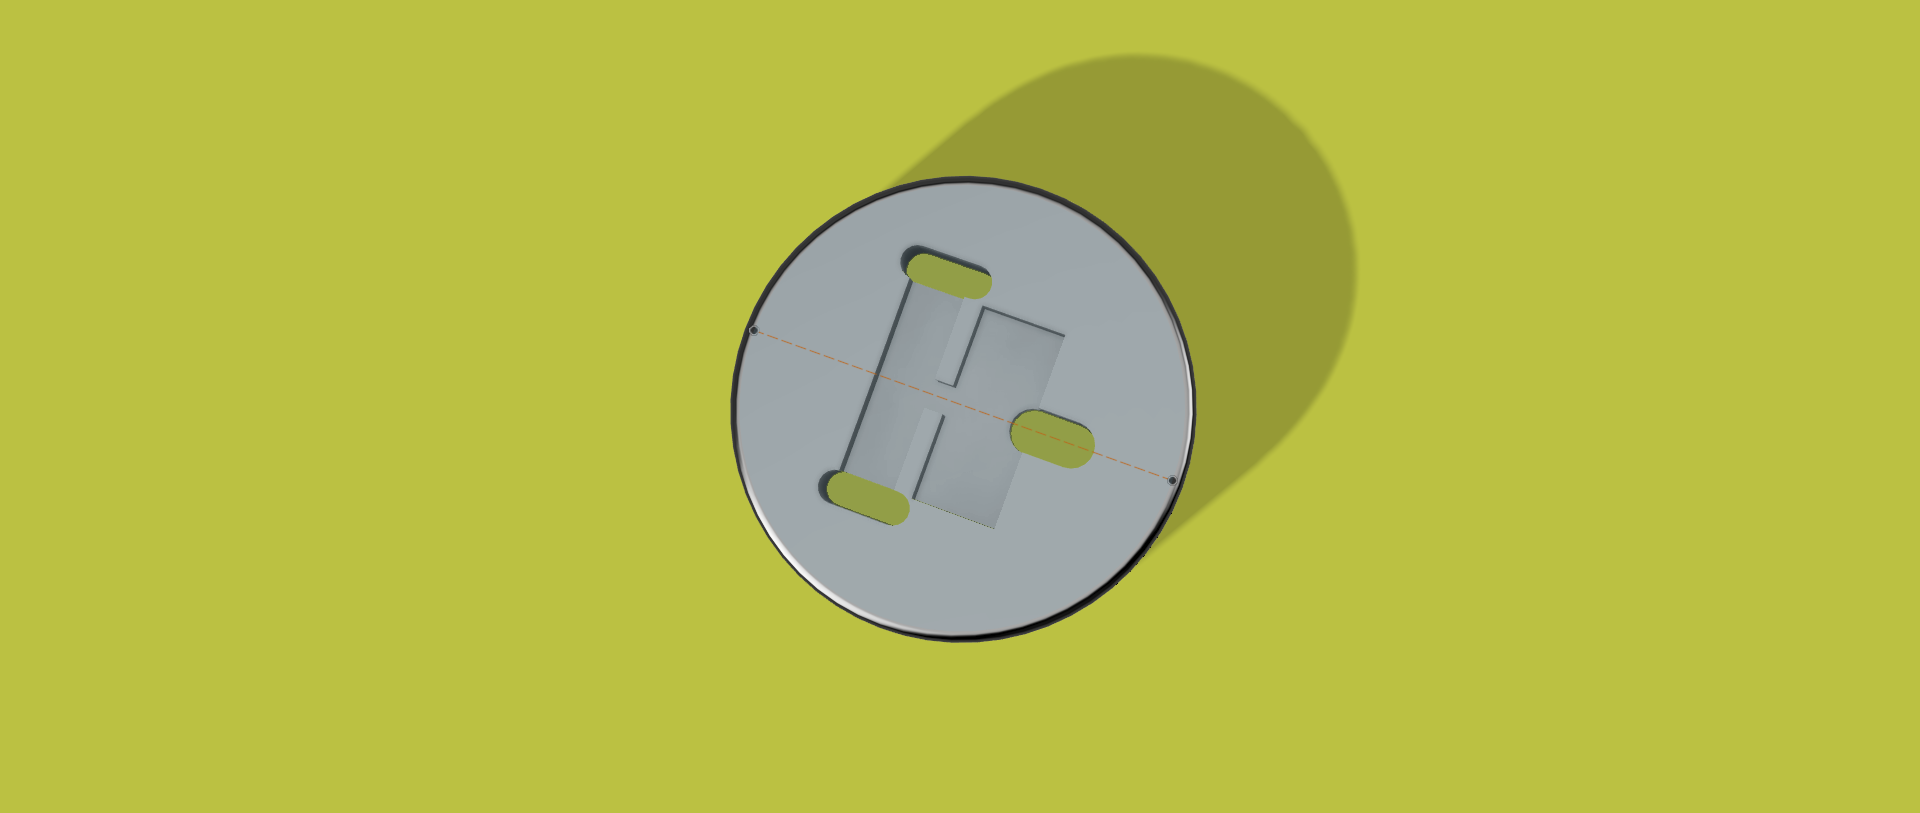
Although this doesn't represent the finalised design, this is generally the direction I've chosen to go. The idea of this will be to test the ability of Tortuga to drive on sand and to test out a number of things:
A. Ingress of sand into the electronics
B. If low pressure, slick tyres will adhere enough on sand
C. How accurately can Tortuga steer in such a small form factor.
My initial thoughts are the front wheel will need more room to manoeuvre - maybe a castor based wheel, if not, depending on the level of difficulty in implementing, regenerative steering/differential steering - the same thing that allows tanks to perform "neutral turns" (tank donuts).
Discussions
Become a Hackaday.io Member
Create an account to leave a comment. Already have an account? Log In.