This project is a fully discrete stepper motor driver built from basic electronic components (MOSFETs, resistors, standard logic) rather than using black-box commercial ICs like A4988. The primary goal is educational: to create an open architecture that allows engineering students to visualize phase stepping sequences, probe gate signals with an oscilloscope, and physically understand H-Bridge operation and thermal dissipation under load. Currently in the perfboard prototyping phase.
Following the gate signal analysis, the next critical validation step for this discrete stepper driver is thermal stability under a sustained holding torque state. Stepper motors draw their maximum current when stationary, placing the highest thermal stress on the H-Bridge MOSFETs. Test Methodology: The NEMA 17 stepper motor was energized and locked in a holding position. Temperature readings were taken from the heatsinks of the high-side (IRF9540) and low-side (IRLZ44N) MOSFETs over a 10-minute continuous load period. Ambient room temperature was 23°C. Thermal Data Results:
Engineering Conclusion: The data shows a stable thermal curve that begins to plateau around the 10-minute mark. The heatsinks are effectively dissipating the power . Notably, the low-side IRLZ44N runs approximately 6°C hotter than the high-side IRF9540. This confirms our earlier oscilloscope observations: the low-side MOSFET is not only handling the continuous holding current but is also subjected to micro-conduction from the Miller effect and switching losses during state changes. A maximum temperature of 46°C is well within the safe operating area (SOA) of the silicon, proving this discrete architecture is robust enough for continuous operation without active cooling.
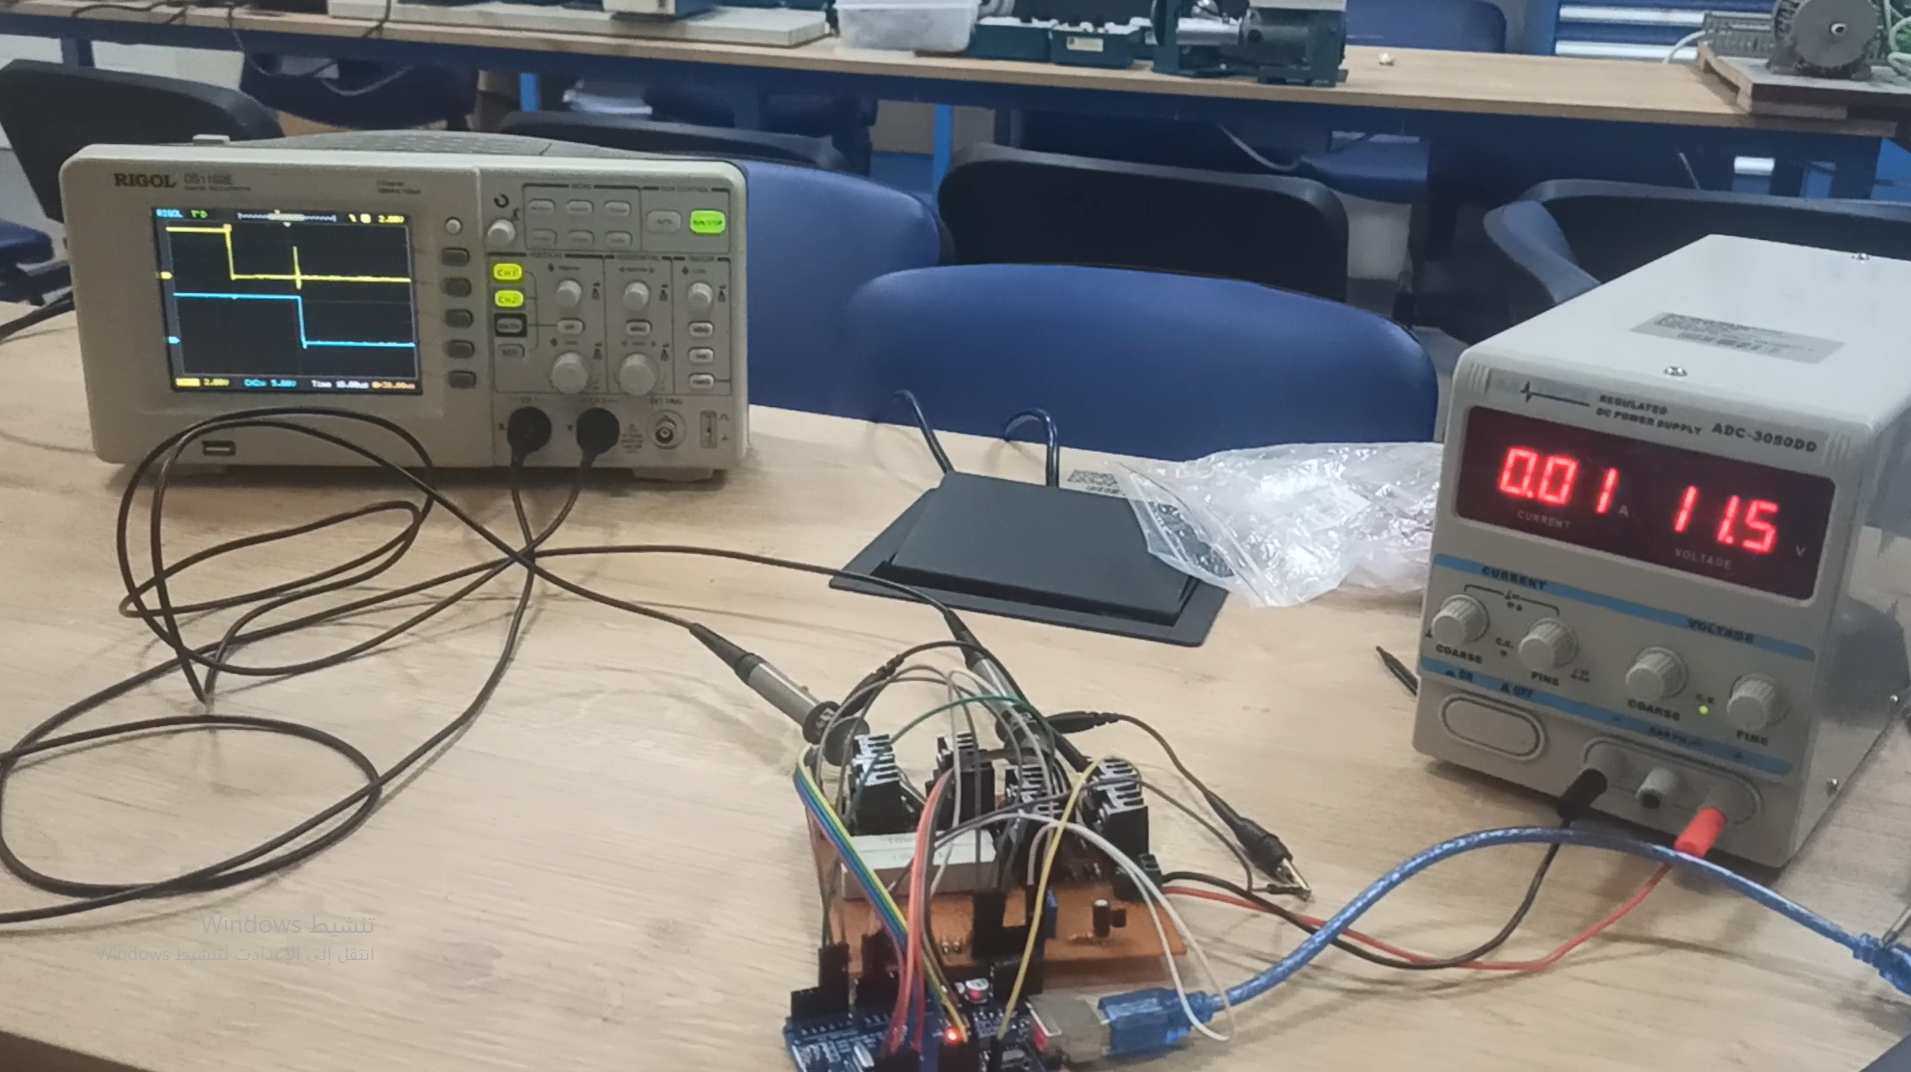
In this log, I hooked up a Rigol DS1102E oscilloscope to probe the gate signals of the H-Bridge under no-load switching conditions. The primary goal was to verify the programmed dead-time and observe the switching characteristics of the discrete MOSFETs. Observations: As seen in the attached trace, the dead-time logic successfully prevents a direct shoot-through. However, a noticeable phenomenon occurs during the high $dv/dt$ transition. The oscilloscope captured a voltage spike of approximately 2V on the low-side IRLZ44N gate when the high-side IRF9540 switches. Engineering Analysis: This is a classic demonstration of the Miller Effect (induced via parasitic drain-to-gate capacitance C_gd. Because the IRLZ44N is a logic-level MOSFET with a V_gs ranging from 1.0V to 2.0V, this 2V spike is just enough to push the low-side transistor into slight micro-conduction. This perfectly explains the minor 10mA (0.01A) idle current draw visible on the bench power supply during switching, even without a motor connected. While this micro-conduction is not fatal and doesn't cause catastrophic thermal runaway at this scale, it is a valuable insight. For future iterations, decreasing the value of the gate pull-down resistors or implementing a dedicated gate driver IC to actively sink the Miller charge will be necessary to achieve a perfectly clean switching state.
The wiring complexity is intentional and functional.
This architecture requires 10 direct control lines from the MCU to drive the individual discrete stages (including the 2N2222 pre-drivers and logic-level low-side gates).
Additionally, 3 feedback lines are routed back to the MCU's ADC to read the voltage drop across the 0.1-ohm shunt resistors, allowing for real-time current sensing and active control.