Close
0%
0%

Makerfabs Nomad Terminal- 3.5" LoRa GNSS Handheld

Nomad devices are based on Lora,designed to communicate/ navigate, and deploy anywhere.

Similar projects worth following
Nomad devices are based on Lora,designed to communicate/ navigate, and deploy anywhere.

Makerfabs Nomad devices are based on LoRa,designed to communicate/ navigate, and deploy anywhere. It is a family of open-source LoRa devices designed for developers, makers, and industrial innovators. Combining long-range wireless communication, positioning, and edge intelligence, Nomad provides a flexible platform for building next-generation connected products.

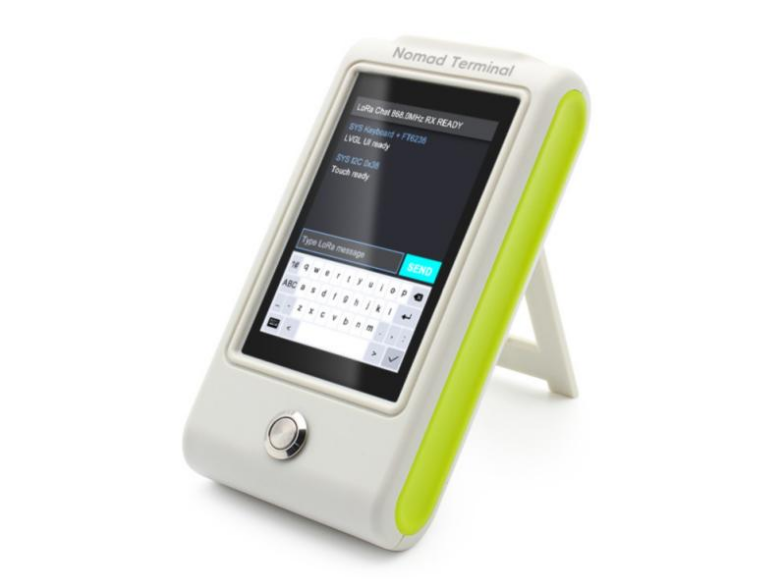
Nomad Touch is built around the ESP32-S3 and features a 3.5-inch capacitive touchscreen as its primary user interface. It supports development with Arduino, ESP-IDF, and LVGL, making it an ideal platform for rapid prototyping and product development.
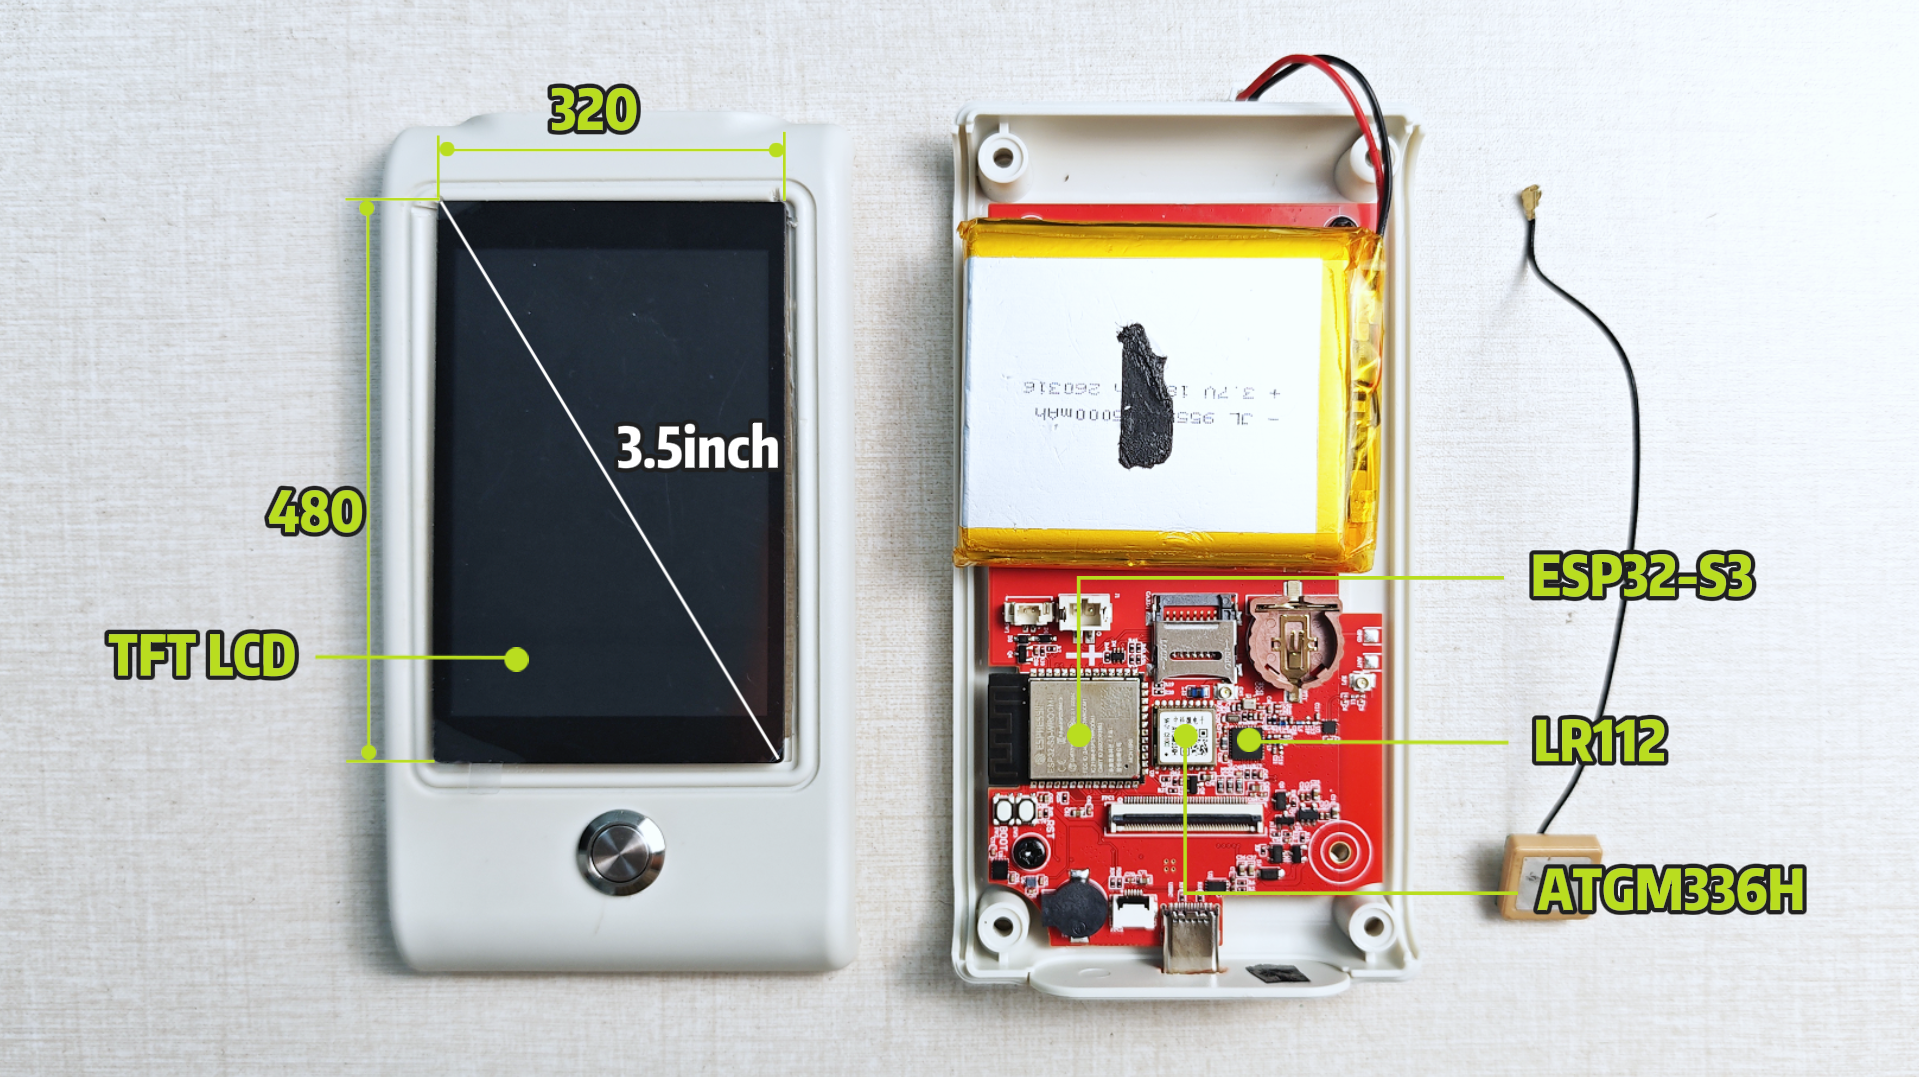
For long-range wireless communication, Nomad Touch adopts the Semtech LR1121 LoRa transceiver. Professionally tuned RF front-end and antenna provide reliable communication ranges of up to 8–10 km in open environments and 2–3 km in urban areas   

High-performance positioning is provided by the ATGM336H GNSS module together with an active GNSS antenna ensure reliable GNSS performance. The GNSS subsystem features an average operating current of 28 mA, with a cold-start time of 32 seconds and a hot-start time of 2 seconds..

To support navigation, motion sensing, and off-grid applications, Nomad Touch also integrates a 9-axis IMU and a real-time clock (RTC), providing a complete hardware platform for outdoor, industrial, and IoT applications.

With Nomad Terminal, user can create:

1. Off-Grid Communication
Build reliable off-grid messaging applications without relying on cellular networks. Powered by the Semtech LR1121 and Makerfabs' professionally optimized RF design, Nomad Touch provides communication ranges of up to several kilometers, making it ideal for:

  • Camping & Hiking
  • Emergency Communications
  • Search & Rescue
  • Disaster Recovery
  • Remote Field Operations
  • Areas without LTE or Internet coverage 

2. GNSS Position Sharing
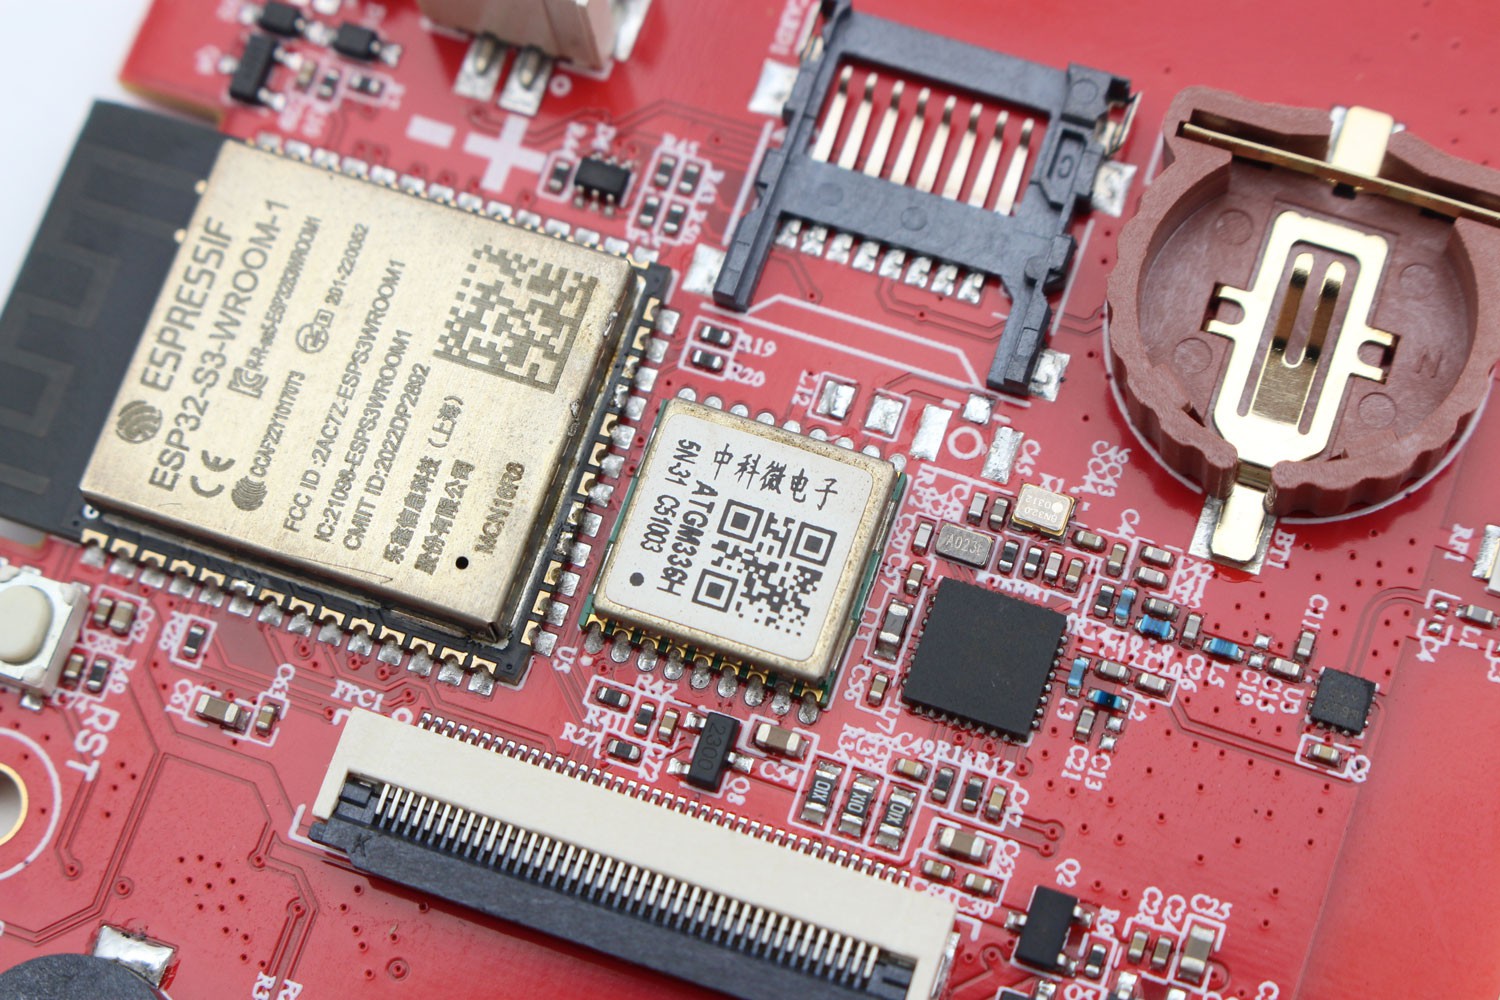
With its integrated GNSS receiver, Nomad Touch can acquire and share real-time location information with other Nomad devices over LoRa. This makes it suitable for Disaster Recovery/ Rescuing.

3. Motion & Navigation
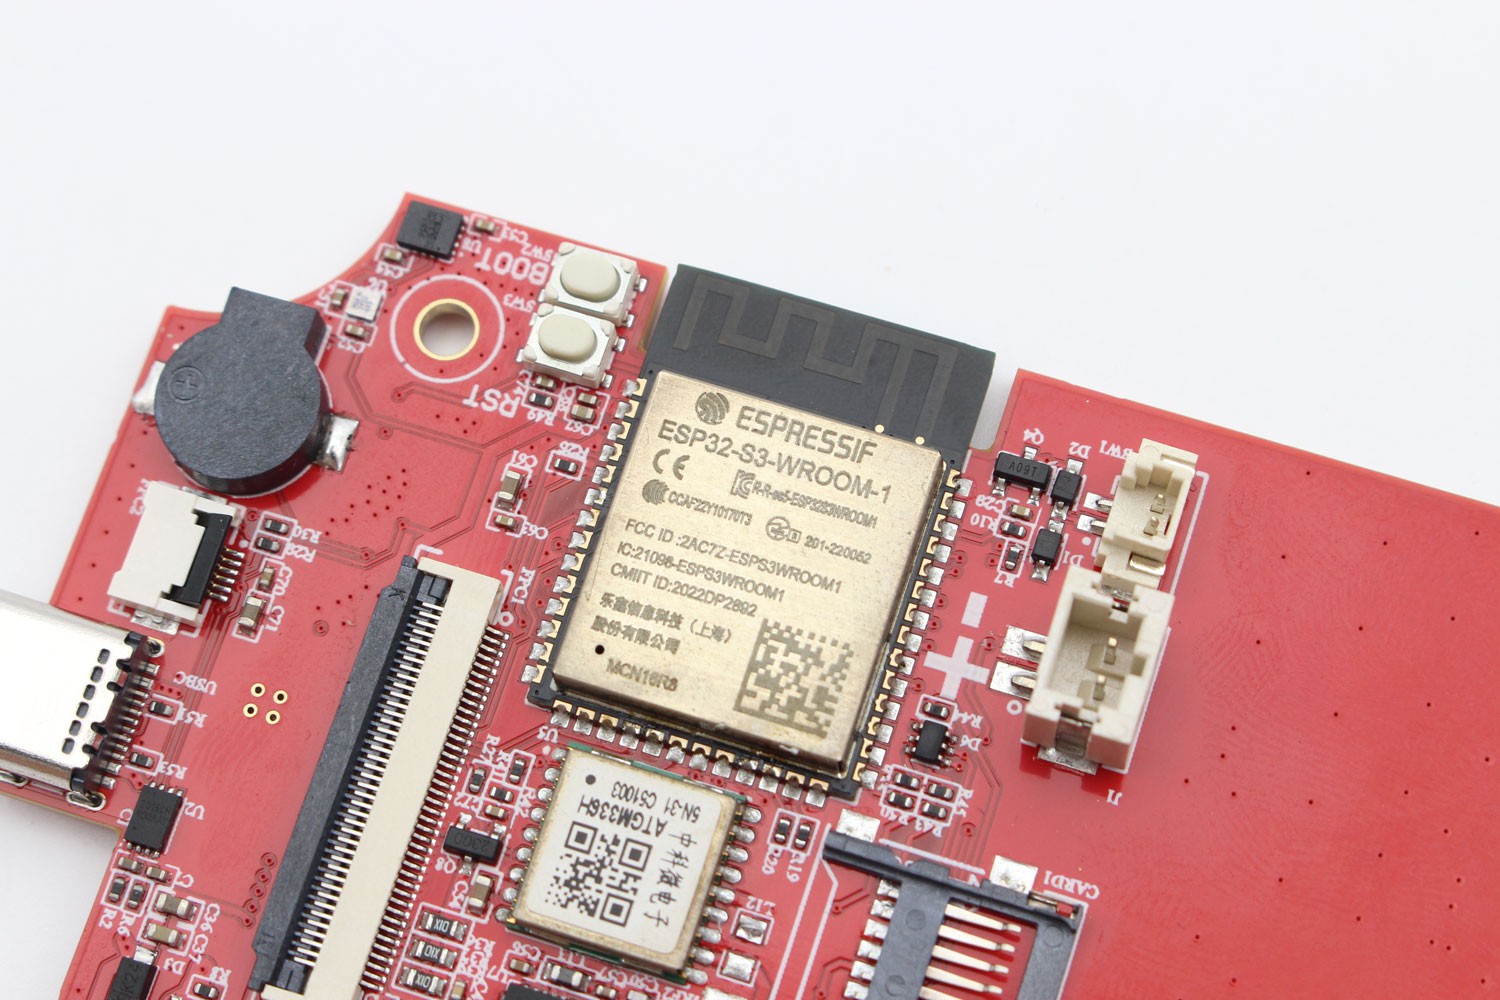
The integrated 9-axis IMU provides motion sensing, orientation, and heading information. Combined with GNSS, it enables more advanced navigation and tracking applications, especially in challenging outdoor environments.

Nomad Touch integrates a 5000 mAh rechargeable Li-ion battery with onboard charging circuitry.

Thanks to its ultra-low-power hardware design, battery life can reach 40–60 days, depending on the application, LoRa transmission interval, GNSS usage, and display activity.

Fully Open Source

Both the hardware and firmware of Nomad Touch are fully open source, giving developers complete freedom to customize, modify, and build their own applications.

Spec:

  • ESP32S3, 16M flash with 8M PSRAM
  • 480*320 SPI display with Capacitive Touch
  • LoRa: Semtech LR1121, 8–10 km range in open environments
  • GNSS: ATGM336H. With active antenna;
  • 6-Axis IMU (Accelerometer + Gyroscope): LSM6DS3TR-C;
  • 3-Axis Magnetometer: BMM150;
  • RTC: PCF8563T/5
  • Battery: 5000 mAH Rechargeable by USB Type-C
  • Exploring Nomad Terminal GPS Antenna Improvement From 8.2 to 5.2 Seconds

    Makerfabs09/01/2026 at 08:39 0 comments

    During product development, we tested the GPS antenna performance of two design generations.

    The first-generation design was functional, but its reception performance was not as good as expected. Based on the test results, we analyzed the antenna placement and redesigned the GPS antenna structure for the second generation. This redesign improved the Time to First Fix (TTFF) from 8.2 s to 5.2 s.


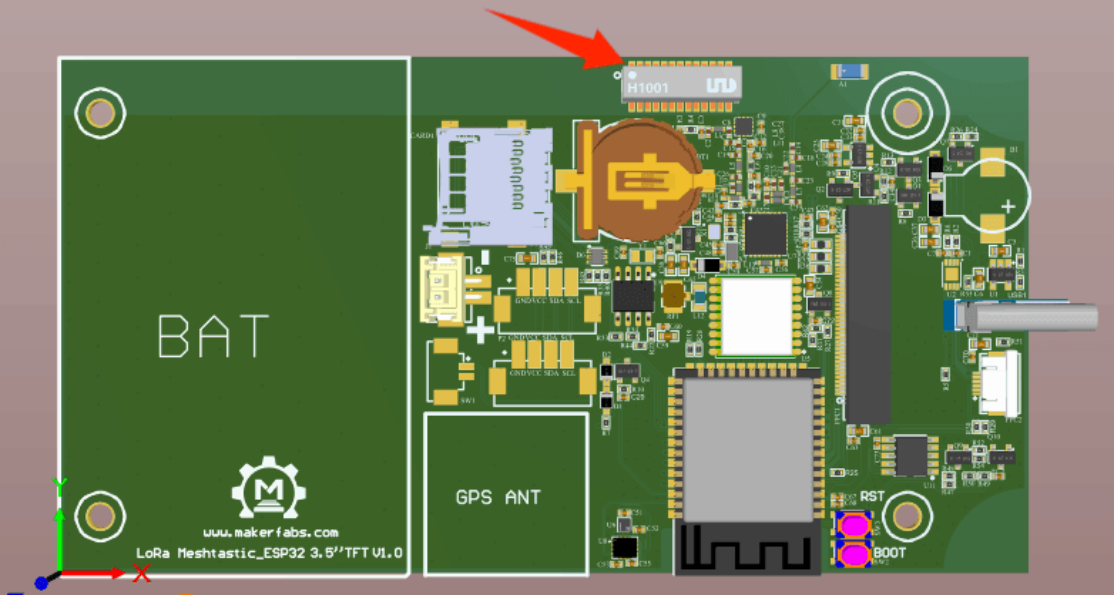
    V1.0: Passive Ceramic Antenna

    The first-generation product used a passive ceramic antenna.

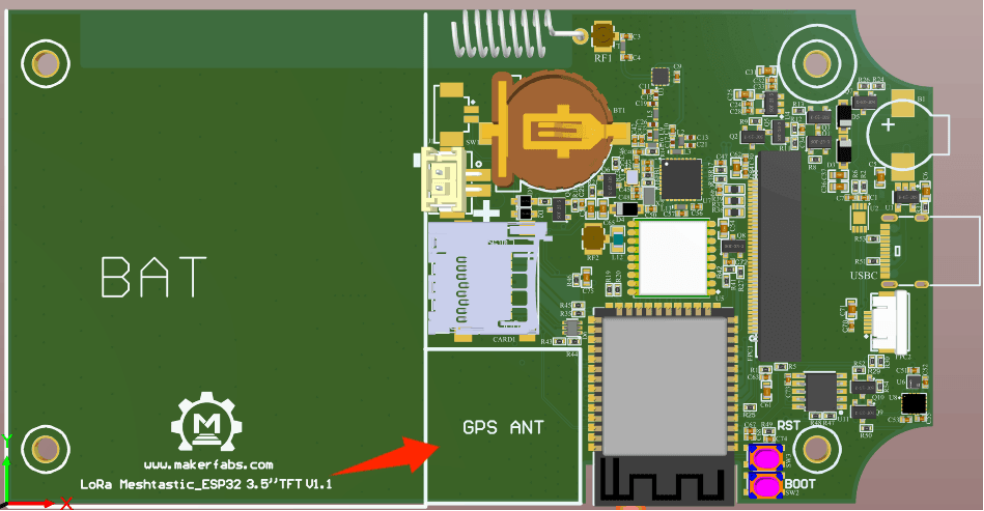
    To save space, it was mounted directly on the PCB, which made the product compact, but the actual GPS reception performance was not satisfactory.

    The display is positioned directly above the antenna, with metal components behind it, which negatively affects GPS signal reception.

    The battery and other components were too close to the antenna.

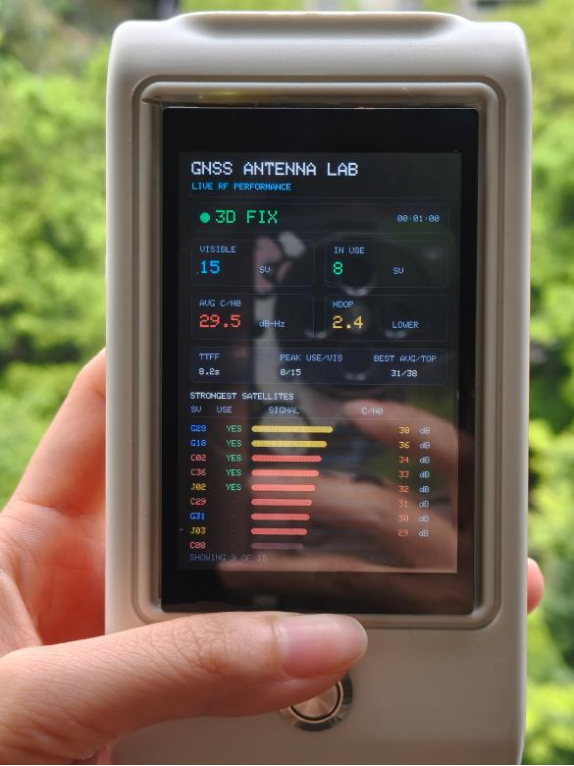
    The V1.0 test results were:

    • Time to First Fix (TTFF): 8.2 s
    • Visible satellites after 1 minute: approximately 15


    V1.1: Redesign for Better Reception

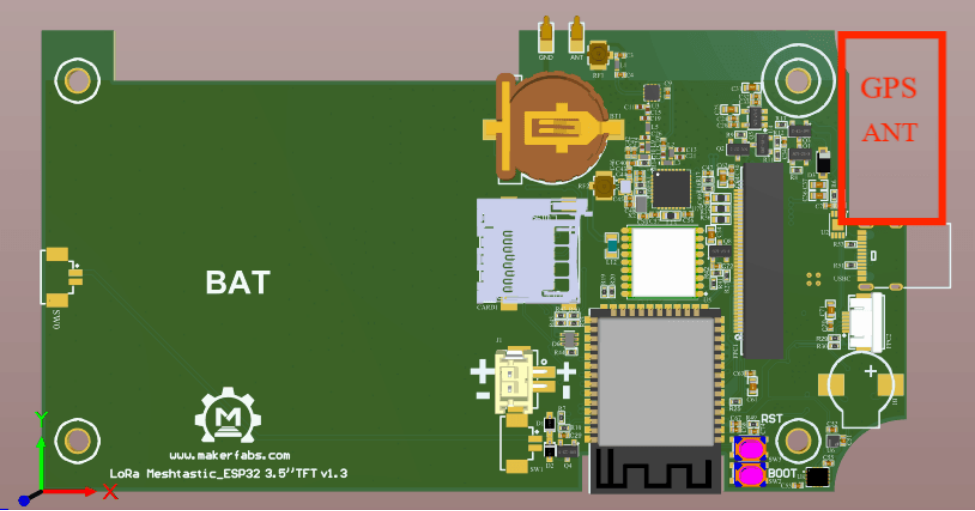
    Based on the first-generation test results, we redesigned the GPS antenna structure for the second generation.

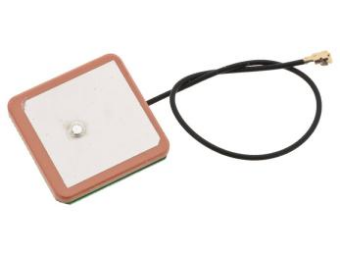
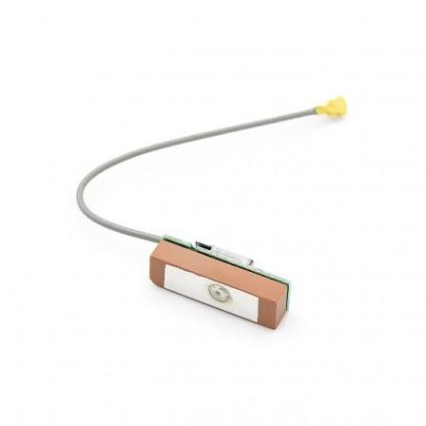
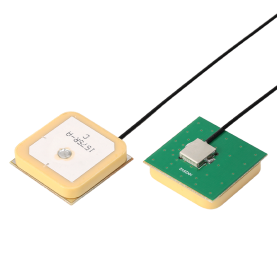
    The second-generation design uses an active ceramic antenna. Unlike a passive antenna, an active antenna integrates a low-noise amplifier (LNA) to boost the received RF signal before it reaches the GNSS receiver, helping improve reception in weak-signal environments.

    The antenna placement was also changed:

    • The antenna is positioned above the PCB and faces upward, with no major obstructions around it.
    • Whether the device is held in your hand or placed upright, the antenna remains pointed toward the sky.

    This redesign directly addressed the main limitations identified in the V1.0.


    Small active ceramic Antenna Test

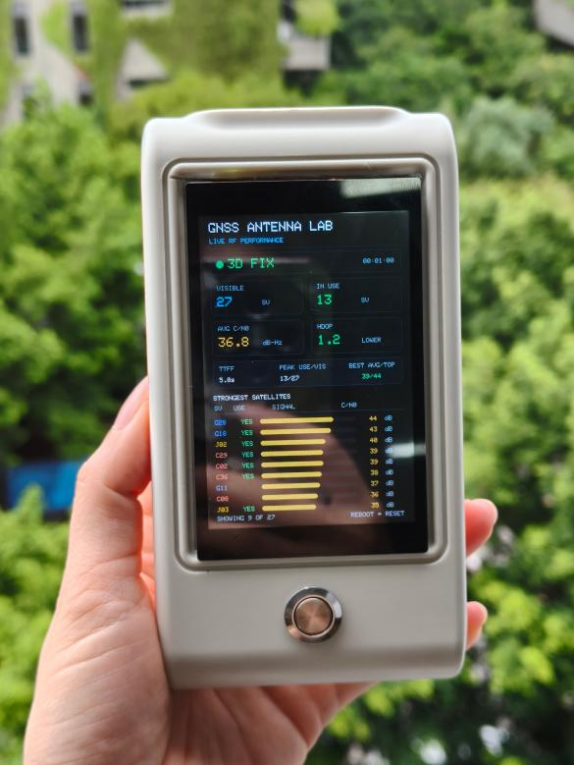
    We first tested a small active ceramic antenna in the V1.1 design.

    The results showed a clear improvement compared with the first-generation passive antenna:

    • Time to First Fix (TTFF): 5.8 s.
    • Visible satellites after 1 minute: approximately 27

    This confirmed that the active antenna design and upward-facing placement were effective.

    However, the small antenna still did not fully meet our expectations. Although the performance was better, there was still room to improve signal strength and satellite visibility in some environments.

    For this reason, we continued testing with a larger active ceramic antenna.


    Large active ceramic Antenna Test

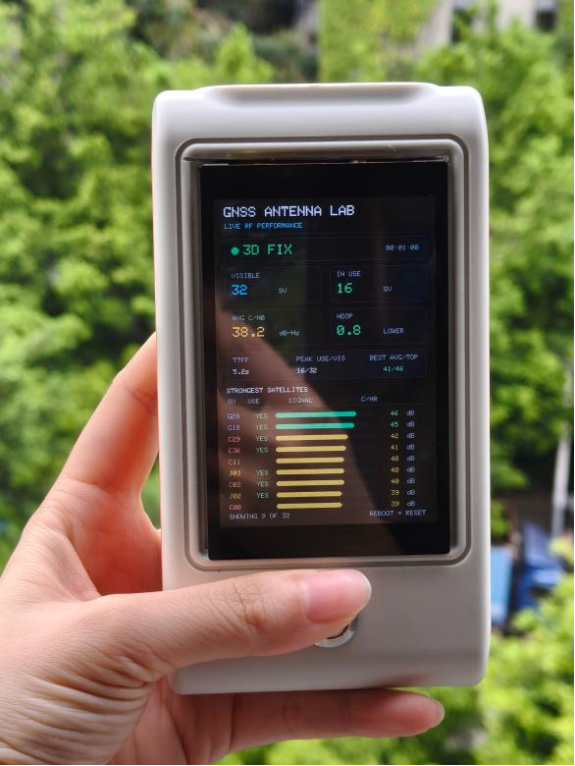
    After confirming the improvement achieved with the small active ceramic antenna, we continued testing with a larger active ceramic antenna. Compared with the smaller antenna, the larger ceramic antenna provides a larger effective receiving area and can achieve higher antenna efficiency and better signal reception performance in our design.

    The test results showed a further improvement with the larger active ceramic antenna.

    • Time to First Fix (TTFF): 5.2 s
    • Visible satellites after 1 minute: approximately 32

    This result met our expectations much better than the first-generation design and the second-generation small antenna.

    Comparison

    All antenna versions were tested under the same test conditions using the same GNSS receiver and test environment. In our test, the TTFF improved from 8.2s to 5.2s.

    Solution

    Antenna Type

    Antenna Type

    Time to First Fix

    Satellites Detected(1 min)

    V1.0

    Passive ceramic antenna

    Beneath the display, close to the battery

    8.2s

    15

    V1.1(small antenna)

    Active ceramic antenna

    Mounted above the PCB, facing upward

    5.8s

    27

    V1.1(large antenna)

    Active ceramic antenna

    Mounted above the PCB, facing upward

    5.2s

    32

  • From Ceramic to FPC: LoRa / Sub-GHz Antenna Optimization

    Makerfabs08/17/2026 at 07:16 0 comments

    During the development of the Nomad Terminal, the LoRa / Sub-GHz antenna went through several design iterations.

    For a compact handheld device, antenna performance is not determined by the antenna itself. The surrounding PCB, ground plane, battery, display, enclosure, and even the way the user holds the device can all affect the final RF performance.

    To improve the overall LoRa RF performance while keeping the product compact and practical, we evaluated several antenna solutions and connection methods during development:

    Ceramic Antenna → FPC Antenna + Coaxial Cable → FPC Antenna + Pogo Pin

    Each revision addressed limitations found in the previous design.

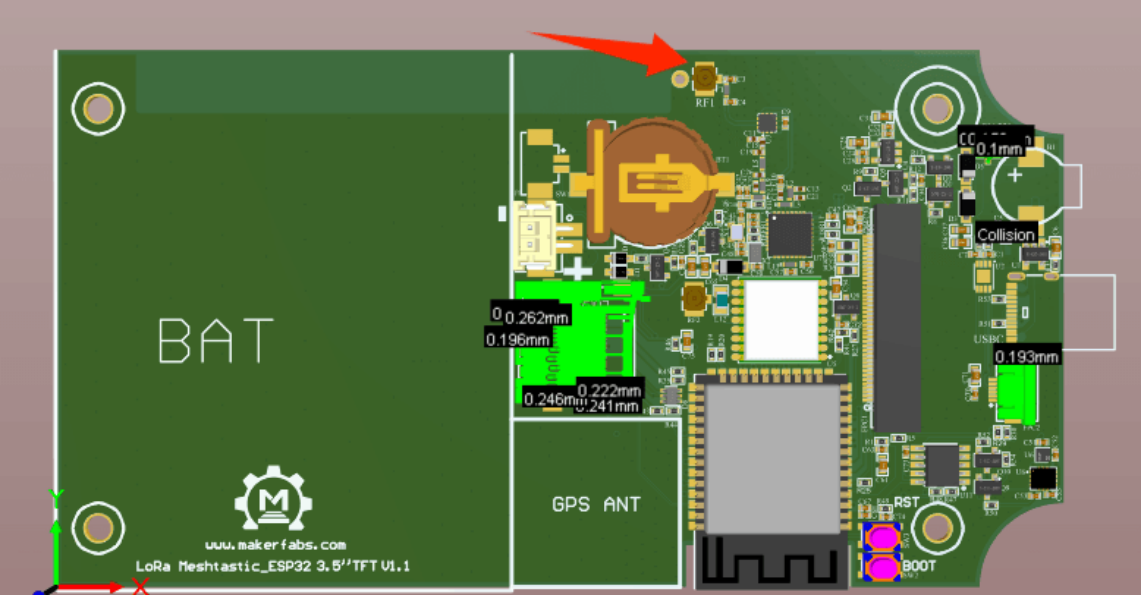
    V1.0--Ceramic Antenna

    For the first hardware revision, we used a ceramic antenna for the LoRa radio. The ceramic antenna was integrated directly onto the PCB, providing a simple and compact RF solution.

    Advantages

    Disadvantages

    Compact and easy to integrate

    Antenna performance is highly dependent on PCB layout

    No additional RF cable required

    Sensitive to nearby components and materials

    The biggest advantages of ceramic antennas are their simplicity, compactness, and ease of integration. For early product prototypes, this is a relatively straightforward solution.

    However, after assembling the complete device, we found that the ceramic antenna was located directly beneath the display module. The nearby conductive structures of the display caused antenna detuning and RF shielding, significantly degrading the overall antenna performance.

    V1.1 — FPC Antenna + Coaxial Cable

    In the second revision, we evaluated an FPC antenna. The key advantage of the FPC antenna was that it decoupled antenna placement from the main PCB layout,  compared with a ceramic antenna mounted directly on the PCB, an FPC antenna can be positioned more freely inside the enclosure.

    Advantages

    Disadvantages

    Can be positioned away from the main PCB

    Requires an additional RF connection

    Easier to avoid the battery and other components

    Transmission-line effects and impedance matching need to be considered

     The FPC solution improved placement flexibility and helped avoid blockage from the display by allowing the antenna to be positioned more freely inside the enclosure.

    However, it introduced a new RF challenge: the connection between the antenna and the main PCB.

    In this design, the FPC antenna is connected to the main PCB through a 50 Ω coaxial cable. Although coaxial cable provides a well-controlled RF transmission path, it introduces additional insertion loss, connectors, routing space, and assembly complexity. When the coaxial cable length exceeds approximately 3 cm, the cable shield can begin to behave as part of the RF ground or counterpoise, making the overall antenna performance more dependent on the cable length and routing. Since this is a handheld device, and for aesthetic reasons, we didn’t want to use a long, high-performance rod antenna, so we made another revision.


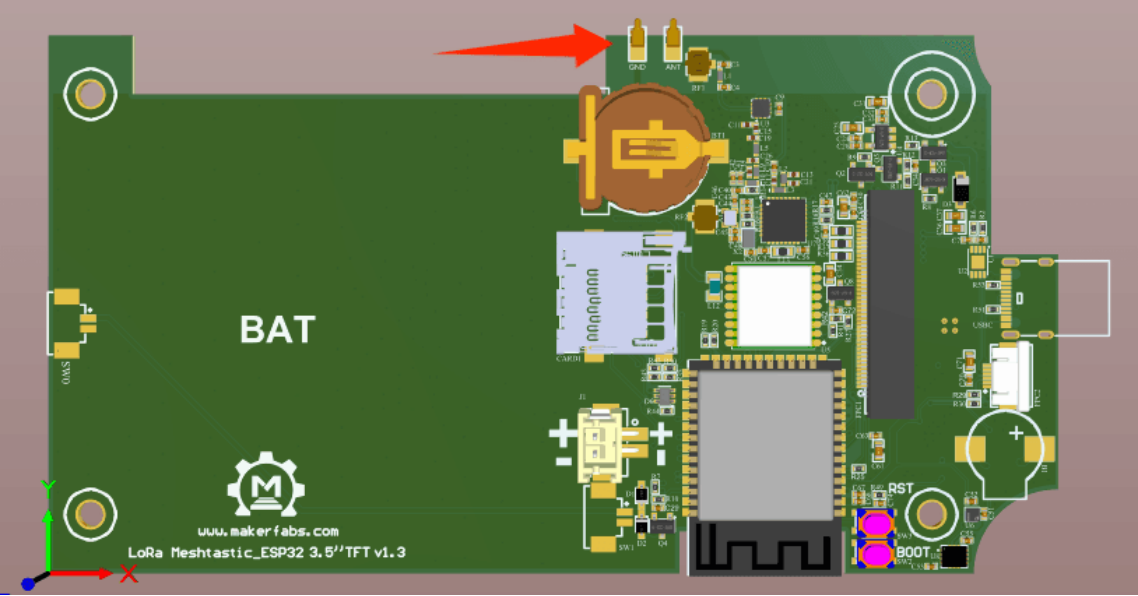
    V1.2 — FPC Antenna + Pogo Pin

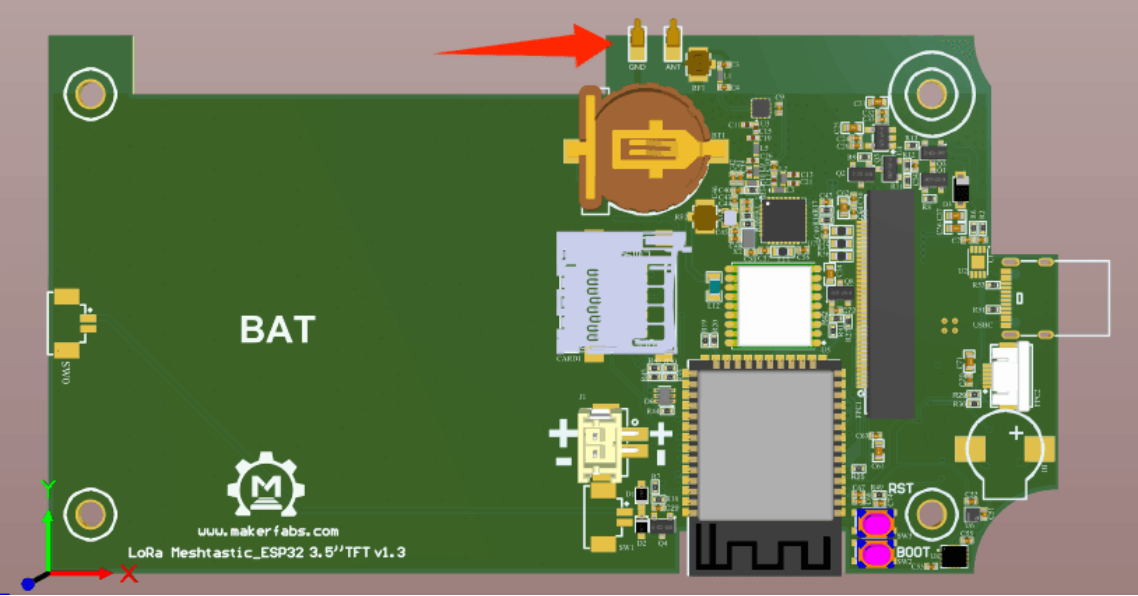
    For the third revision, we replaced the coaxial connection with a dual-Pogo-Pin RF connection, using one pin for the RF feed and the second pin for the ground return. This means the antenna is no longer referenced to the antenna side as ground, but instead uses the PCB as the reference ground.

    Advantages

    Disadvantages

    Compact RF connection with direct access to the PCB ground reference

    Requires careful mechanical integration

    It's much simpler than FPC + coaxial cable

    It is important to ensure reliable contact with the pogo pins.


    This approach gave us a better combination of the advantages from the previous two designs. The FPC antenna provided the mechanical flexibility we needed, while the Pogo Pin allowed us to keep the RF connection extremely short.

    Before evaluating the antenna in the final handheld device, we also characterized the antenna using laboratory RF measurement equipment. The antenna was measured using a network analyzer (Agilent...

    Read more »

View all 2 project logs

Enjoy this project?

Share

Discussions

Similar Projects

Does this project spark your interest?

Become a member to follow this project and never miss any updates