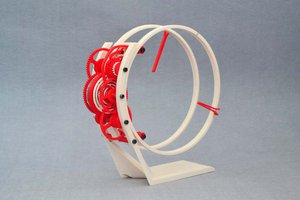
Years ago I built a barn-door tracker for making long exposure photographs of the night sky. It was made from MDF (wood) and plastic and is a bit janky, but it worked ok and I got a few good photos.
I was looking for a project to make with my new lathe and milling machine, and a re-make of the old tracker in metal seemed like a good candidate. But I also wanted to make it
- smaller, more compact
- much more rigid
- more accurate
...so came up with a rather unconventional design which is simple, but requires a microcontroller to compensate for the variable rate required to drive the motor. Read on...
I wasn't really comfortable with the idea of having to manually set the starting position of the tracker each time it's powered on, i.e. the 'only just fully closed' position. So I found an old microswitch kicking around and decided to test it for its mechanical repeatability. I wrote a script to slowly press and release the microswitch very precisely, using the motor/screw/nut mechanism, and record the motor step count on each low-to-high and high-to-low transition. Closing/pressing the switch seemed to give the best consistency, with NC and NO contacts being broadly similar in their behaviour. Repeatability was easily better than +/-0.01mm, and probably within +/-0.005mm most of the time. Which is remarkable.
I can use this switch to detect the 'closed' position and thus initialise the motor at start-up, rather like Z-axis homing on a 3D printer.
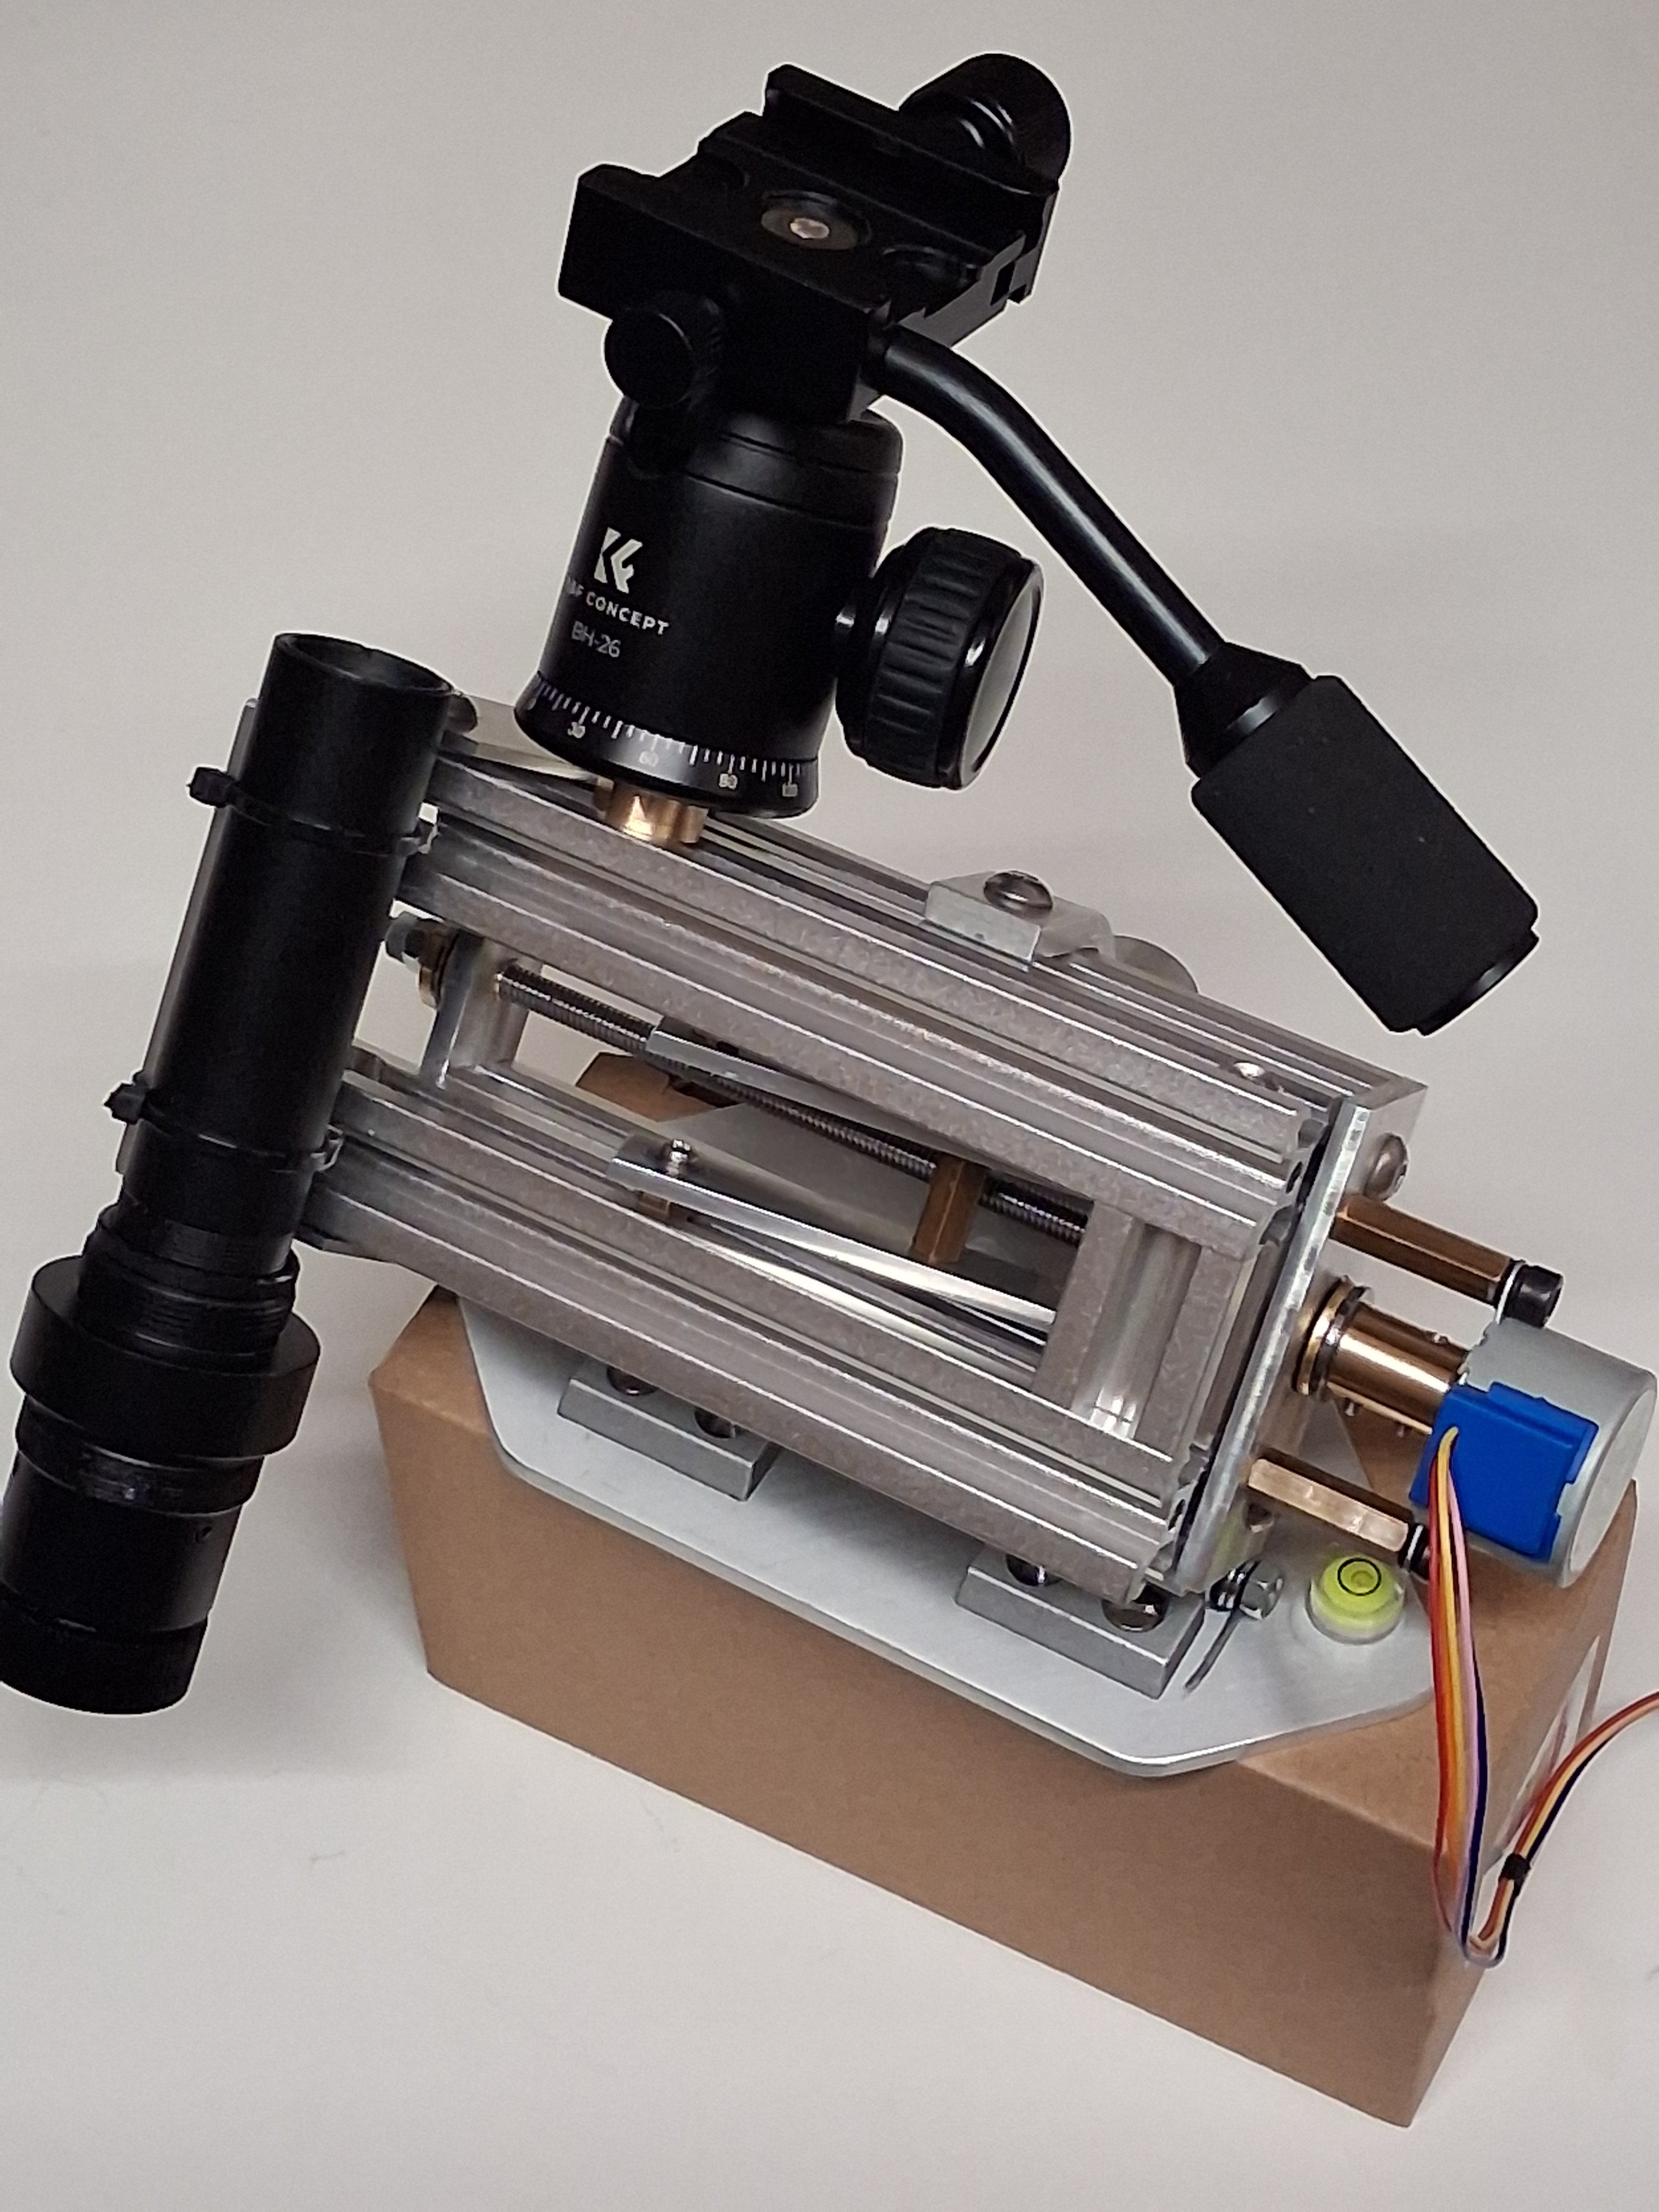
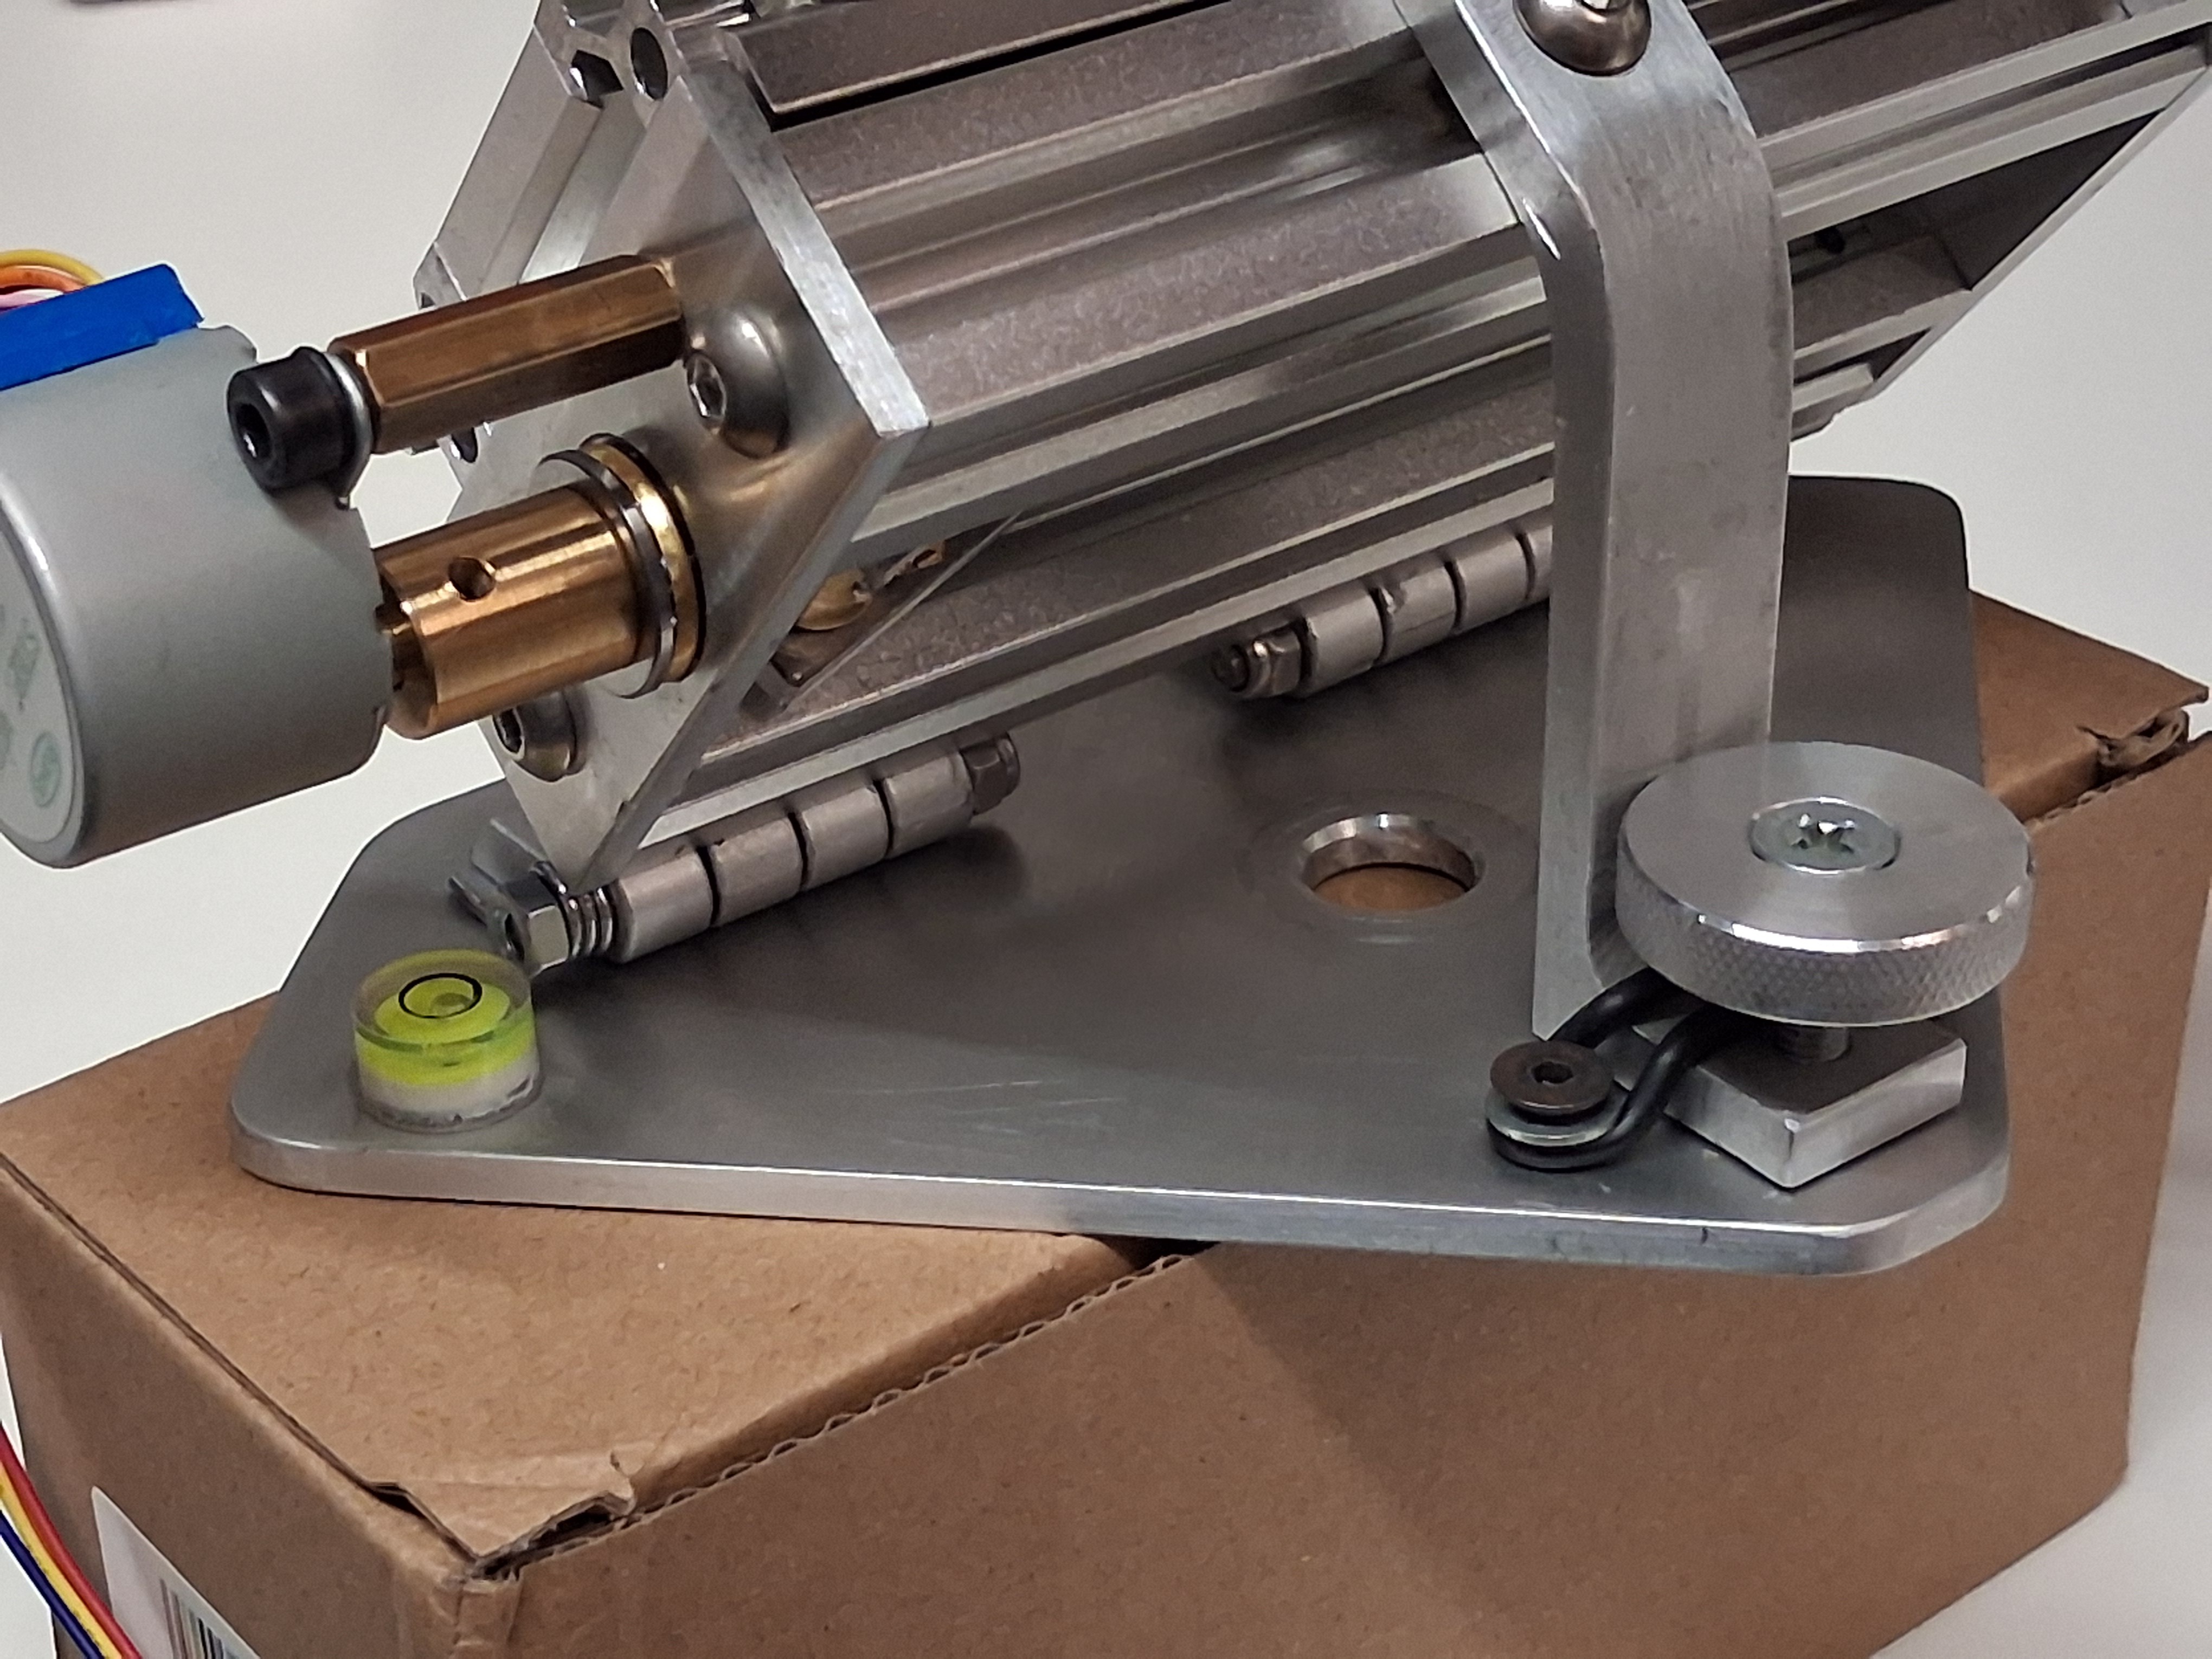
I've nearly finished all the making and assembling, just a few finishing touches to go:
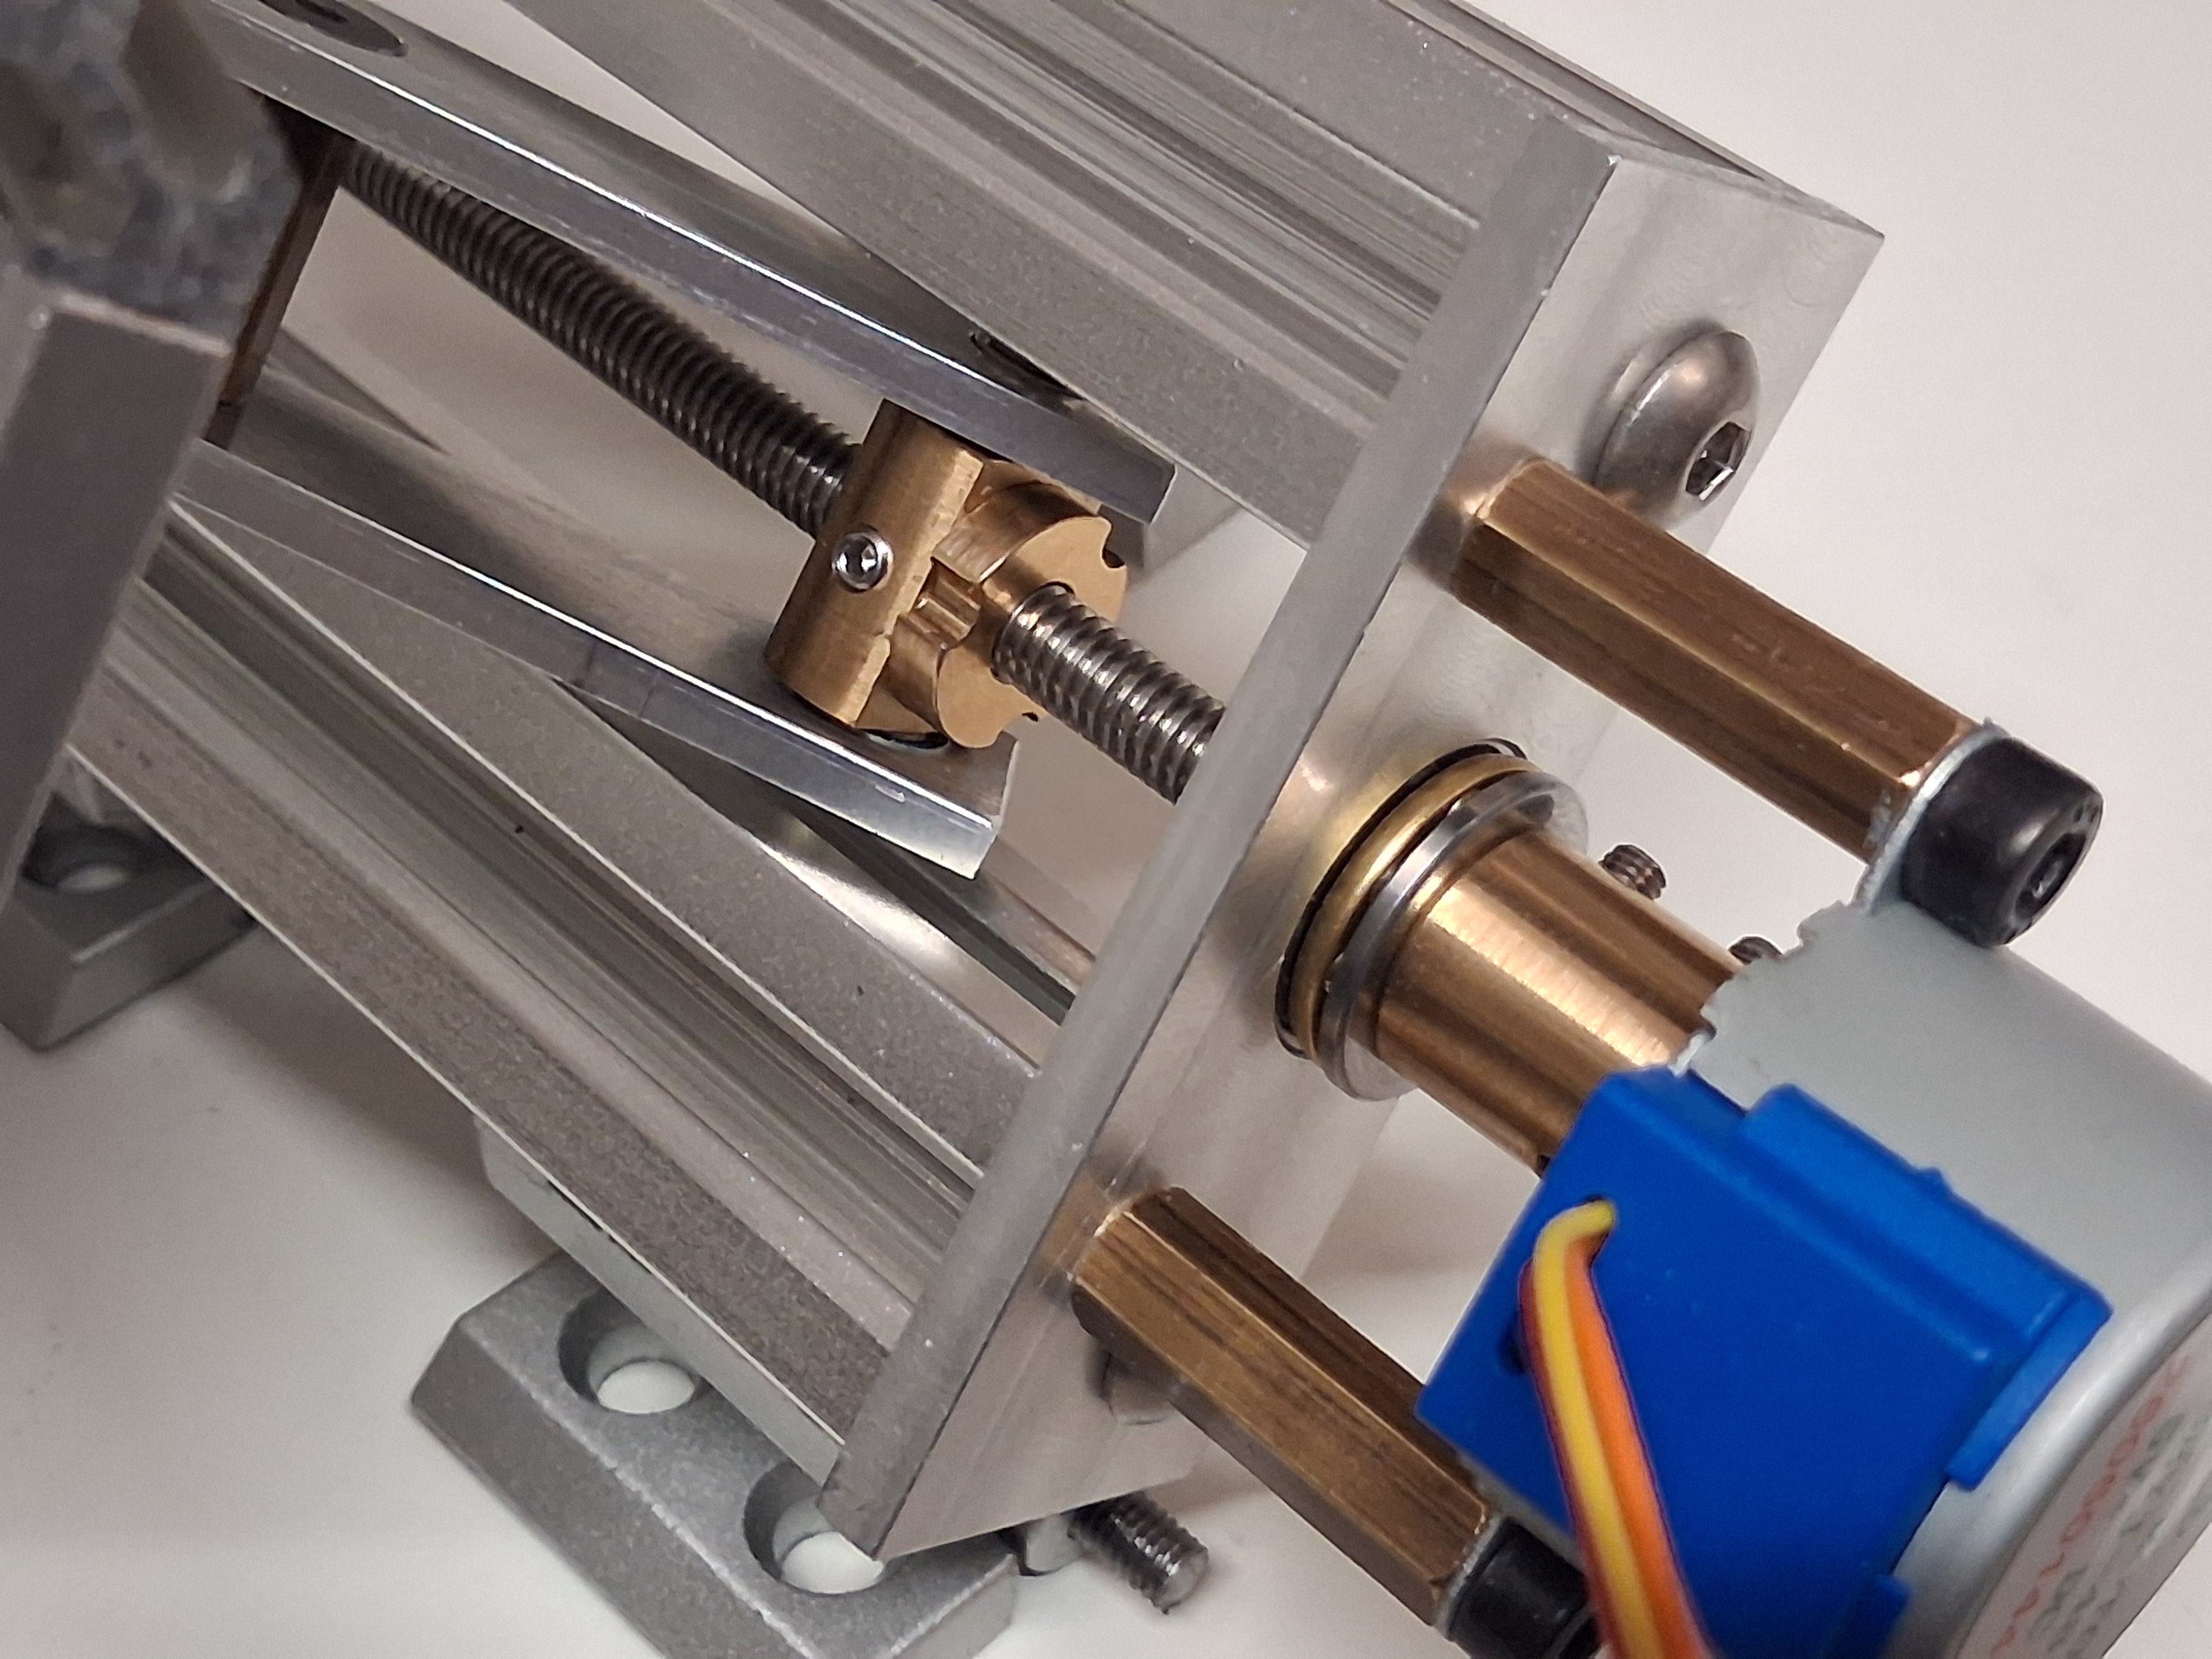
The stepper motor is only just powerful enough to drive the screw once my camera is mounted on top, so I might have to revisit that. Plus I still need to finalise the electronics/driver and software anyway.
But... early experiments with my 250mm lens and the camera in Live View mode at maximum zoom show that the motion is very smooth - not very much wobble at all.
The stepper motor runs "open loop" so the controller has no way of knowing the position of angle of the tracker. It keeps track of the step count each time the motor is stepped so, as long as it starts up in a known position, and isn't allowed to stall at all, it all works fine.
The controller also has a 'clock' which counts the milliseconds that have elapsed since powering on. After each step, the controller calculates the exact clock time of the next step. It does this using a bit of maths which relates the step count - and therefore the position of the nut - to the angle of the moving part of the tracker. The angle must increase at a constant rate, but the timing of the steps is changing slightly all the time.
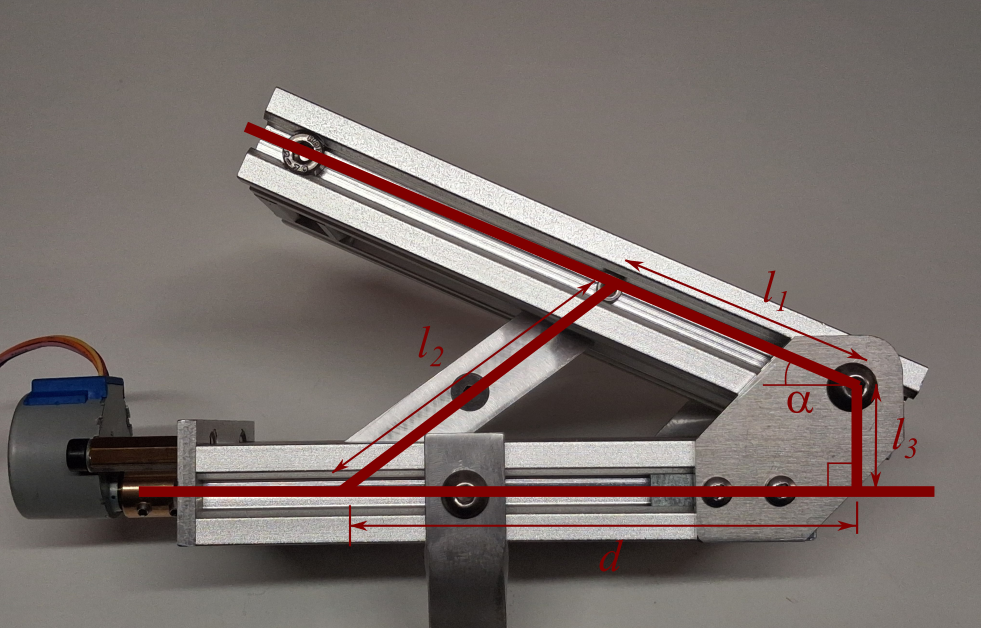
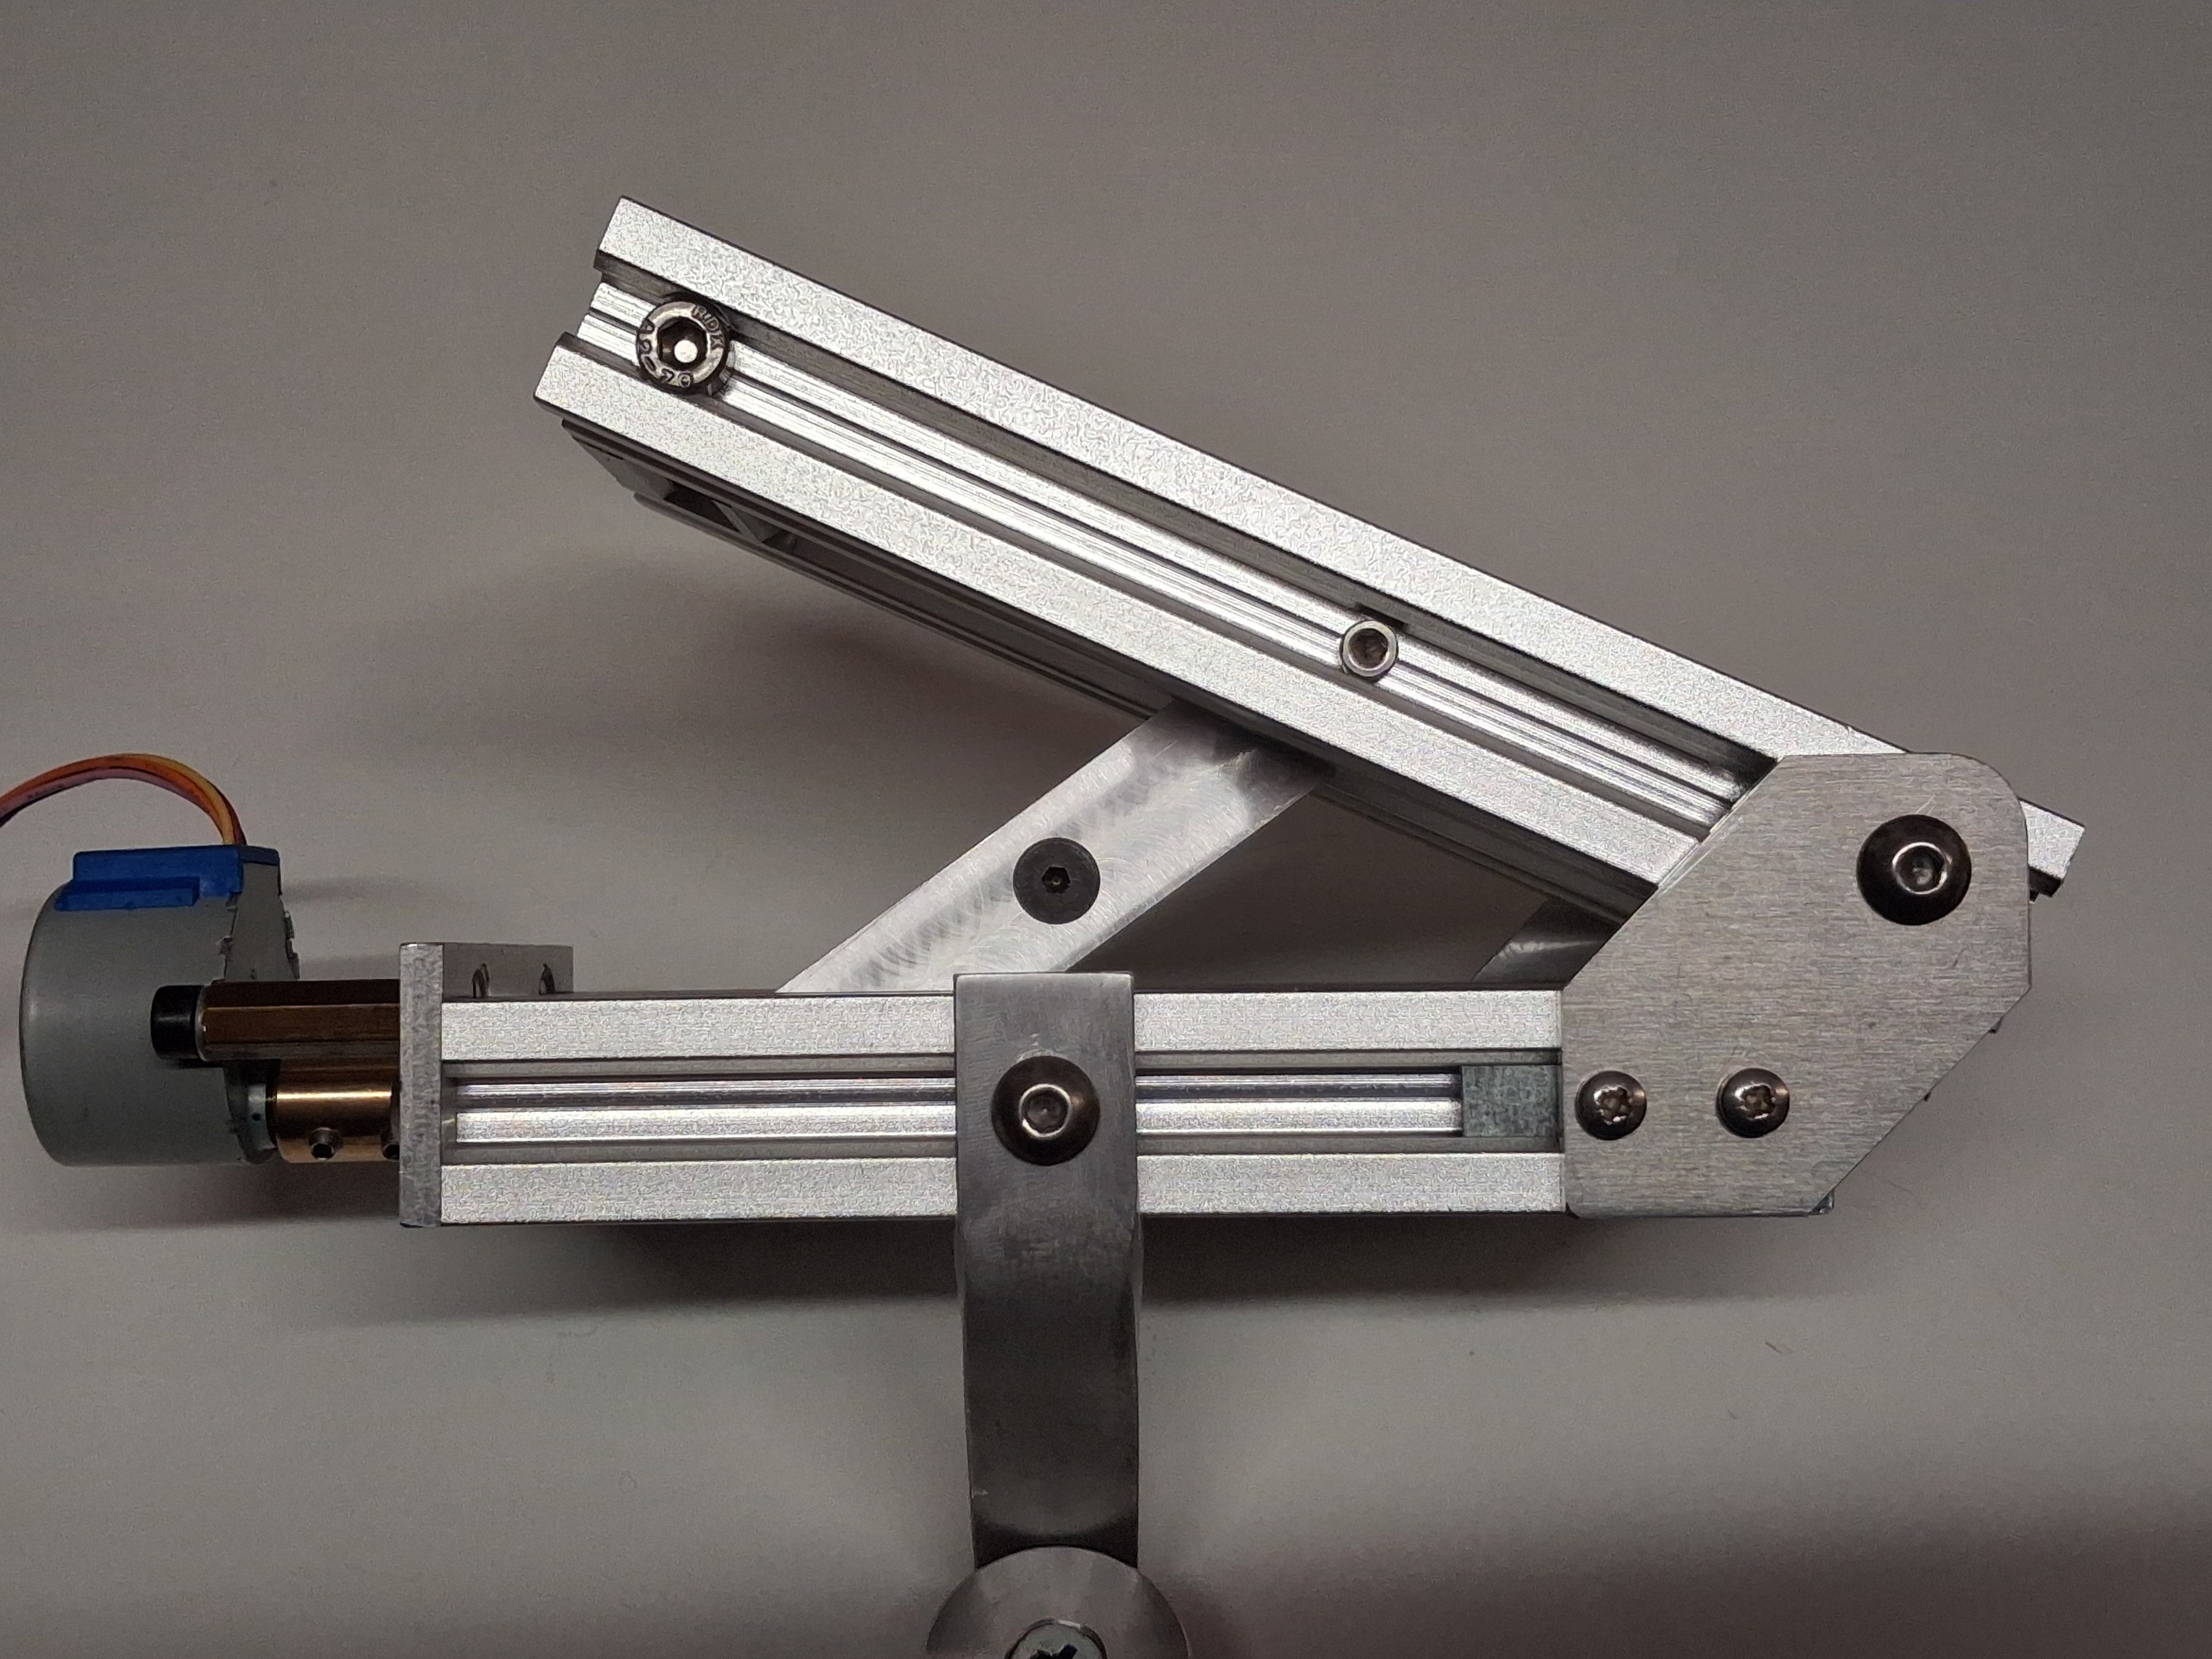
Lengths l1, l2 and l3 are all fixed and connected by hinges. Distance d changes as the motor drives the nut forward and backward along the screw. The opening angle, α, is then determined using trigonometry as:
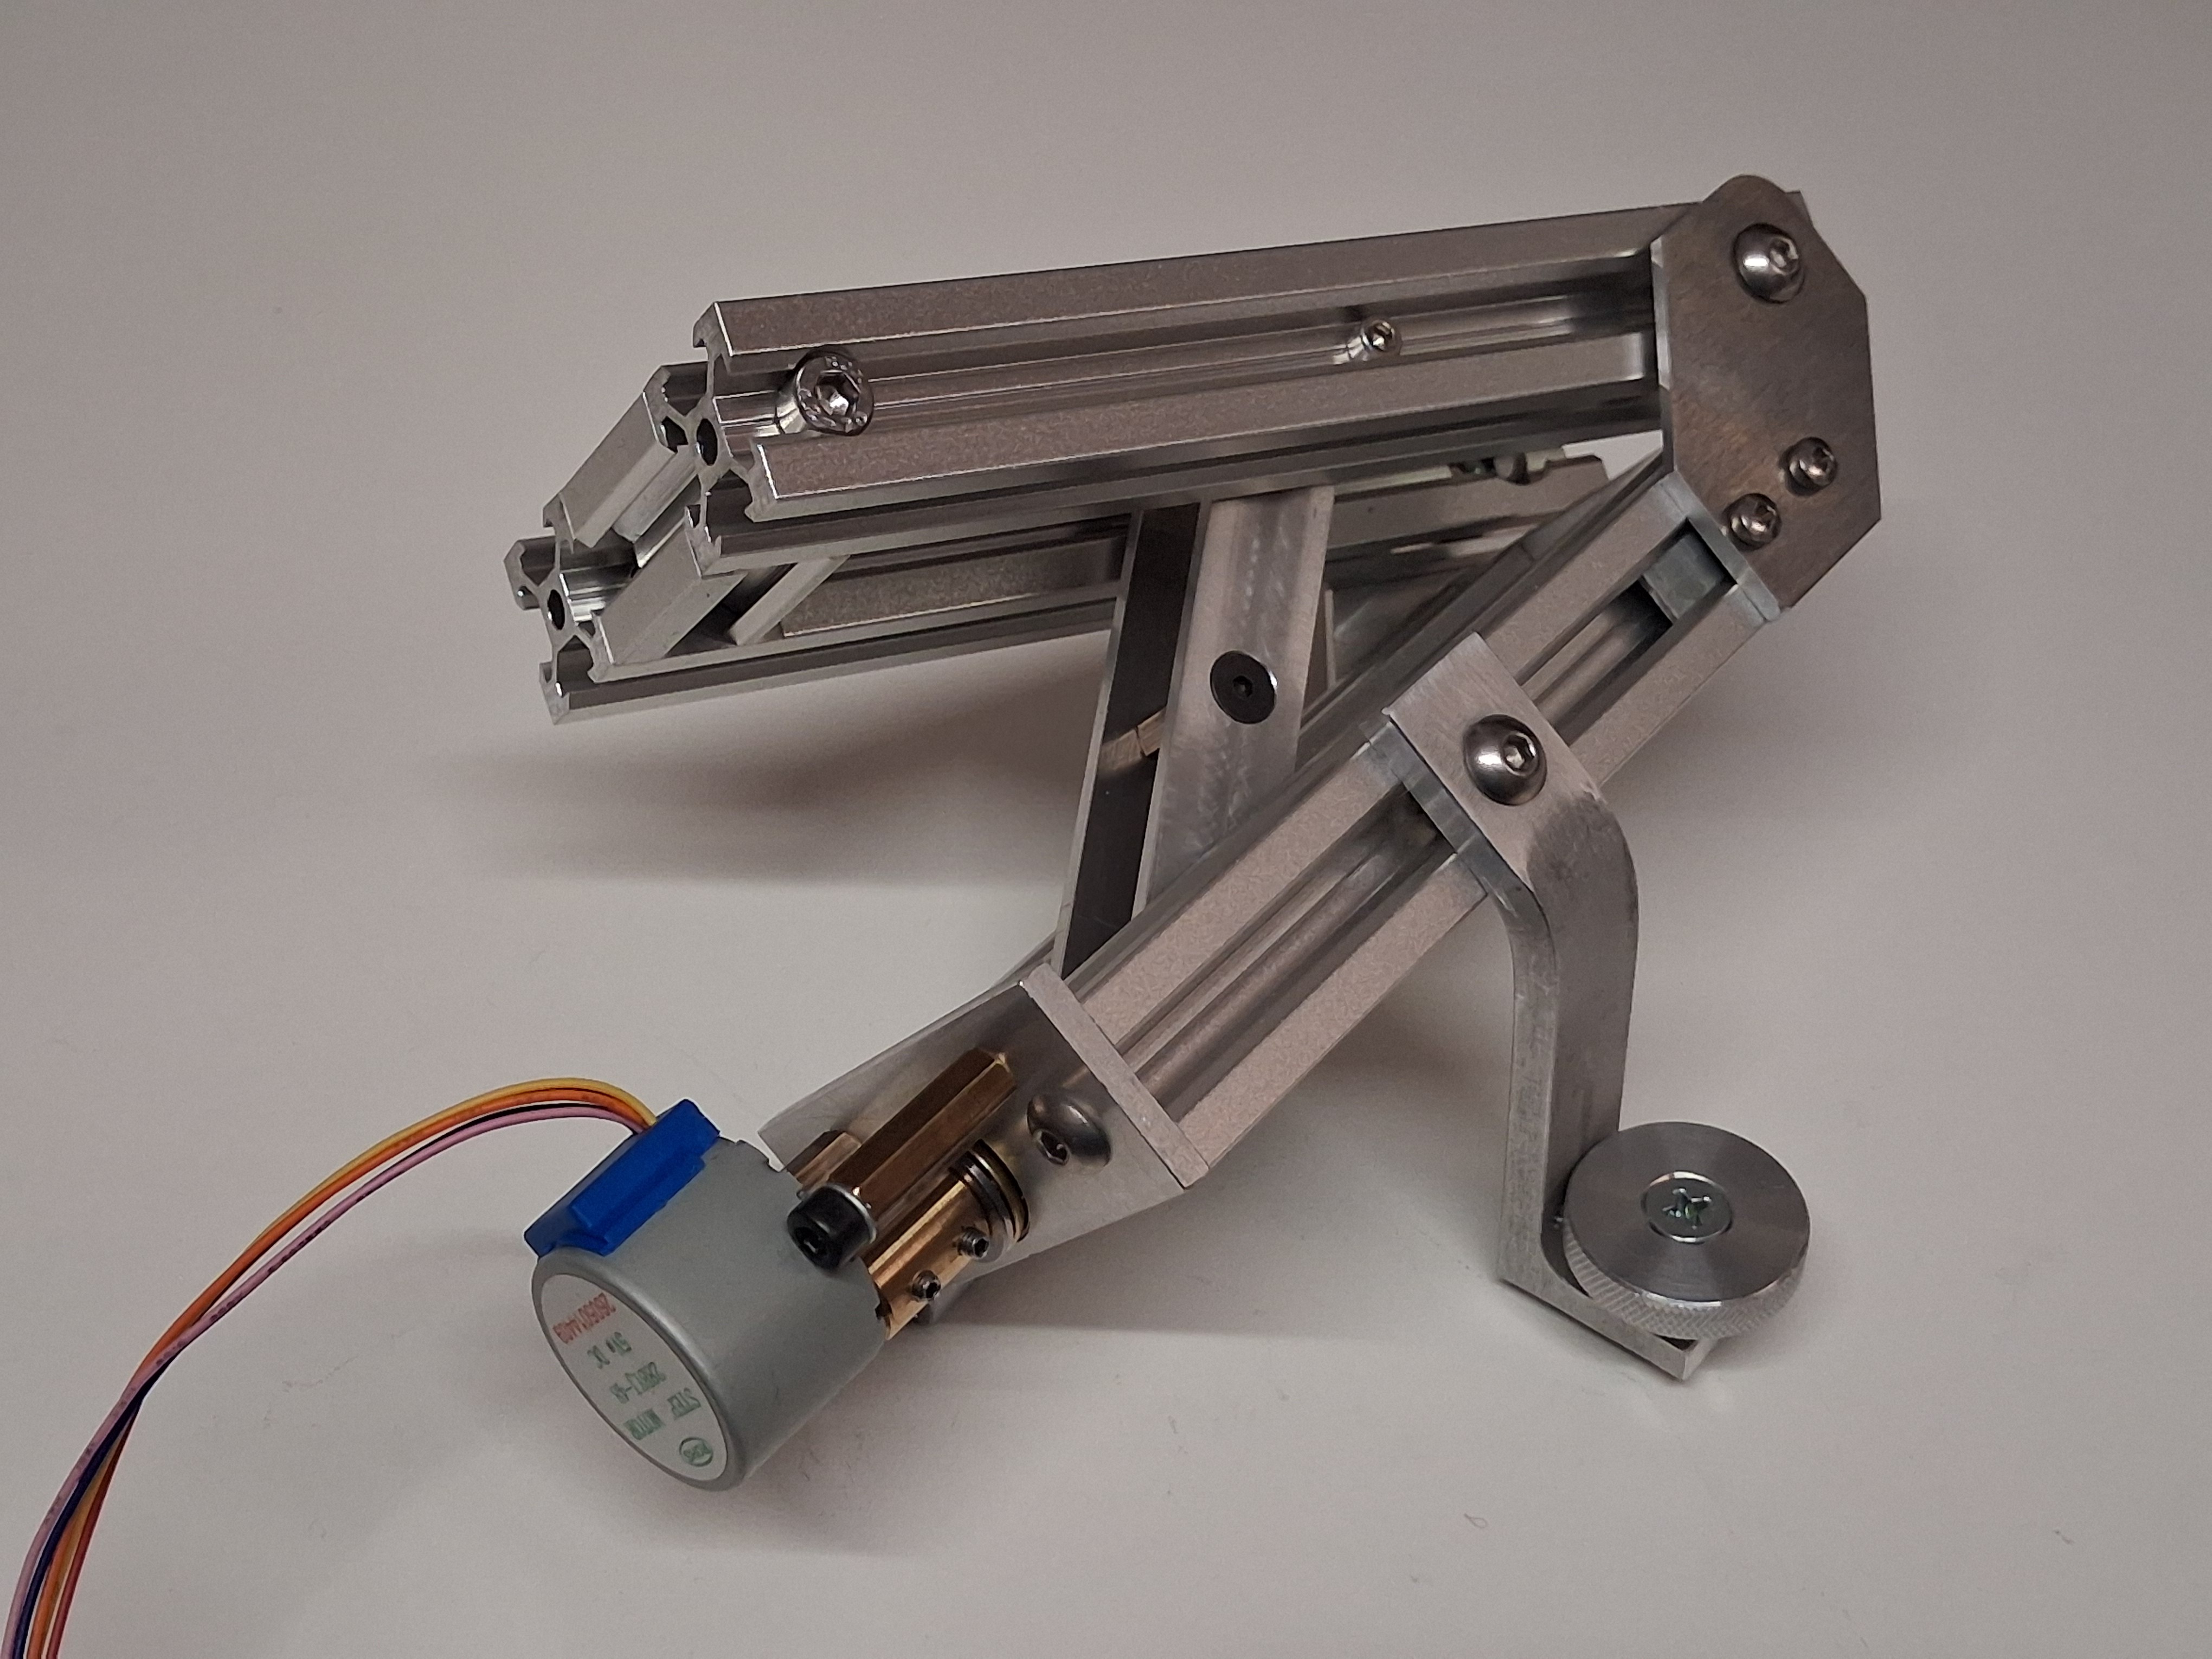
I've been working on this a few weeks, so the design is already quite advanced. Here's what I've got so far:
The mechanism is quite different: a nut is driven along a straight, linear leadscrew which in turn opens the two halves via a linkage. Since the opening angle must increase at a constant rate, but the position of the nut along the screw is not proportional to the angle, the screw cannot be driven at a constant rate. Instead a microcontroller (Arduino Nano) is used to calculate the precise moment to step the motor each time (20-30 times per second) in order to compensate for the changing relationship between nut position and opening angle.
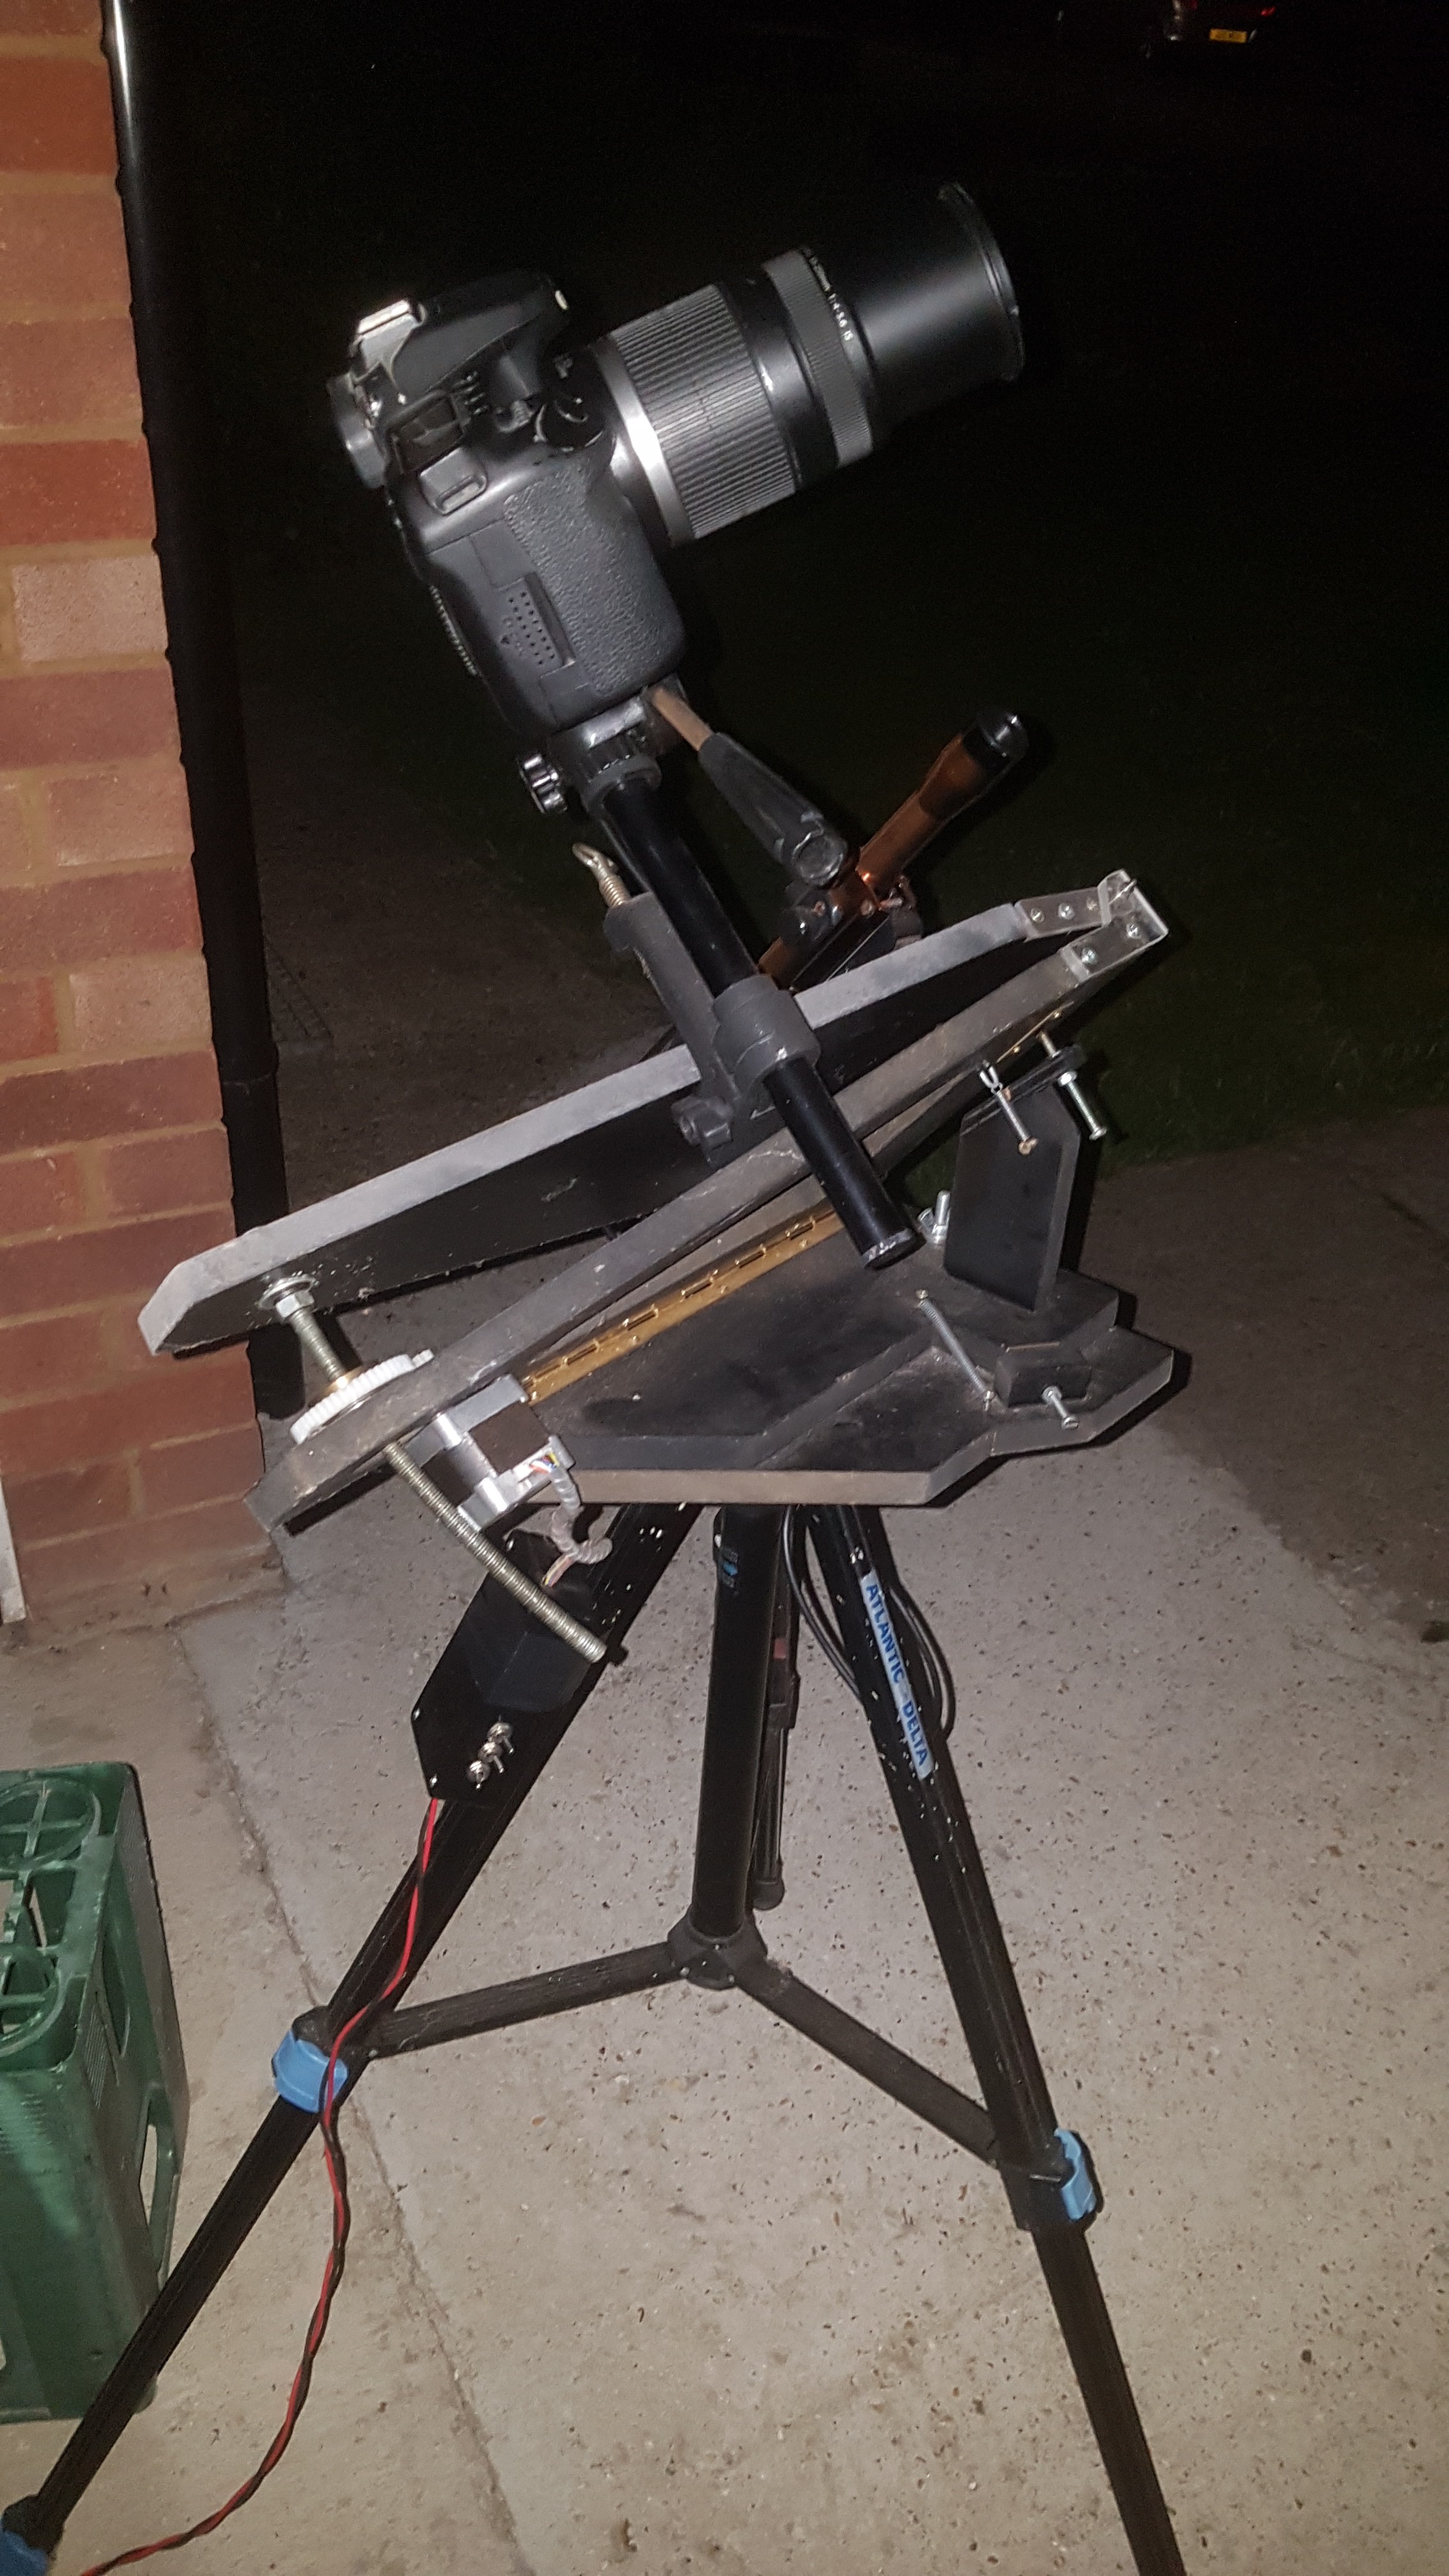
Here's a pic of the original wooden tracker with my DSLR attached:
It uses a stepper motor driven at a fixed 32-steps-per-second rate, courtesy of a 32kHz quartz crystal clock and frequency divider. The motor drives a nut along a curved, threaded rod, which opens the two halves at the required 15degrees-per-hour rate. The down-side is that the curved rod tends to waggle (the thread isn't very accurate) so very long exposure images are a little blurry. Overall accuracy is also limited by poor dimensional tolerance when drilling the holes for the bearings - the whole thing has to be large to minimise the tolerance effects.
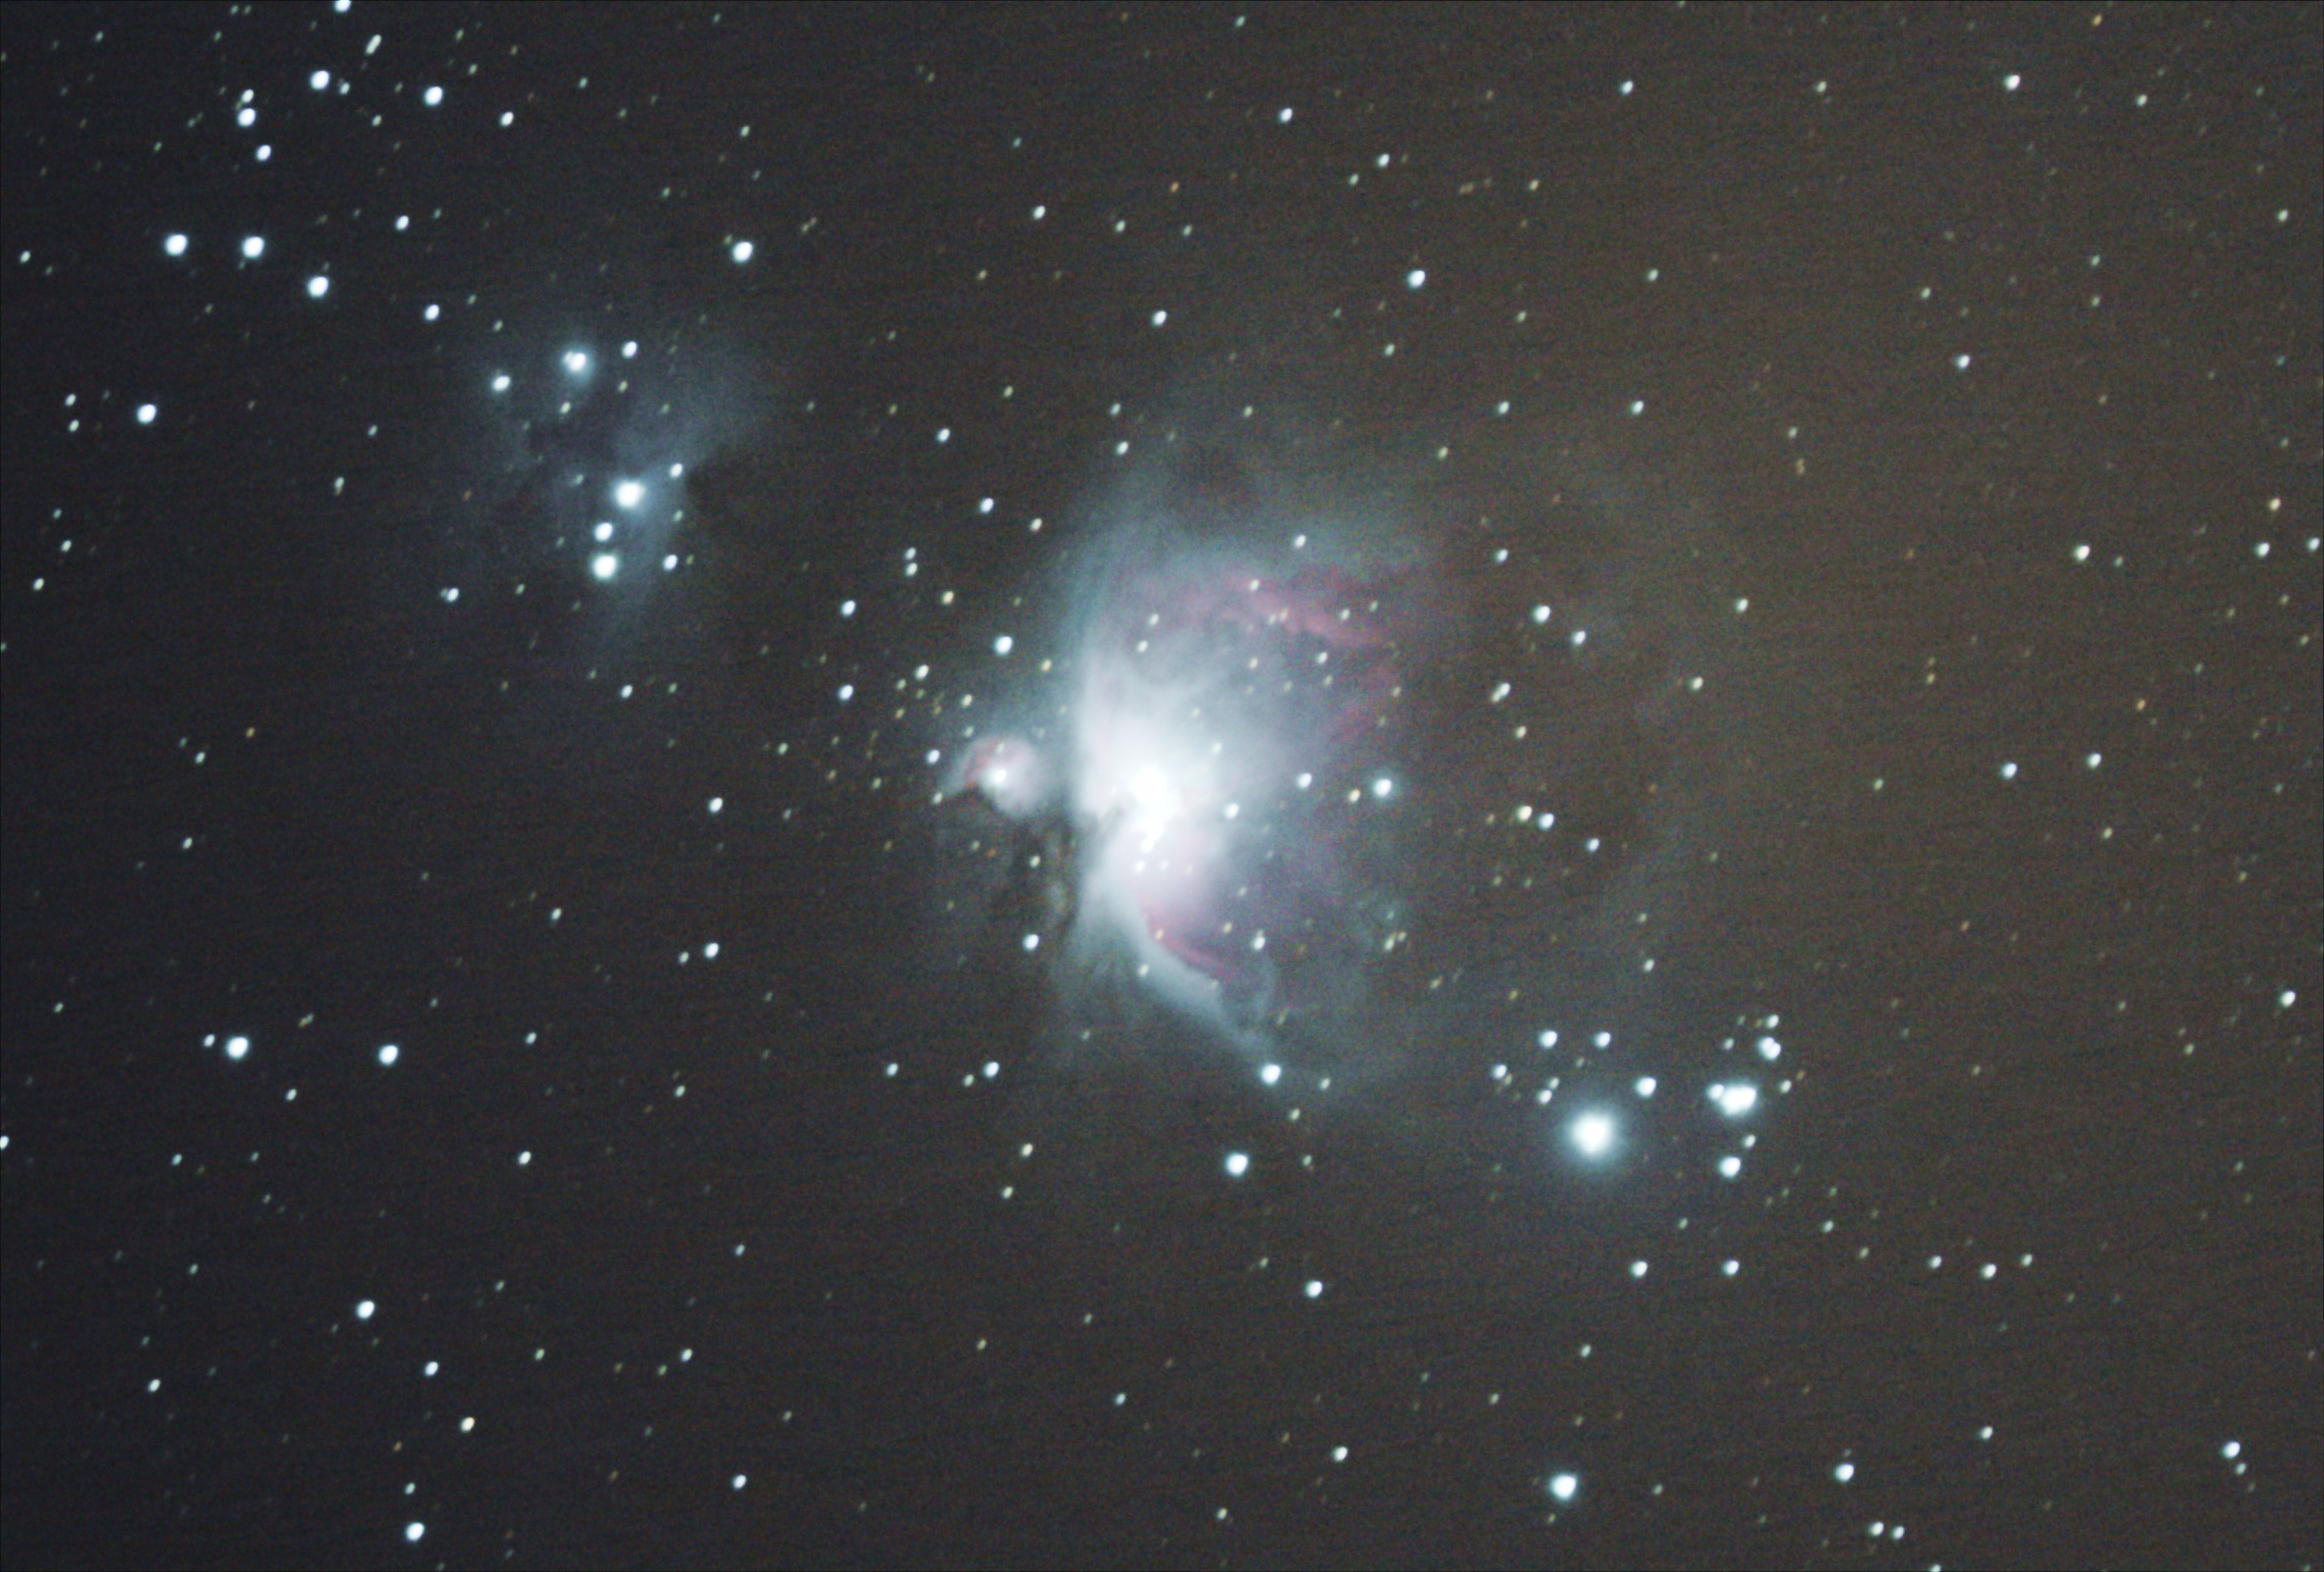
Nevertheless, here's a pic I managed to take by stacking dozens of short(ish) exposures:
Hi, thanks for your interest in the project. Yes I had been considering spring loading, or using a counterweight, to help things. But an easier solution might be to convert the motor from 5-wire to 4-wire and use a bipolar driver. This should also allow me to run the motor from nearer 12V (I'm intending to power from a lead-acid battery) which will also be quite convenient. Perhaps making those changes will improve the torque enough without needing any mechanical assistance... Hopefully I'll get time to try it soon!
Regarding the underpowered motor issue, your linkage is non-linear in terms of leverage, so it requires a lot more force to move the same distance when the angle α is closer to zero, this combines with the fact that the camera is also on a lever that requires more force to move up when the mass isn't above the fulcrum. luckily you've already taken that into account by mounting the camera close to the hinge.
Anyway, because the issue is angles, the easiest solution is simply to start your exposure with α already close to 90º. Or alternatively just flip the whole setup and motor rotation so that it's working with gravity rather than against it, or even just spring load the mechanism to take some of the force off of the motor.
Hi, thanks for your interest in the project. Yes I had been considering spring loading, or using a counterweight, to help things. But an easier solution might be to convert the motor from 5-wire to 4-wire and use a bipolar driver. This should also allow me to run the motor from nearer 12V (I'm intending to power from a lead-acid battery) which will also be quite convenient. Perhaps making those changes will improve the torque enough without needing any mechanical assistance... Hopefully I'll get time to try it soon!