Close
0%
0%

Rolling Ball Robot

Wanted to build a rolling ball robot that was like the pop from Arc Raiders. This is my journey into making a prototype.

Similar projects worth following
93 views
0 followers

Welcome to my project! I am attempting to remake a Pop Arc from Arc Raiders. 


Plan

  1. Create the prototype housing that will hold the RC like unit inside the ball
  2. Create and test the electronics
  3. Create the model to hold all the electronics inside the housing
  4. Test the overall movement
  5. Start working on the appearance to make it look more like a Pop Arc
    1. This stage might also require adding more electronics e.g. speaker 
  • 1 × MH-ET LIVE ESP32 DevKit Main brains
  • 1 × TB6612FNG Dual H-Bridge
  • 2 × XD-37GB520 12v motor

  • Update 2 - Design Work

    Dale08/31/2026 at 00:14 0 comments

    Motors

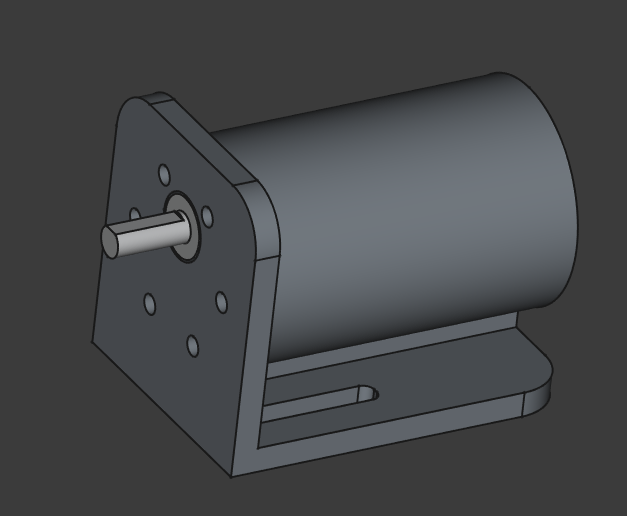
    I have started to design and test print the motor holders for the main body. After testing a few prints and forgetting the screw size is M3, I managed to come up with a nice design as shown below. Thankfully I was able to find a model for the XD-37GB520 motors from grabcad.
    The result came out really well in the end. Using M3x12 screws, the motor fits really snug inside the holder.
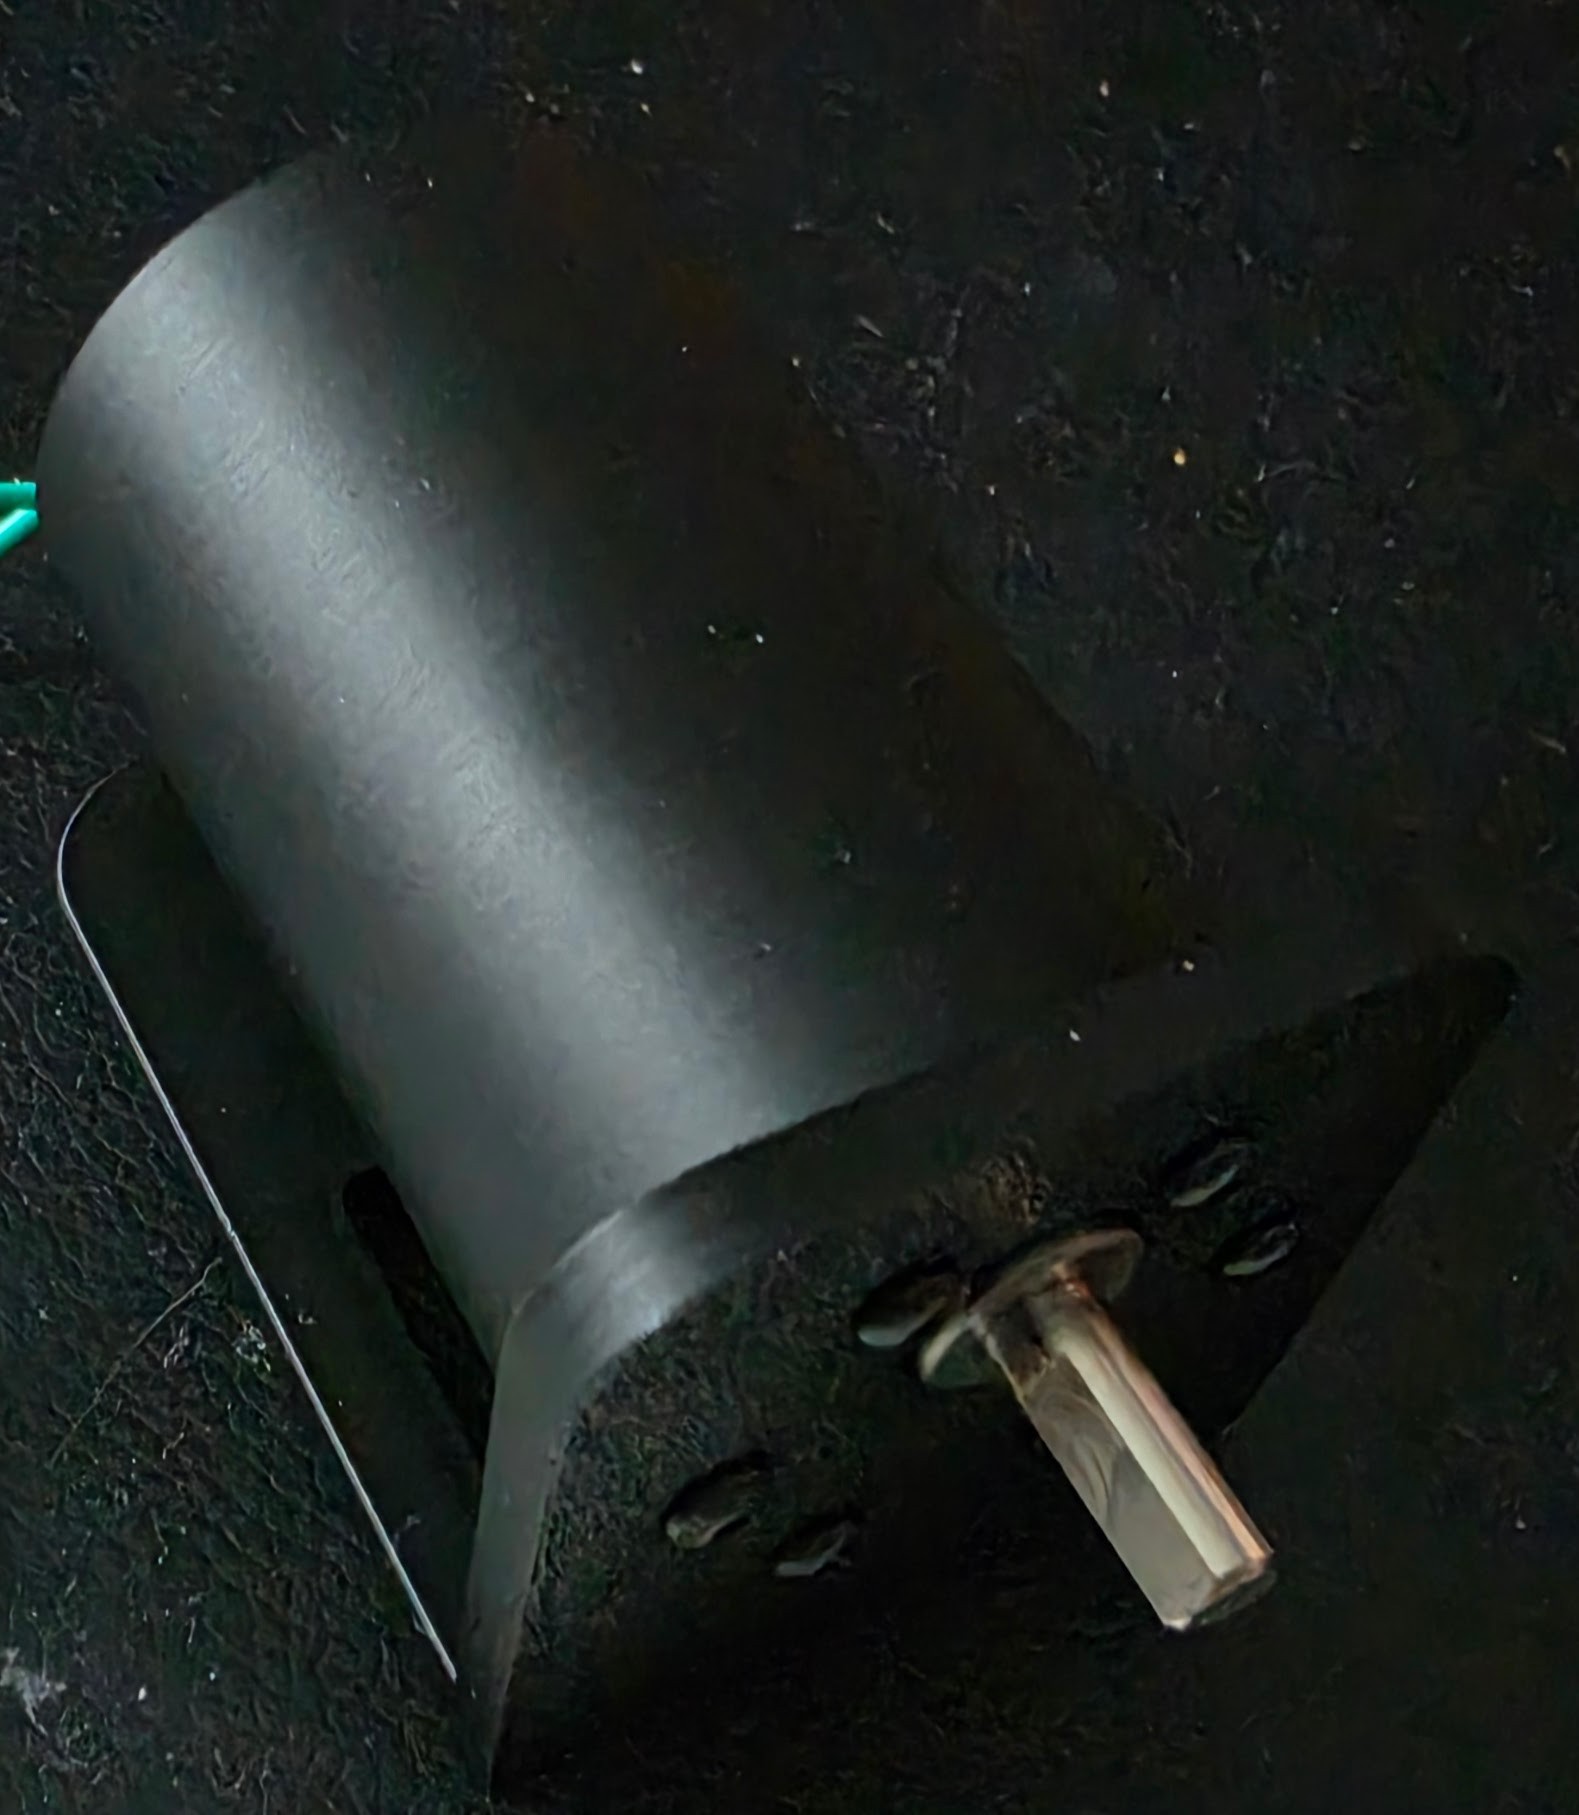
    The idea of the bracket was to give me an idea of how far the wheels need to come out to make contact with the sphere. One thing I will be looking at is angling the wheels if the contact is not great.
    Main Sphere

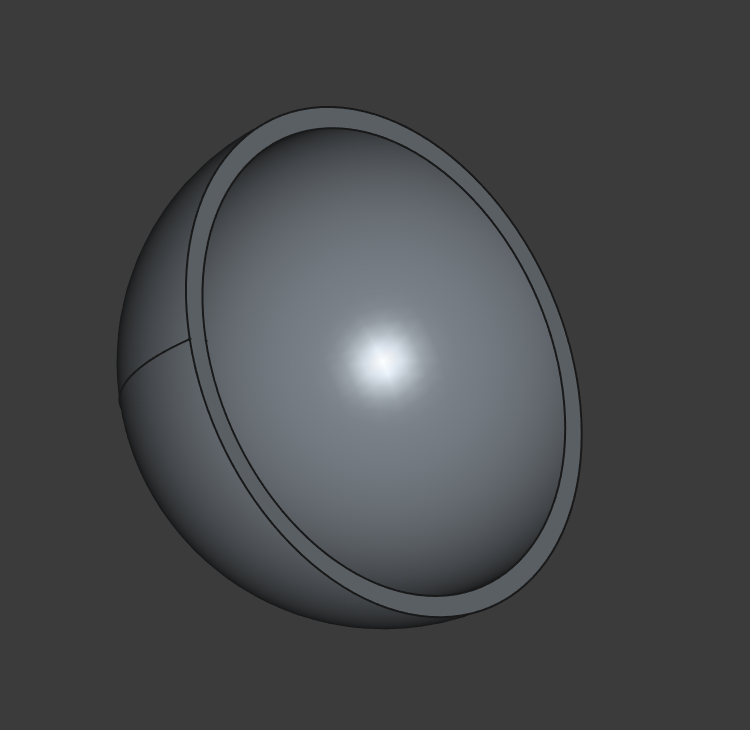
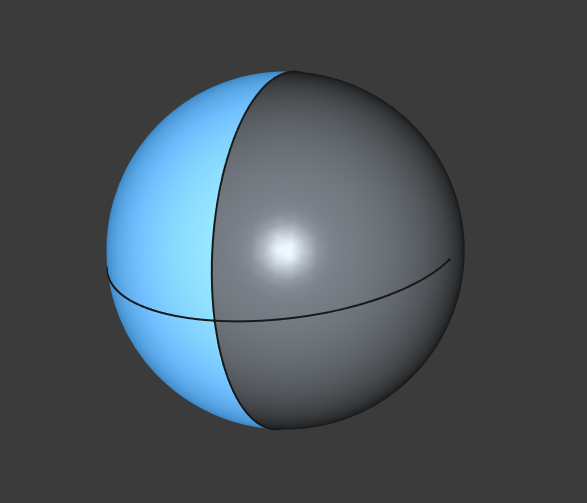
    The main sphere pieces I have started to print for test fitting. One thing I might need to invest in is a bigger nozzle due to the print times being silly for the A1..19h at .4mm is not great for testing things fit.

    I shall be designing the main bracket unit next to hold all the electronics e.g. ESP32+Motor Controller+Battery components. 

  • Progress on the electronics and CAD model

    Dale08/22/2026 at 16:08 0 comments

    Been working on getting the basics sorted before moving into the main gritty tasks. To do this, I have made a nice list of tasks that I have worked on.

    • Solder wires for the motor controller and ESP32 dev board 
    • Run test code against the setup with 12V supplied to the controller board
    • Start CADing work on the ball

    So task one, I have already soldered up the boards and ran some quick code to test they work. Everything looks good with the motors being able to rotate correctly etc. 

    The next step was to start working on getting the sphere started that will house the RC frame to move the ball. I went with a 220mm size sphere to avoid not being able to print this on my Bambu A1. 
    Next steps is to get a few holes added around the ball to be able to mount them together. Once that is done, I shall be moving onto the frame that will house the motors, controller, battery, ESP32 etc.

View all 2 project logs

Enjoy this project?

Share

Discussions

Similar Projects

Does this project spark your interest?

Become a member to follow this project and never miss any updates